Bluetooth Controll Robot

The Bluetooth-Controlled Obstacle-Avoiding Robot is a small robotic vehicle that can be controlled wirelessly using a Bluetooth controller. The robot uses an Arduino as its main controller to receive commands, control the motors, and monitor the distance in front of the robot.
The robot uses an ultrasonic sensor to detect obstacles. When an obstacle is detected, the robot can stop, move backward, and turn to avoid the obstacle. The Bluetooth controller allows the user to control the movement of the robot wirelessly.
This project demonstrates the basic concepts of robotics, Arduino programming, wireless communication, sensor interfacing, motor control, and obstacle detection.
Supplies
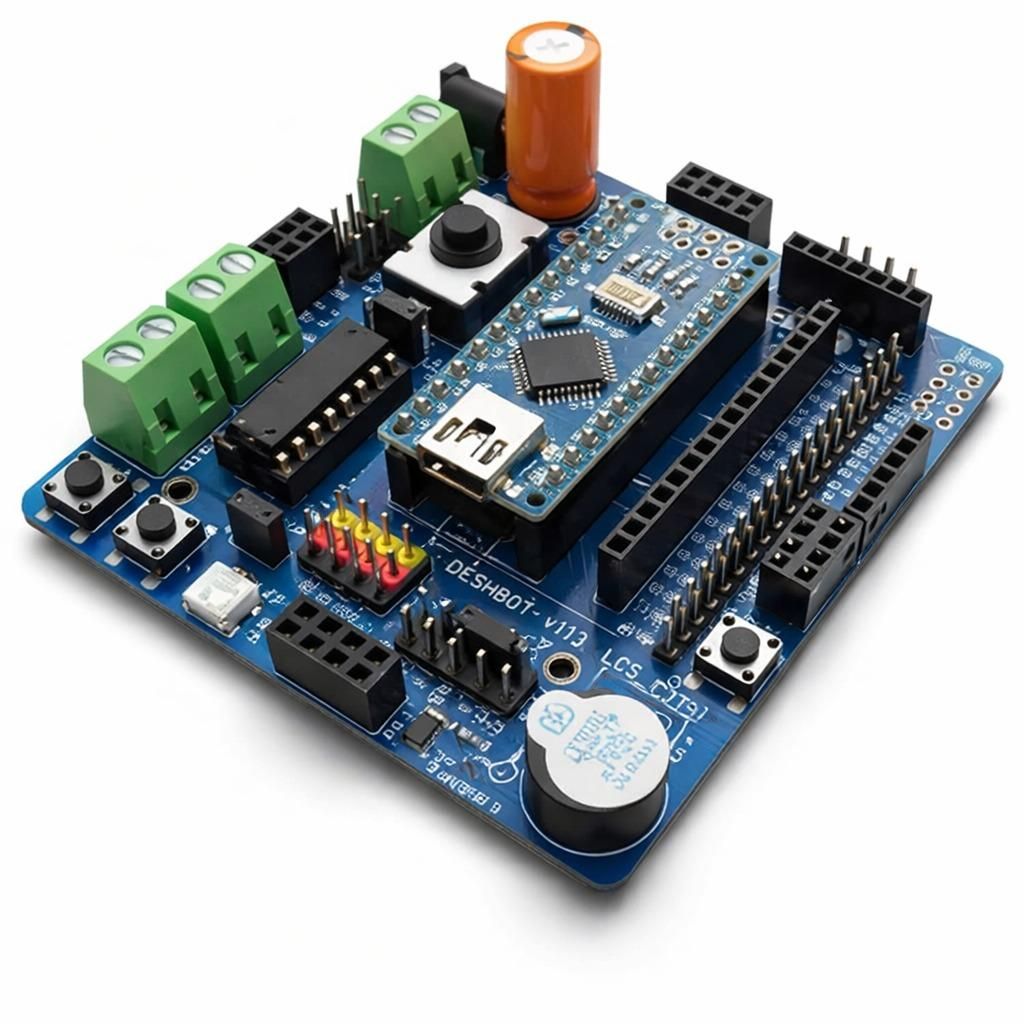
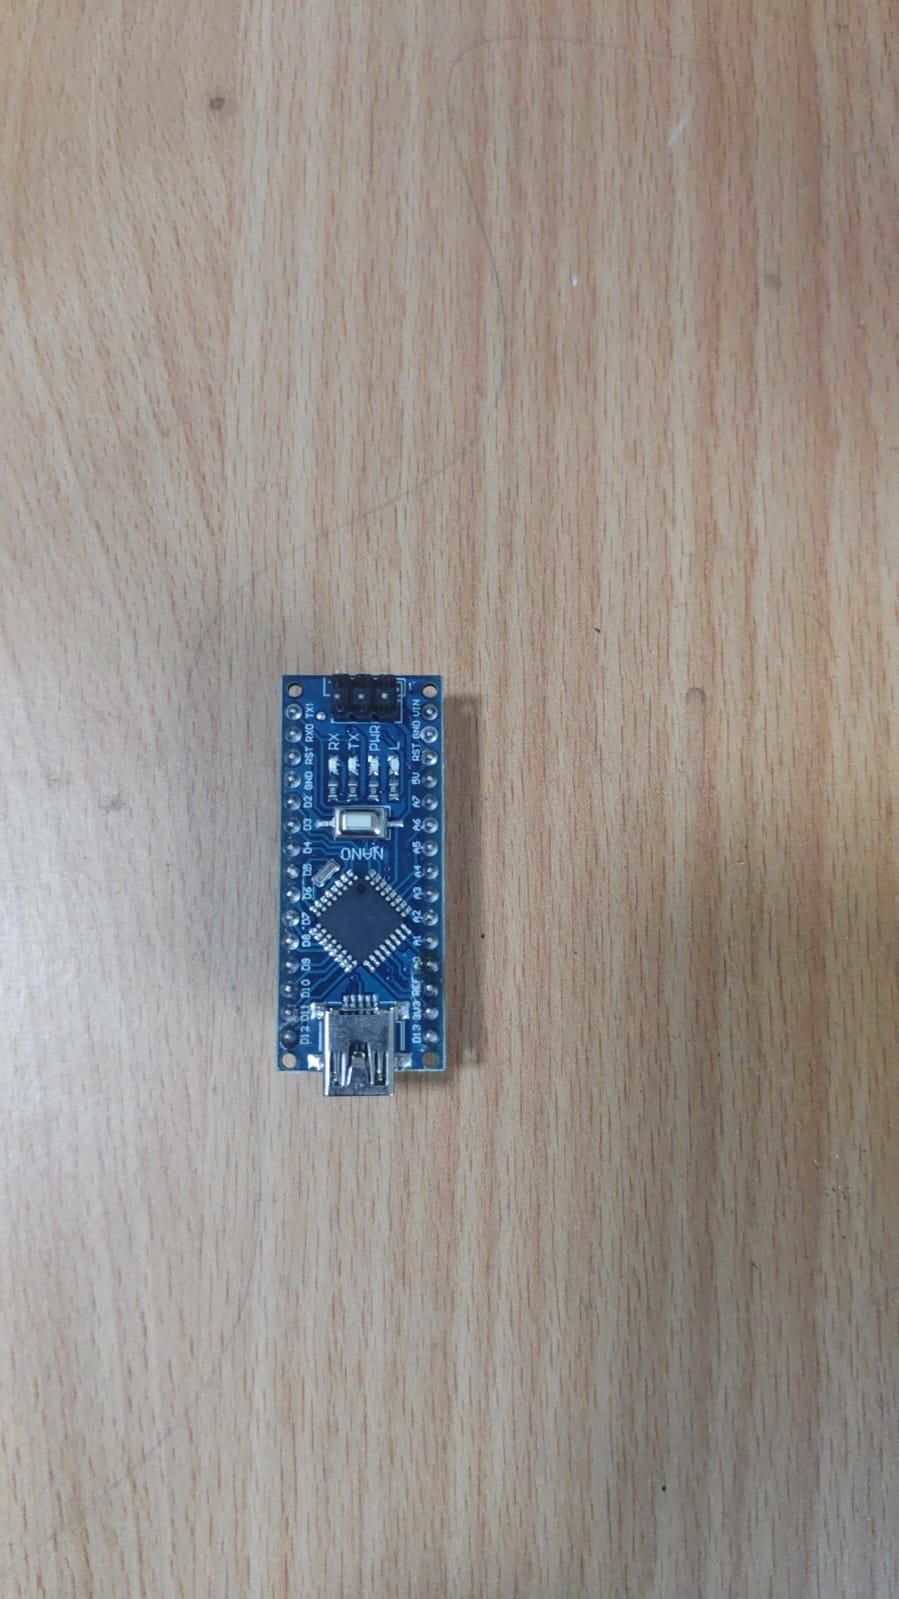
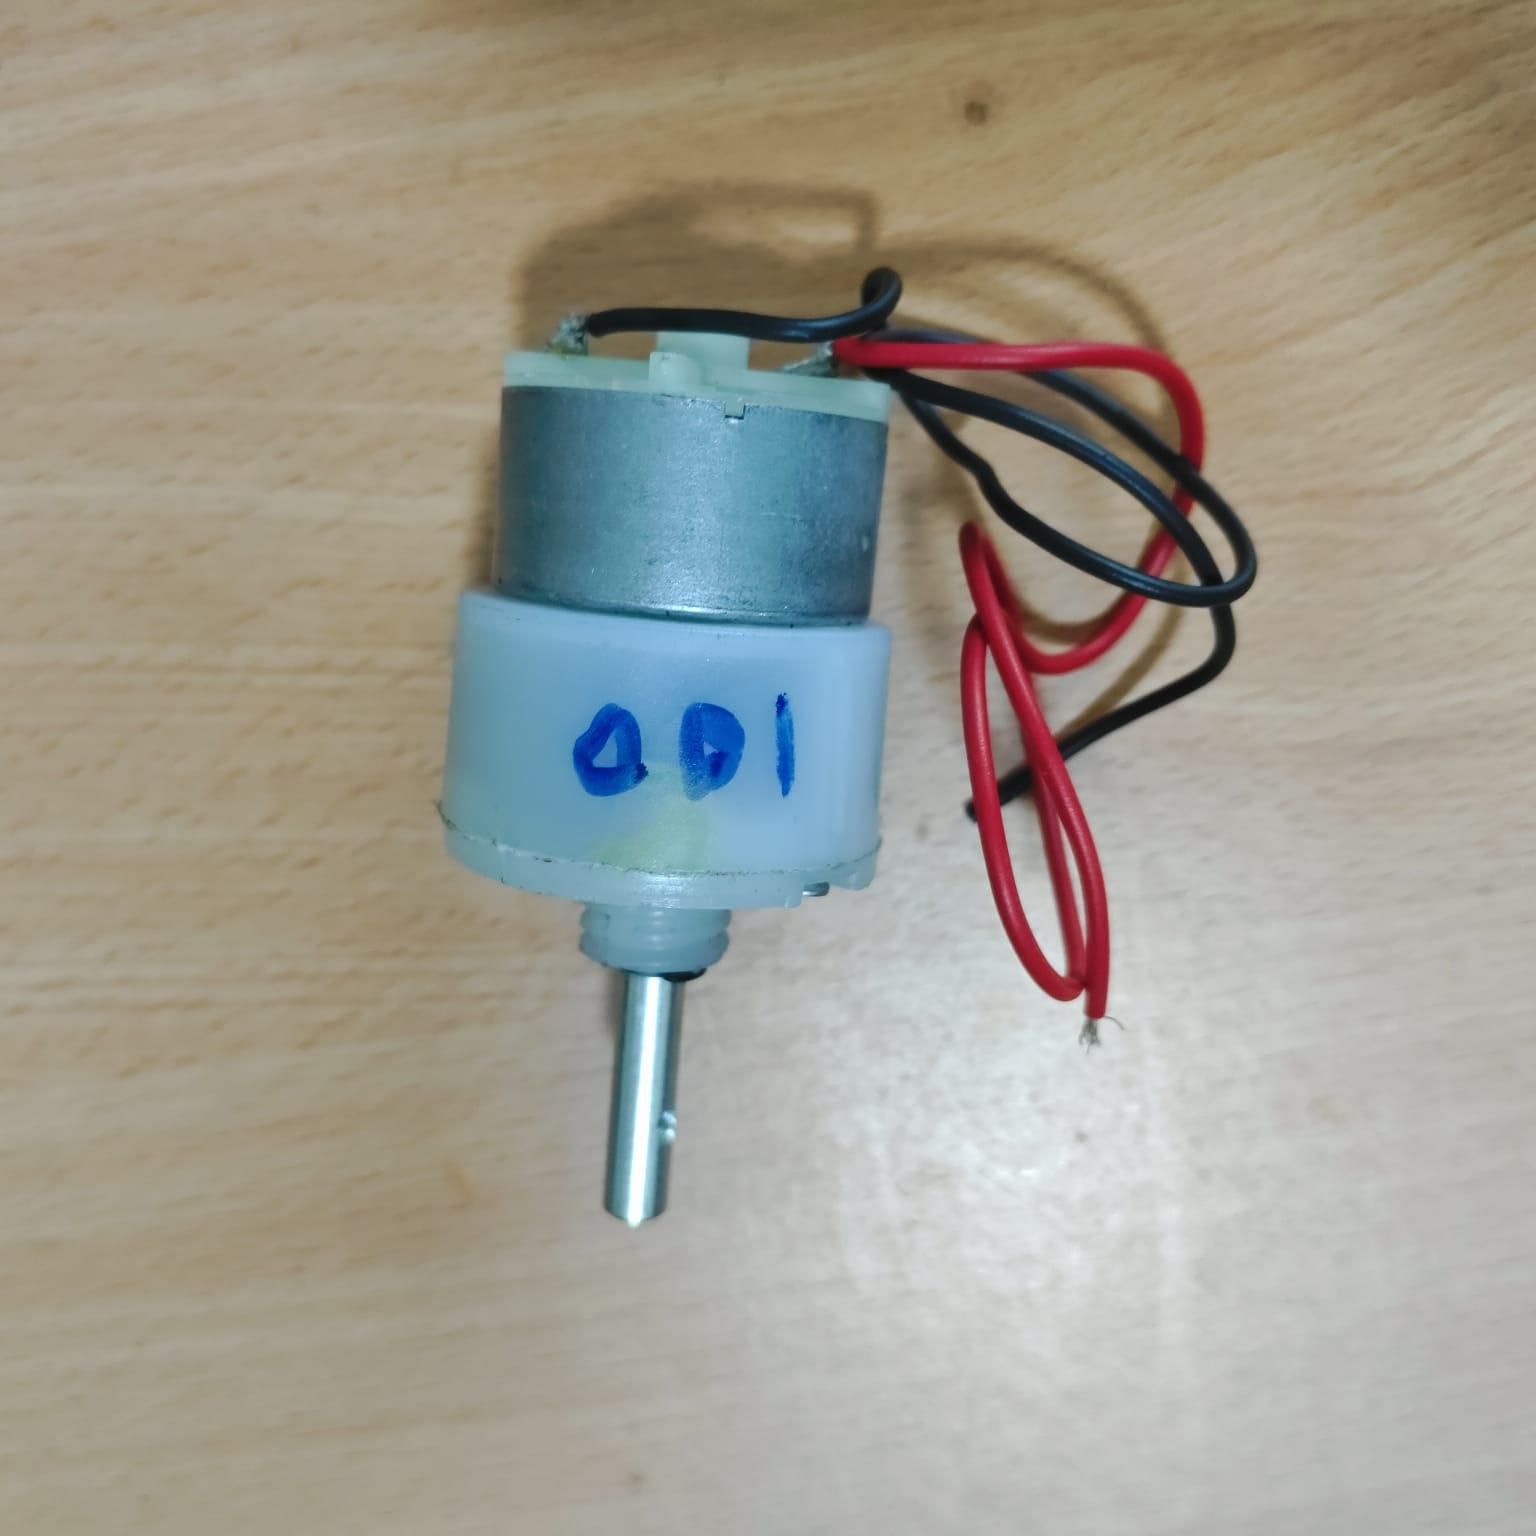


Deshbot Shield
Arduino Uno/Nano
HC-05 Bluetooth module
HC-SR04 ultrasonic sensor
Two DC geared motors
RGB LED
Robot chassis
Wheels
Battery
Bluetooth controller/mobile application
Objectives
The main objectives of this project are:
- To build a wireless Bluetooth-controlled robot.
- To control two DC motors using an Arduino and motor driver.
- To use an ultrasonic sensor for obstacle detection.
- To automatically stop or change direction when an obstacle is detected.
- To understand Bluetooth communication with Arduino.
- To demonstrate basic robotic movement and control.
- To use an LED as a simple status indicator.
Bluetooth Control

The Bluetooth system provides wireless control of the robot.
The controller can be programmed with commands such as:
CommandRobot Action
Forward
Move forward
Backward
Move backward
Left
Turn left
Right
Turn right
Stop
Stop both motors
The exact Bluetooth characters can be assigned according to the controller program.
Conclusion
The Bluetooth-Controlled Obstacle-Avoiding Robot demonstrates how an Arduino can combine wireless communication, ultrasonic sensing, motor control, and LED indication to operate a robotic vehicle.
The Bluetooth controller provides wireless movement control, while the ultrasonic sensor allows the robot to detect obstacles and perform an avoidance sequence. The project provides practical experience with Arduino programming, electronic connections, sensors, motor drivers, and robotics.
Overall, the project is a useful foundation for developing more advanced autonomous and remotely controlled robotic systems.