Build a 3D Printed Micromanipulator V2 (with a Switchable Magnetic Base)
by Remi_Rafael in Workshop > Science
382 Views, 2 Favorites, 0 Comments
Build a 3D Printed Micromanipulator V2 (with a Switchable Magnetic Base)

This tutorial will show you how to build a 3D-printed micromanipulator. This is an updated version of the micromanipulator I published two years ago, but it includes several significant changes.
If you are new to micromanipulators, they are tools designed to precisely position and manipulate objects at the micron scale. They are very useful, but also very expensive tools in microelectronics. This project is the result of my effort to design a capable, low-cost, DIY alternative based on 3D printing.
To achieve smooth motion between the 3D-printed parts, I use metal rods as sliding elements. The axes are also spring-loaded to counter backlash. The result is a sensitive yet capable device that can position a tip on pads smaller than 50 micrometers.
Compared to my previous micromanipulator, this version:
- Includes a switchable magnetic base.
- Uses 3 mm slider rods instead of 2 mm for increased rigidity
- Has larger, more ergonomic knobs
- Has an improved tip holder
As building this version requires quite a few more steps, I am making a separate Instructable for it. I will leave the previous tutorial online for people who want to build Version 1.
Supplies

This design relies primarily on 3D-printed parts. However you will also need:
- 12x 12 mm diameter 3 mm thick magnets
- 39x 12mm diameter, 1 mm thick washers (The washers must be magnetic. Use carbon-steel or magnetic steel washers; do not use non-magnetic stainless steel.)
- 4x 10 mm M3 bolts
- 3x 55 mm M3 bolts
- 11x M3 nuts
- 2 or 3 mm metallic rods cut into 4x 45 mm, 4x 65 mm, 3x 52.5 mm
- 3x 40mm springs (40/50 min/max length, 7.5 max outer diameter, 3.5 min inner diameter, 0.6 to 0.8 recommended wire diameter)
You will also need the following tools:
- Vice
- Metal saw
- File
- slightly below 2 or 3 mm drill bit (slightly undersized compared to your metal rod is preferred)
- Electric drill/Screw driver
- Supports removal tools (cutter, pliers...)
- (optional) grease or oil lubricant
- (optional) glue
If you decide to also build the needle tip holder, you will also need:
- 2x M3 4.2 mm OD 4 mm long melt inserts
- 2x 10 mm M3 bolts
- 1x 14 to 20 mm M3 bolt
- 4x 10 to 15 mm M3 bolt
- 1x M3 nut
- 1x 35 to 50 mm long 2mm thick metal rod
- 1x 3 to 4 mm M2 screw
- 1x spring 6-7 mm OD about 30 mm long
To help you source the hardware, I have provided some links in the last step of this tutorial. These are provided for reference only, and I cannot guarantee the quality of the products.
Print the Parts


To build this project, start by printing the different parts. The STL available on Thingiverse, Printable and Makerworld are pre-oriented and all the required parts are gathered in a single file. Choose the 2 mm or 3 mm version depending on the metal rods you have (3 mm is recommended). For esthetical reasons, you may choose to print the knobs and the lever in a different color. If you use Bambu Studio, you can directly use the 3mf I provide. Otherwise I recommend to print all the parts in PLA+ or PETG with 0.2 mm layers, 4 walls and 25% infill except for the TPU pads that should be printed with 60% infill. Supports are required.
Install the Magnets

For a short introduction to the switchable magnetic mechanism, you can refer to Step 8 of my instructable on building a On/Off magnetic base.
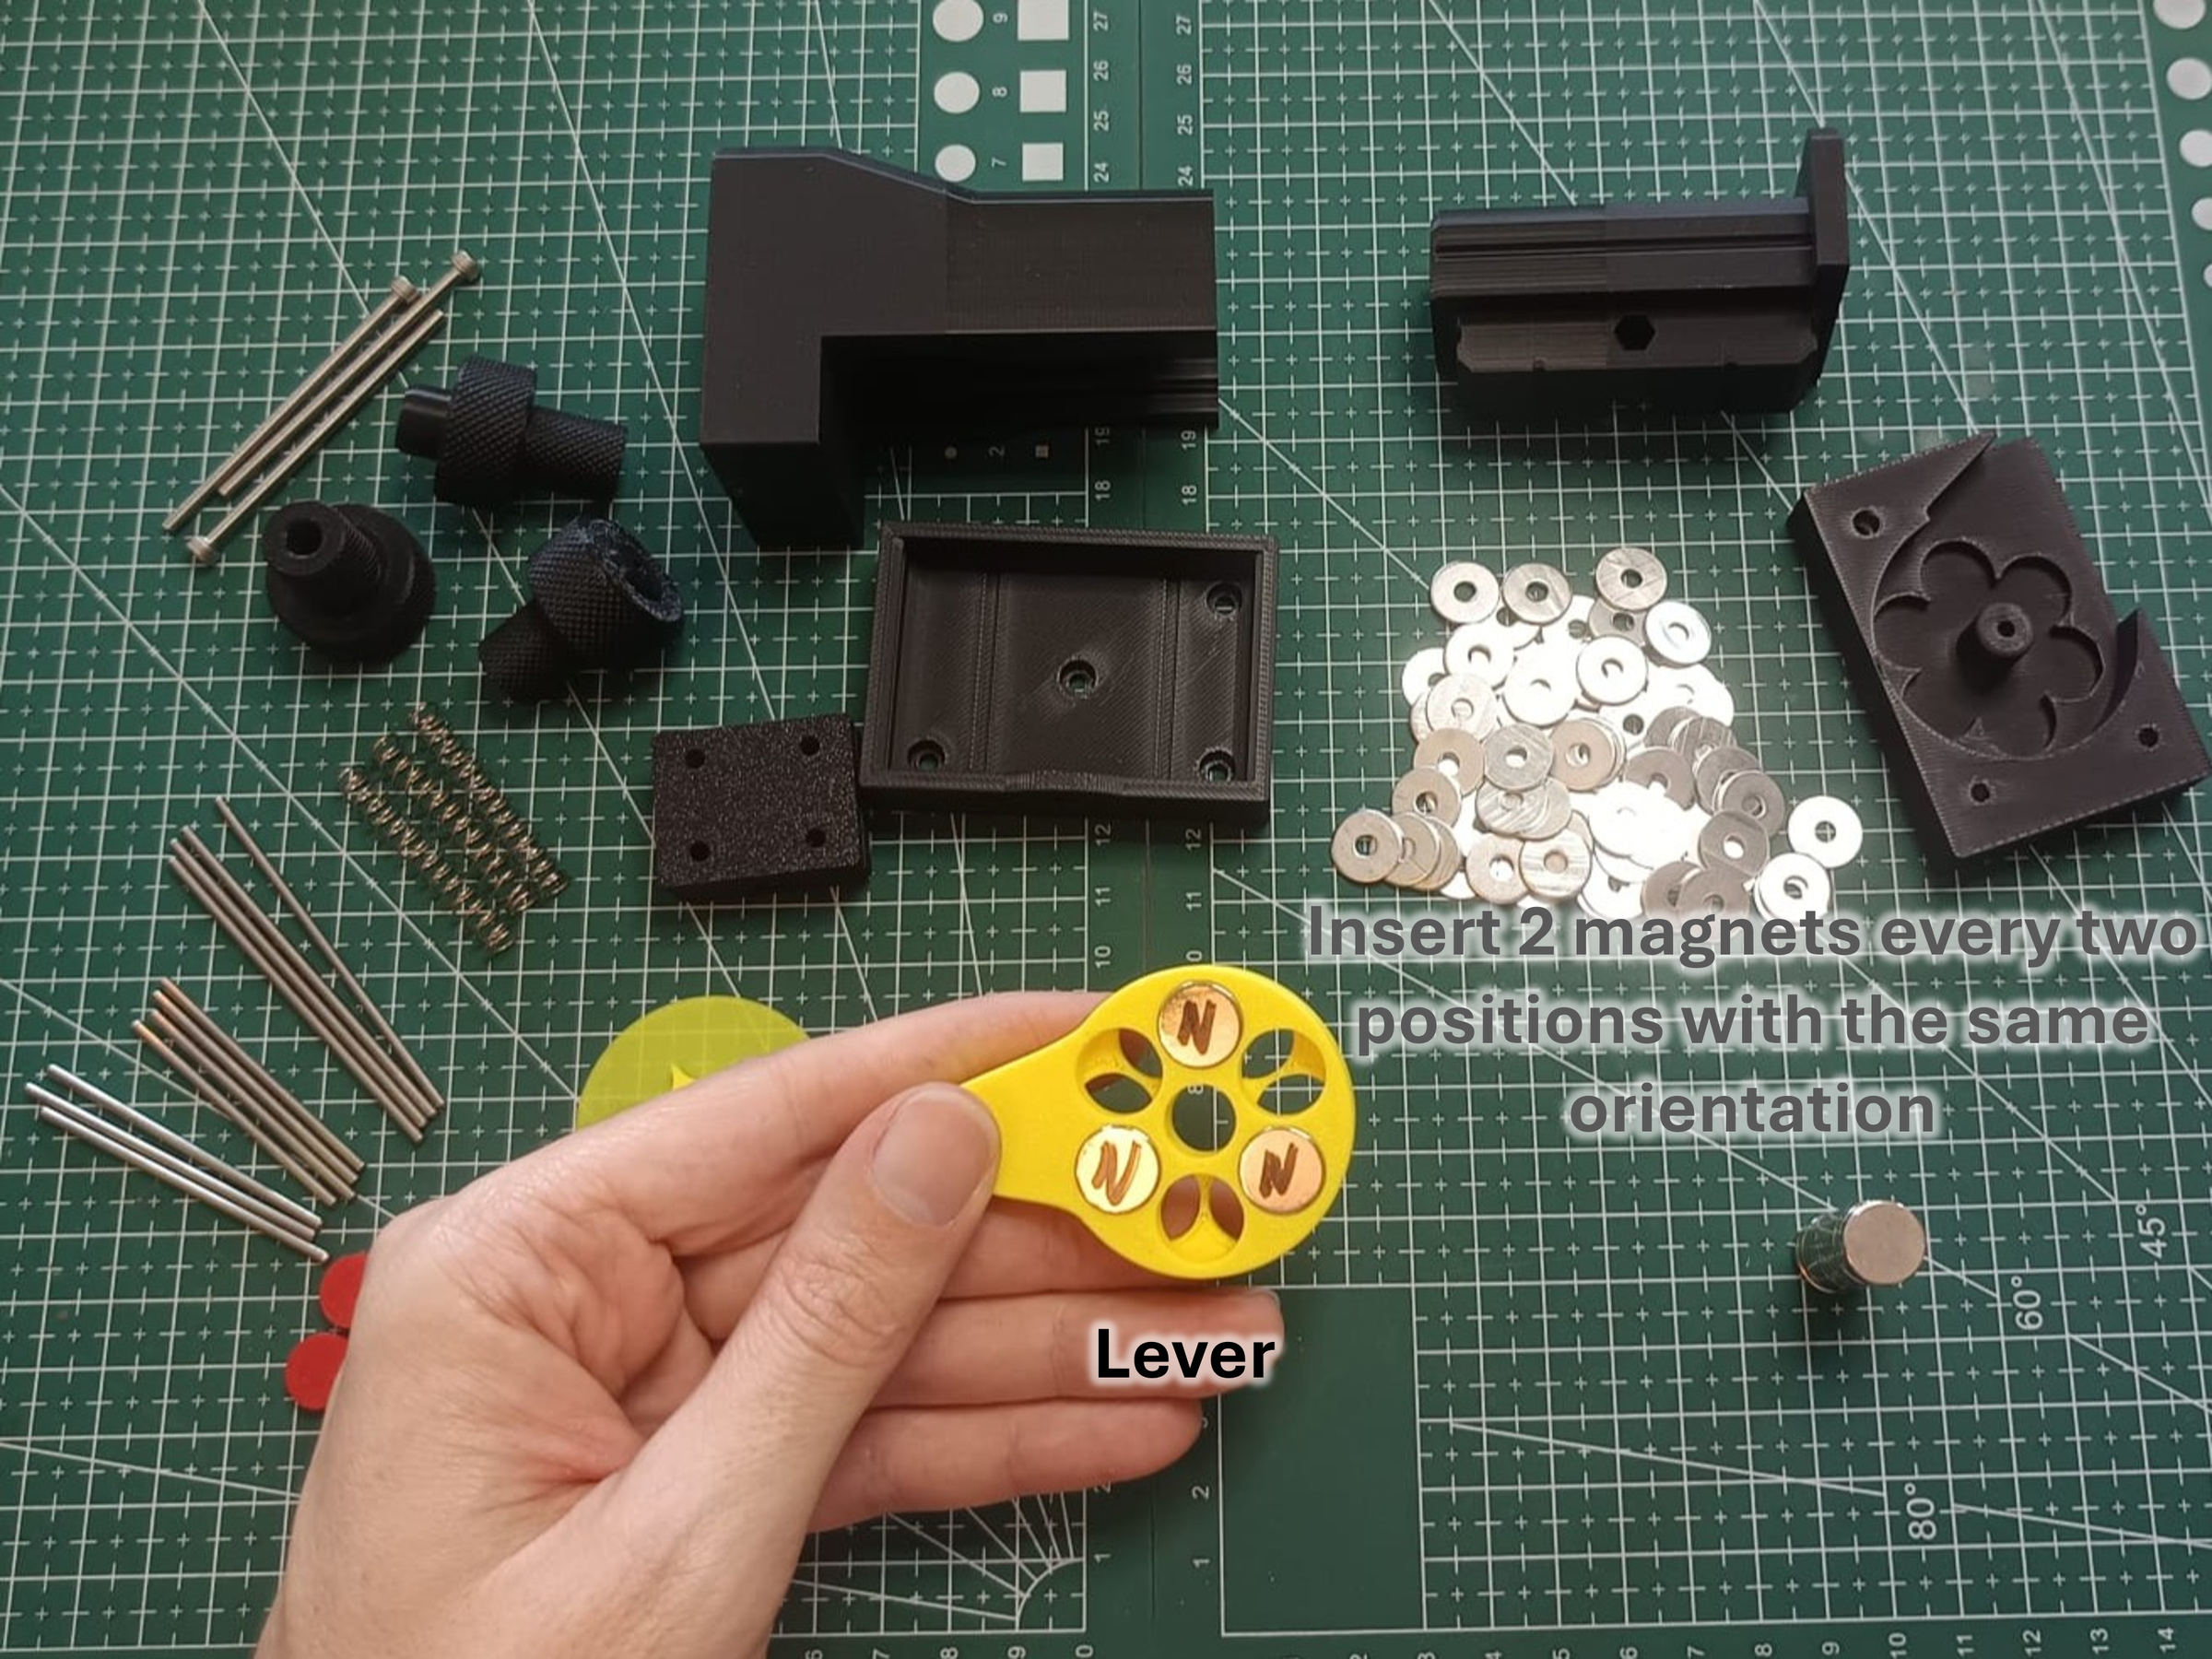
To start the build, use a vice or a hammer to insert the M3 nuts into the micromanipulator base. Then take the lever and insert magnets into half of the holes on the bottom side, making sure that all the magnets are oriented in the same direction. To identify the bottom, place the base part on your table and present the lever. When oriented upside up, the lever should naturally align with the base corner.
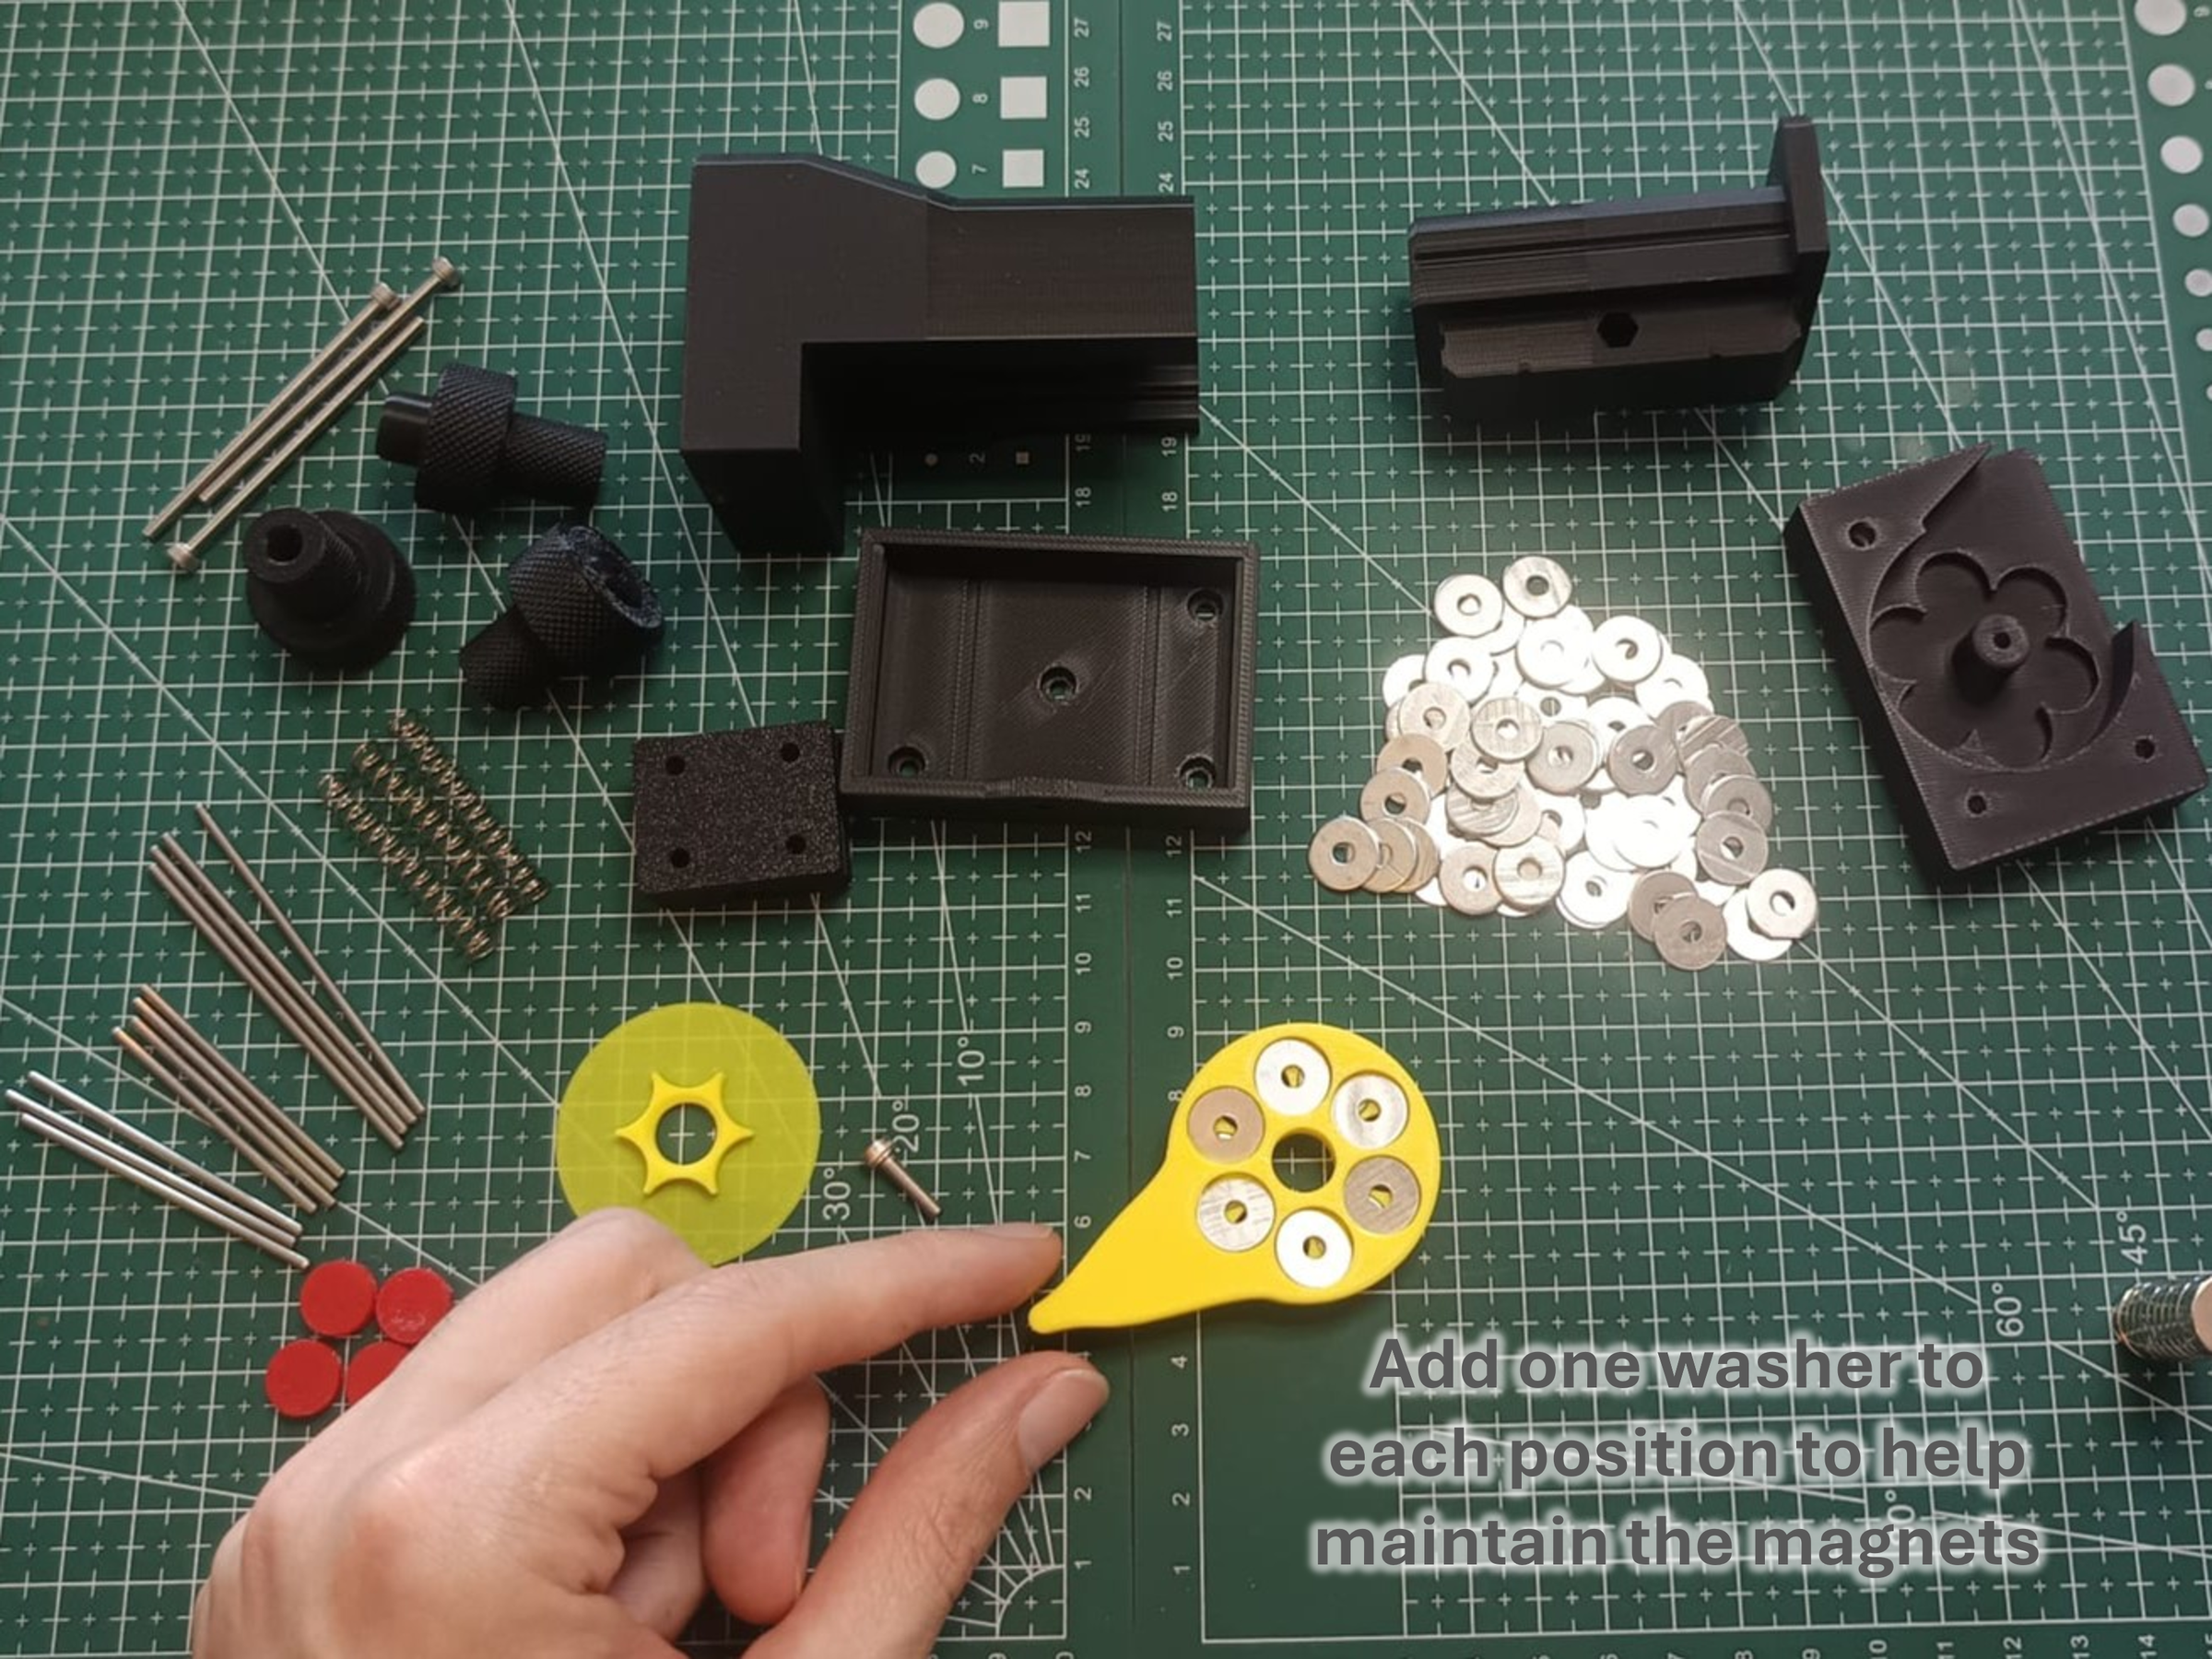
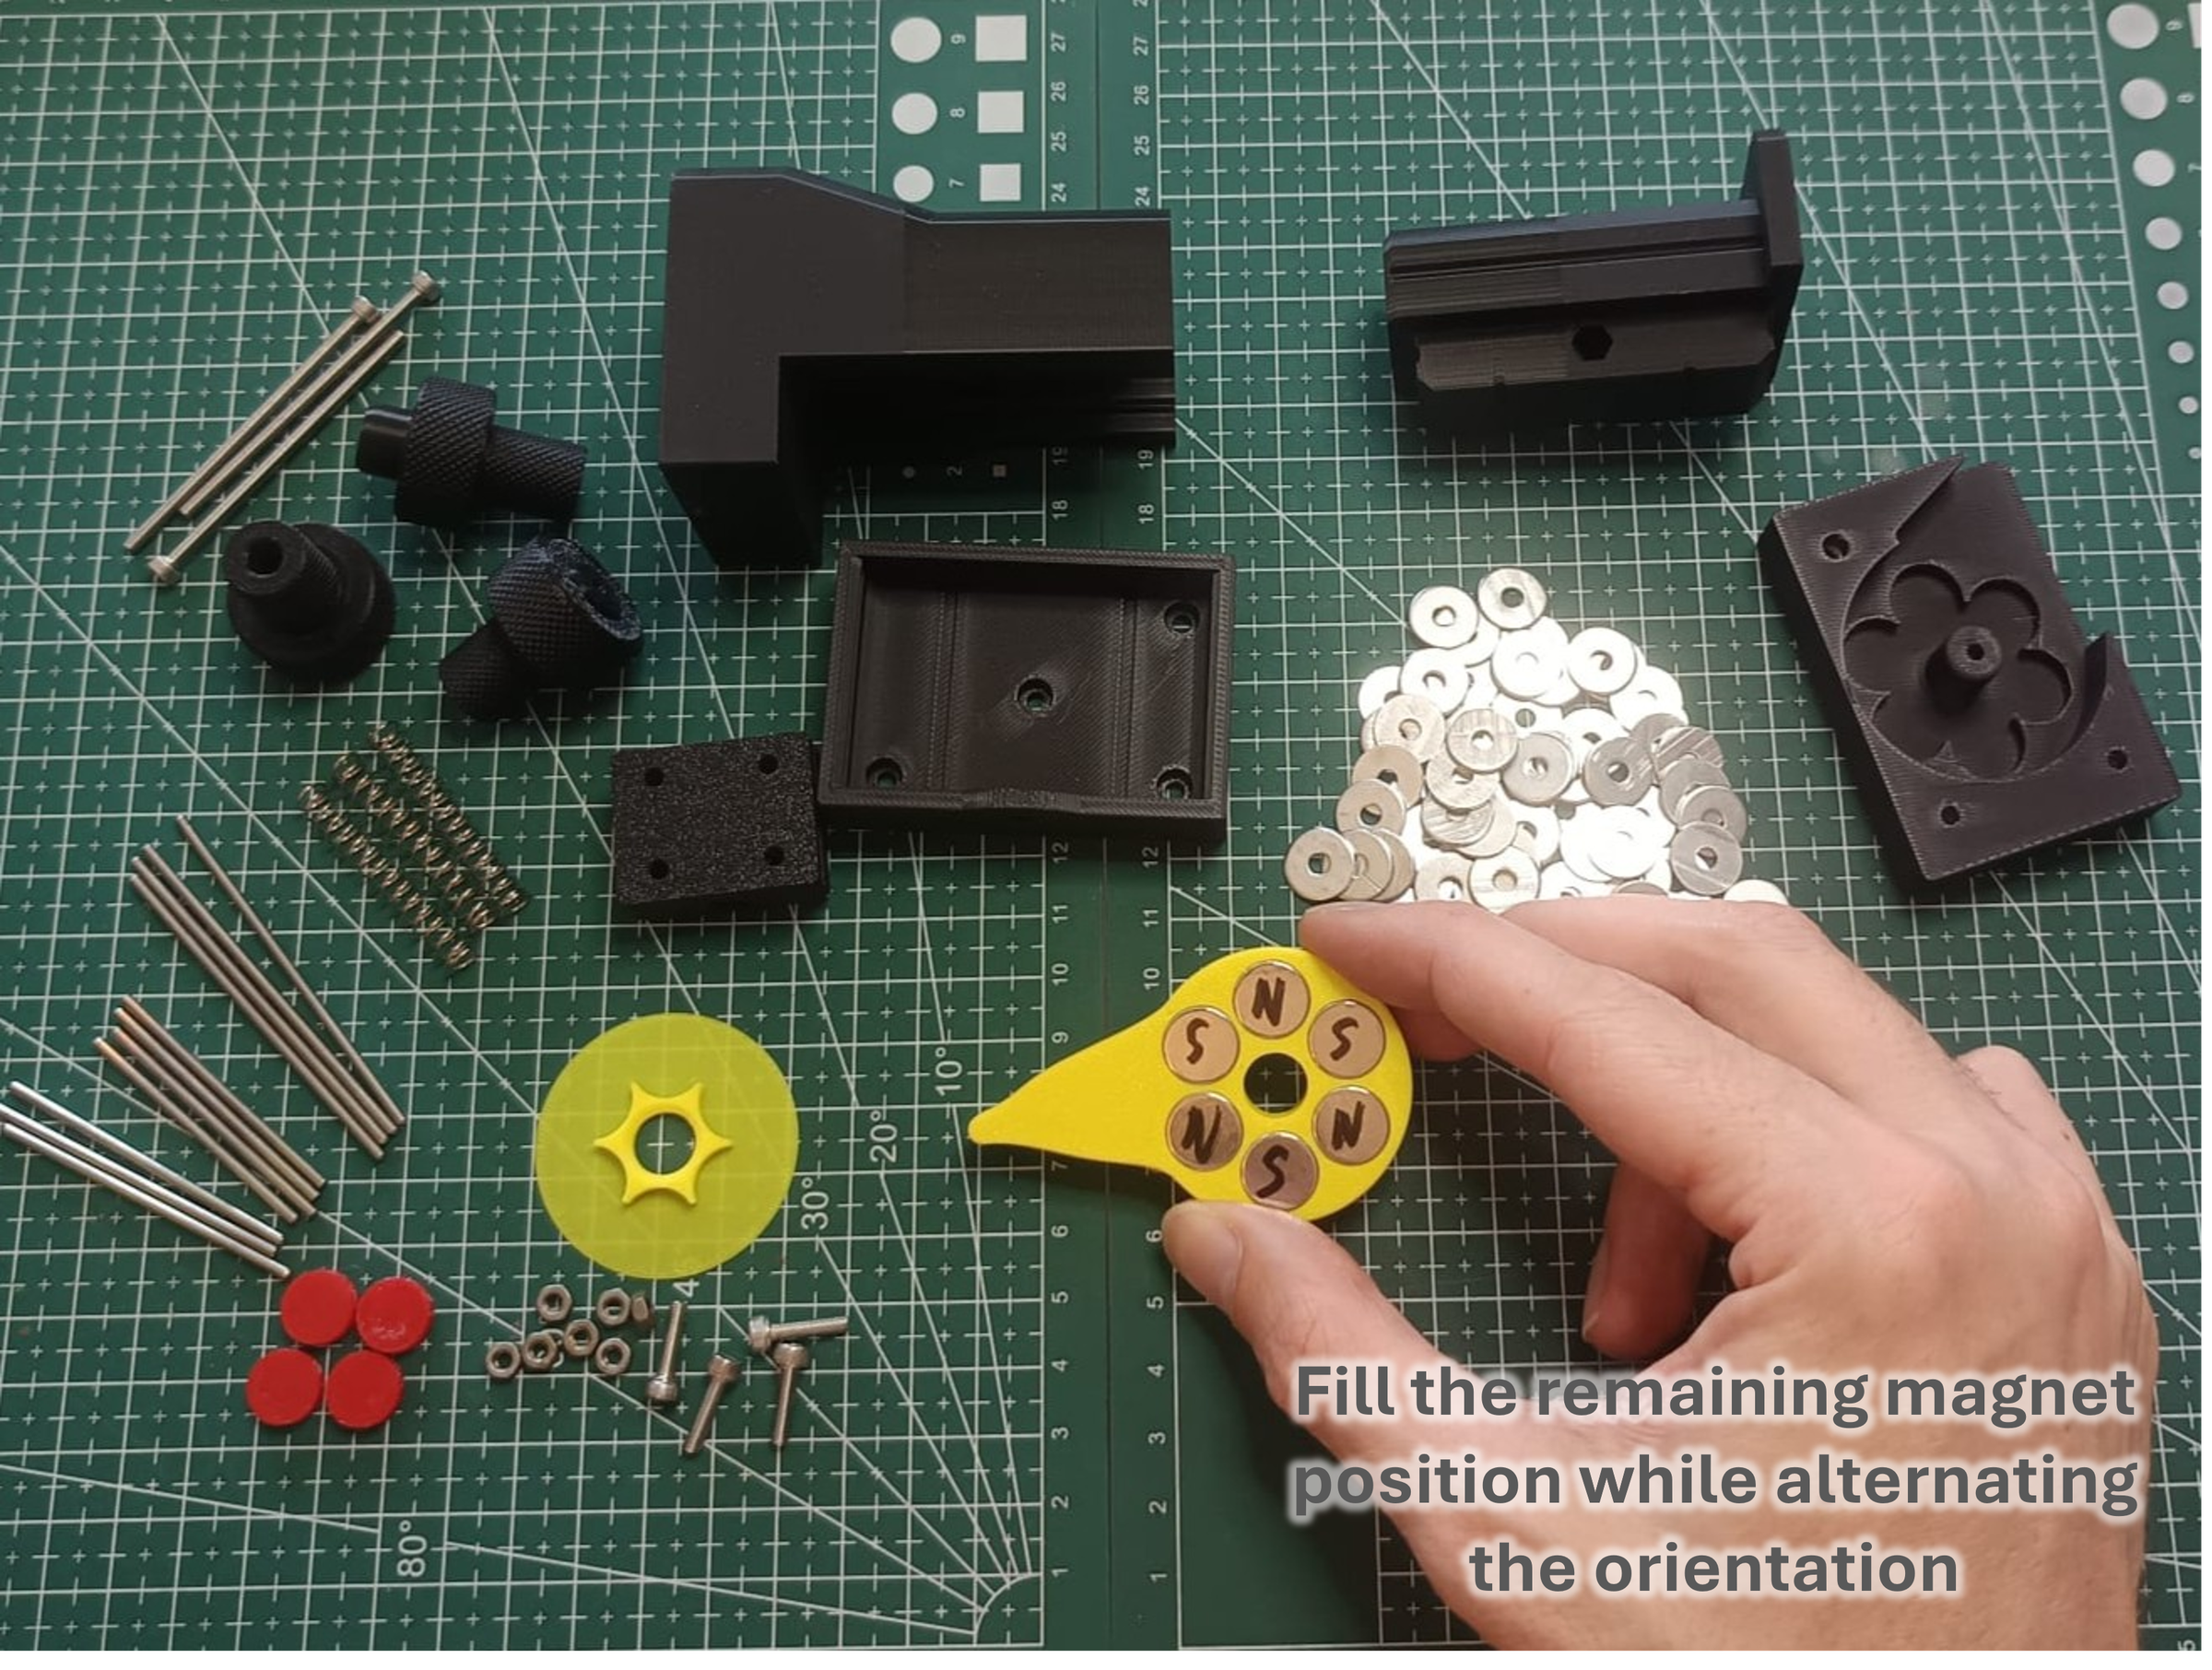
Once the first magnets are installed, turn the lever upside down and add one washer to each hole. These washers will hold the previously installed magnets in place and make the next steps easier. Then fill the remaining holes on the bottom side with magnets, making sure that their orientation alternates from one hole to the next.
Once all the magnets are installed, finish filling the top side with washers. Each hole should contain three washers. The washer stacks should not protrude above the surface of the lever. If the washers have sharp edges that prevent them from forming a compact stack, use a file to smooth the edges.
Install the Washer Retainer


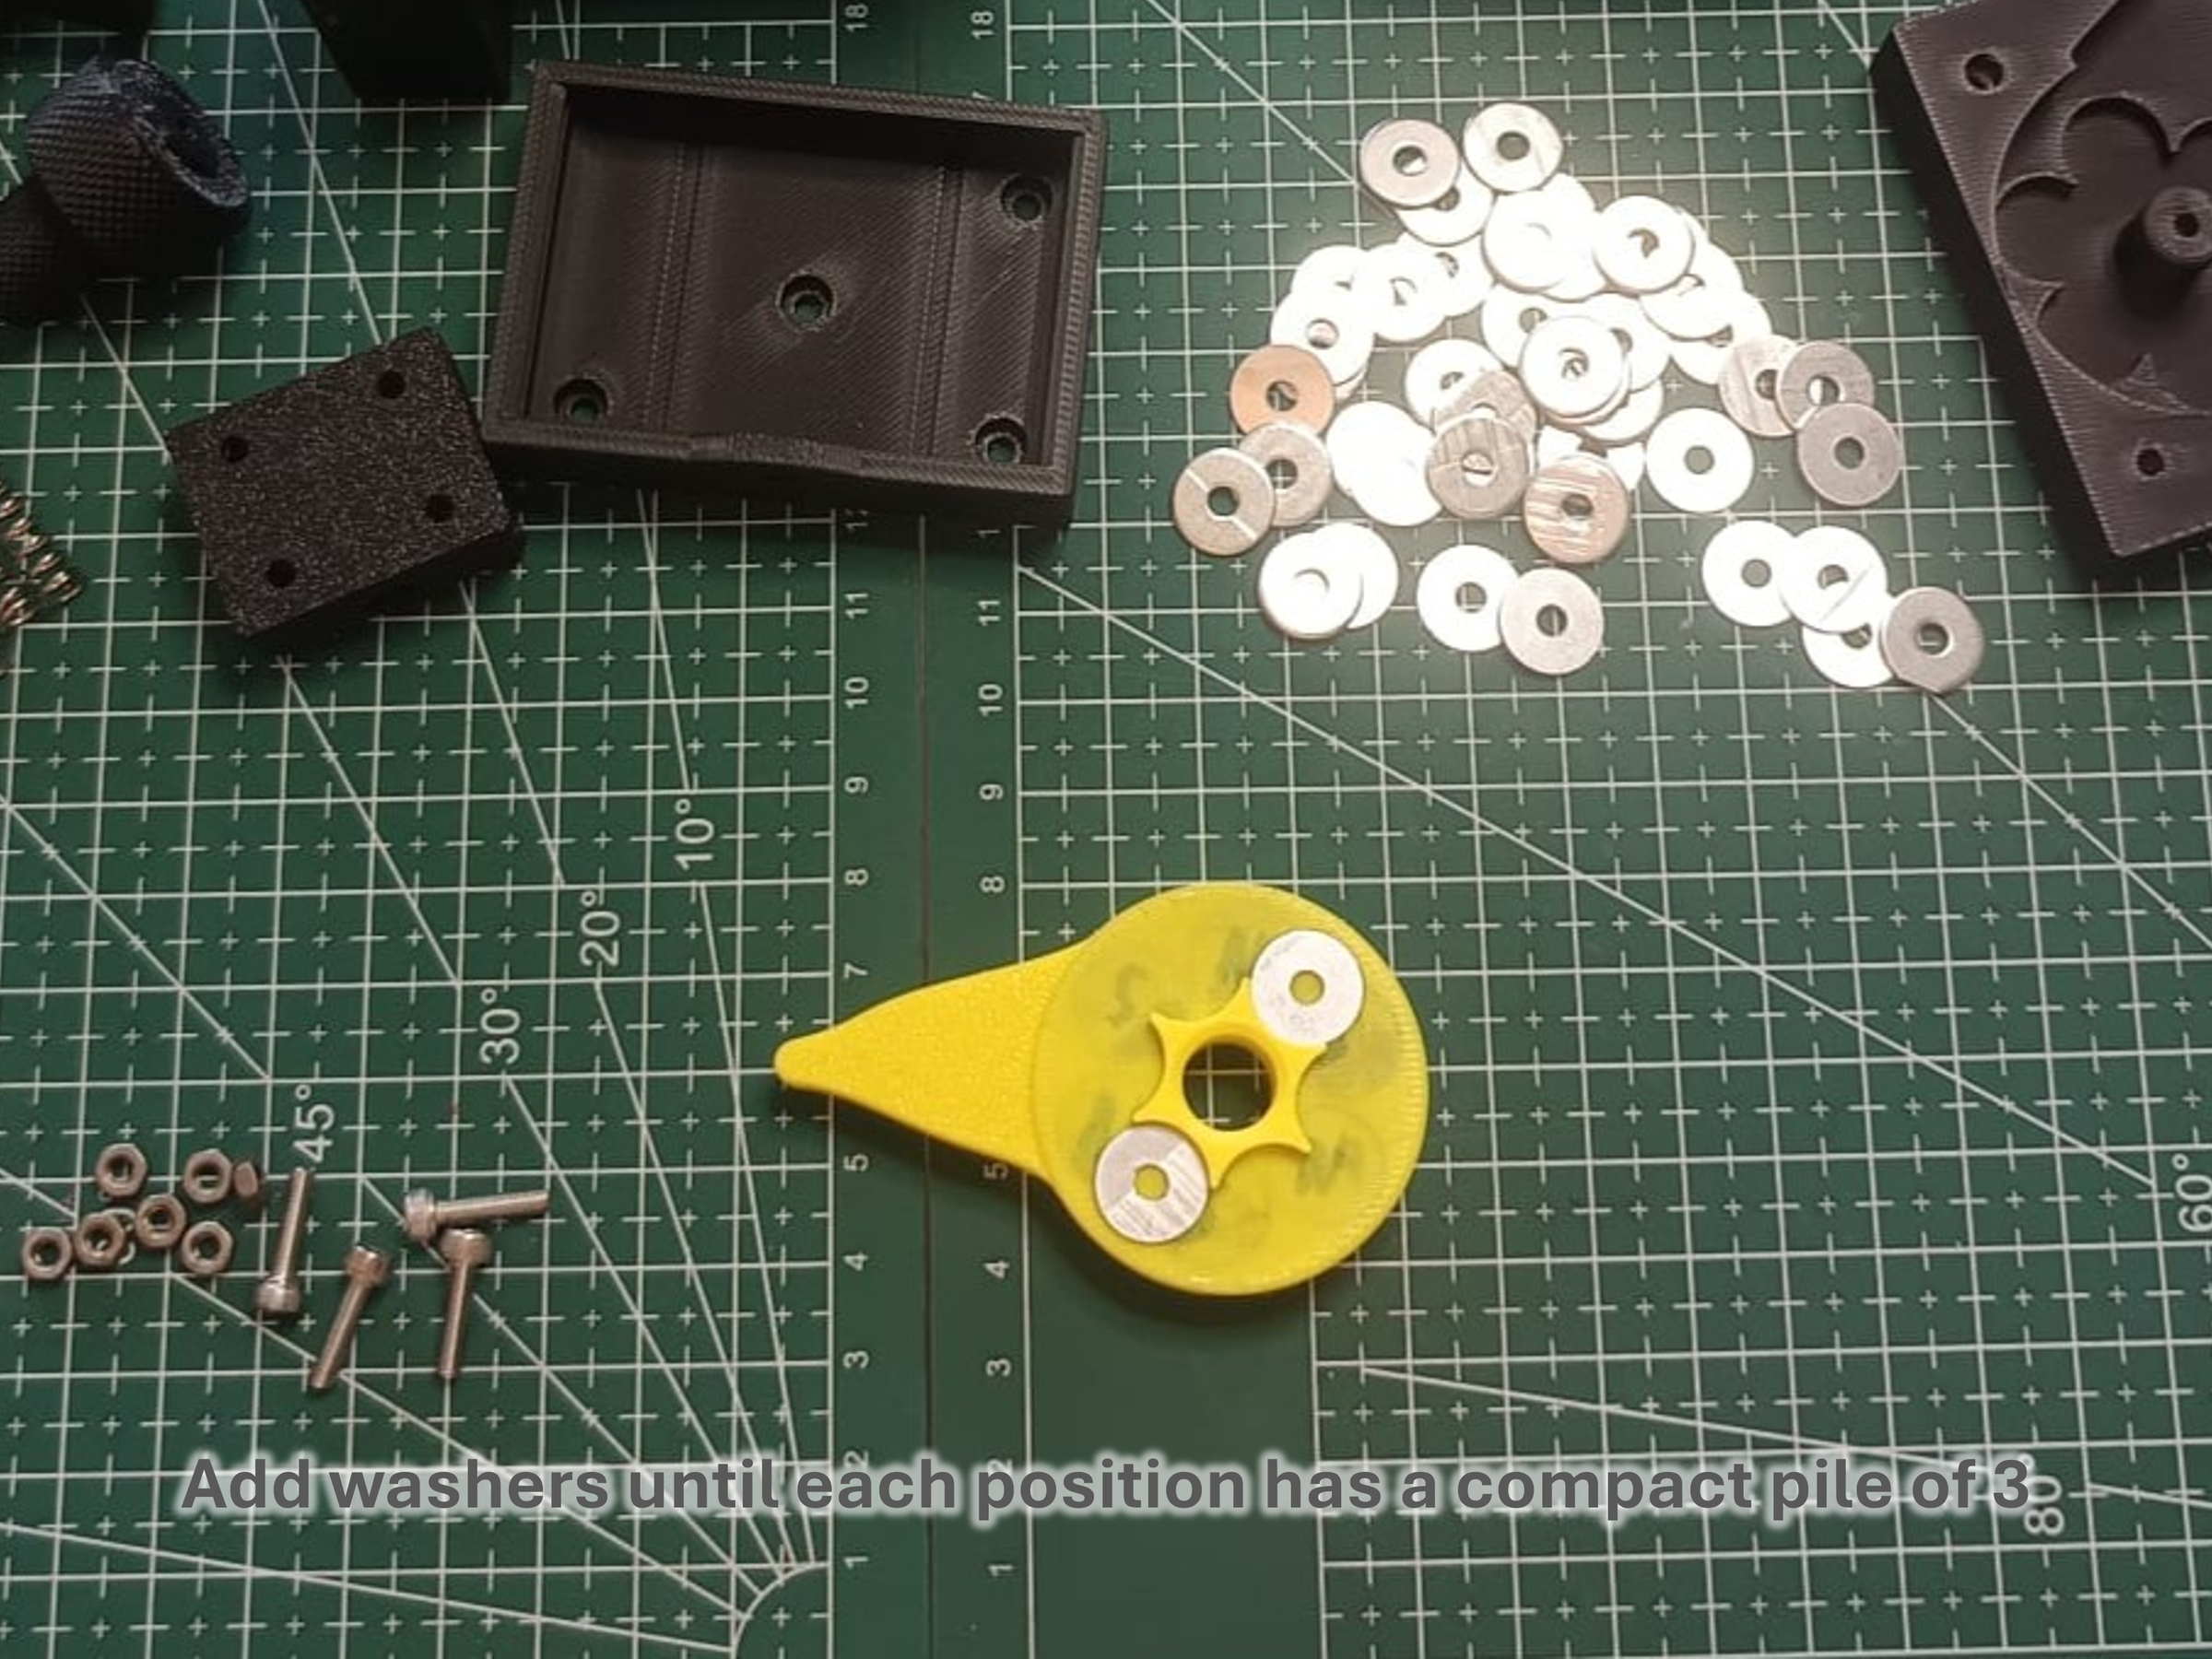
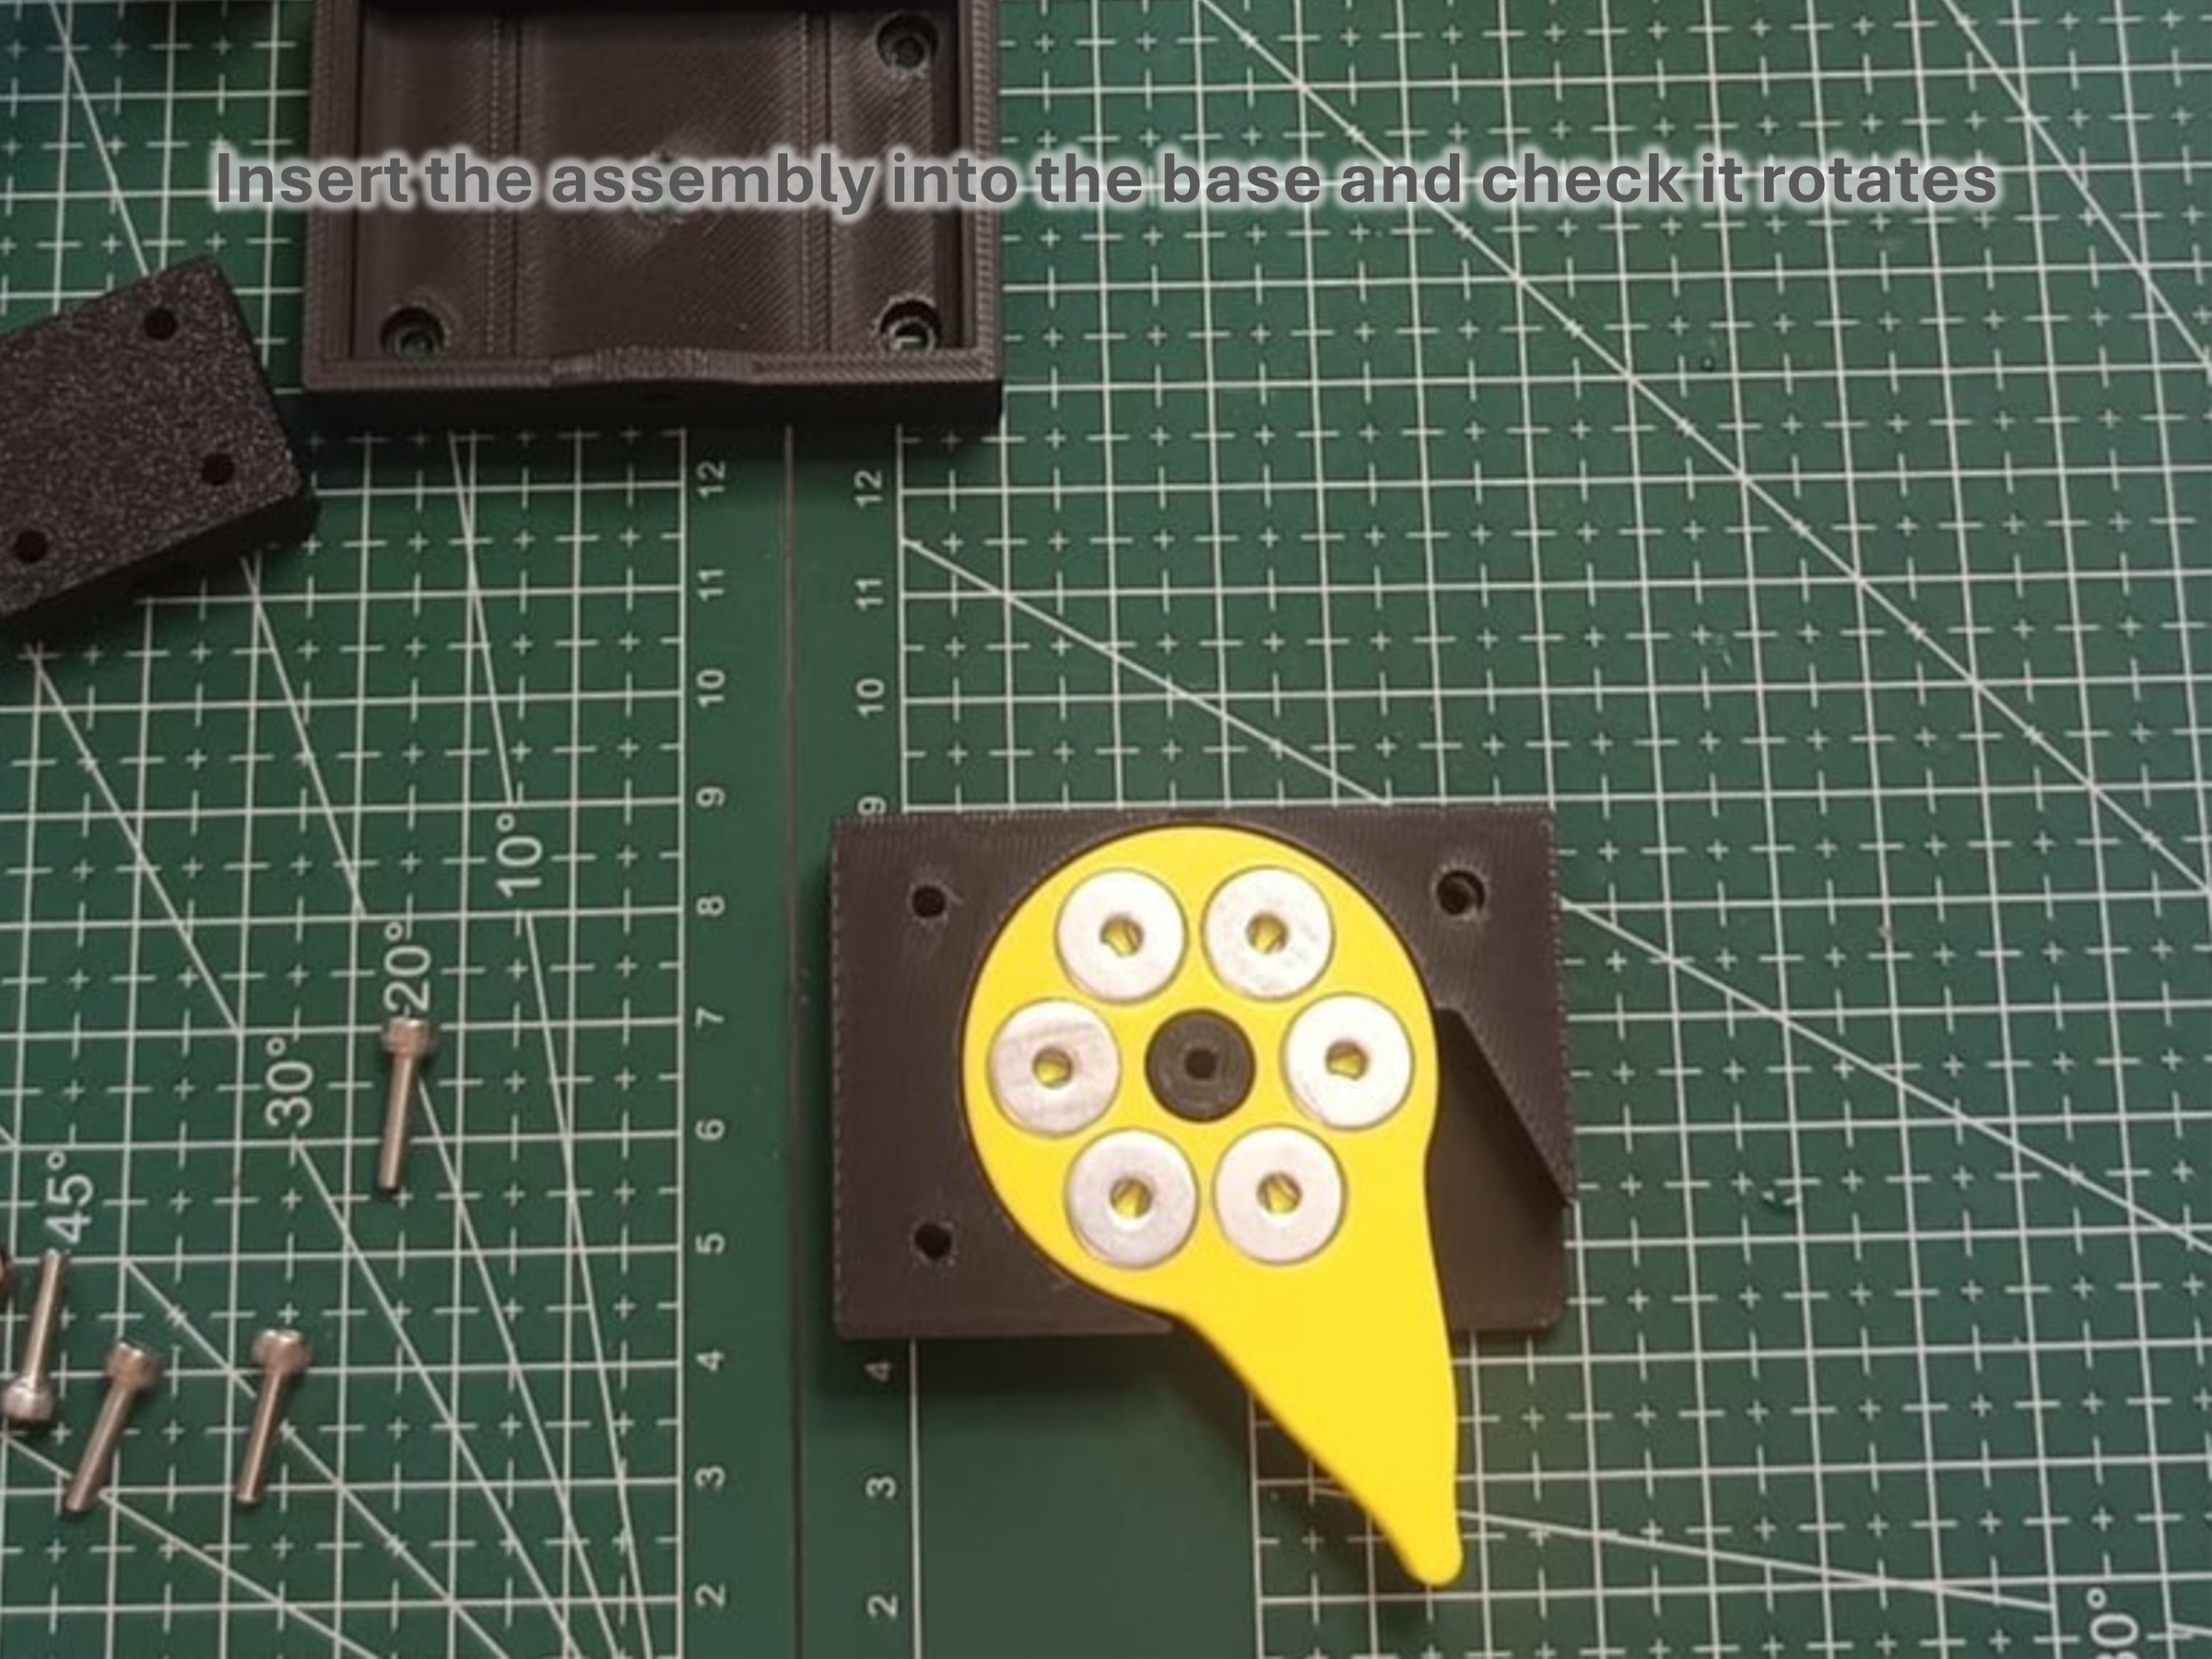
To ensure smooth operation of the lever, you can apply a small amount of industrial grease or oil to the top of the magnets. Then take the washer retainer and place it on top of the magnets, making sure that its edges are positioned over the magnets. Stack three washers at each position, making sure that each stack is compact. File the edges of the washers if necessary.
Once all the washers are installed, insert the assembly into the base with the washer retainer facing downward. Check that the lever can rotate freely and that rotating it switches the magnetic force on and off.
Prepare the Axis Assembly

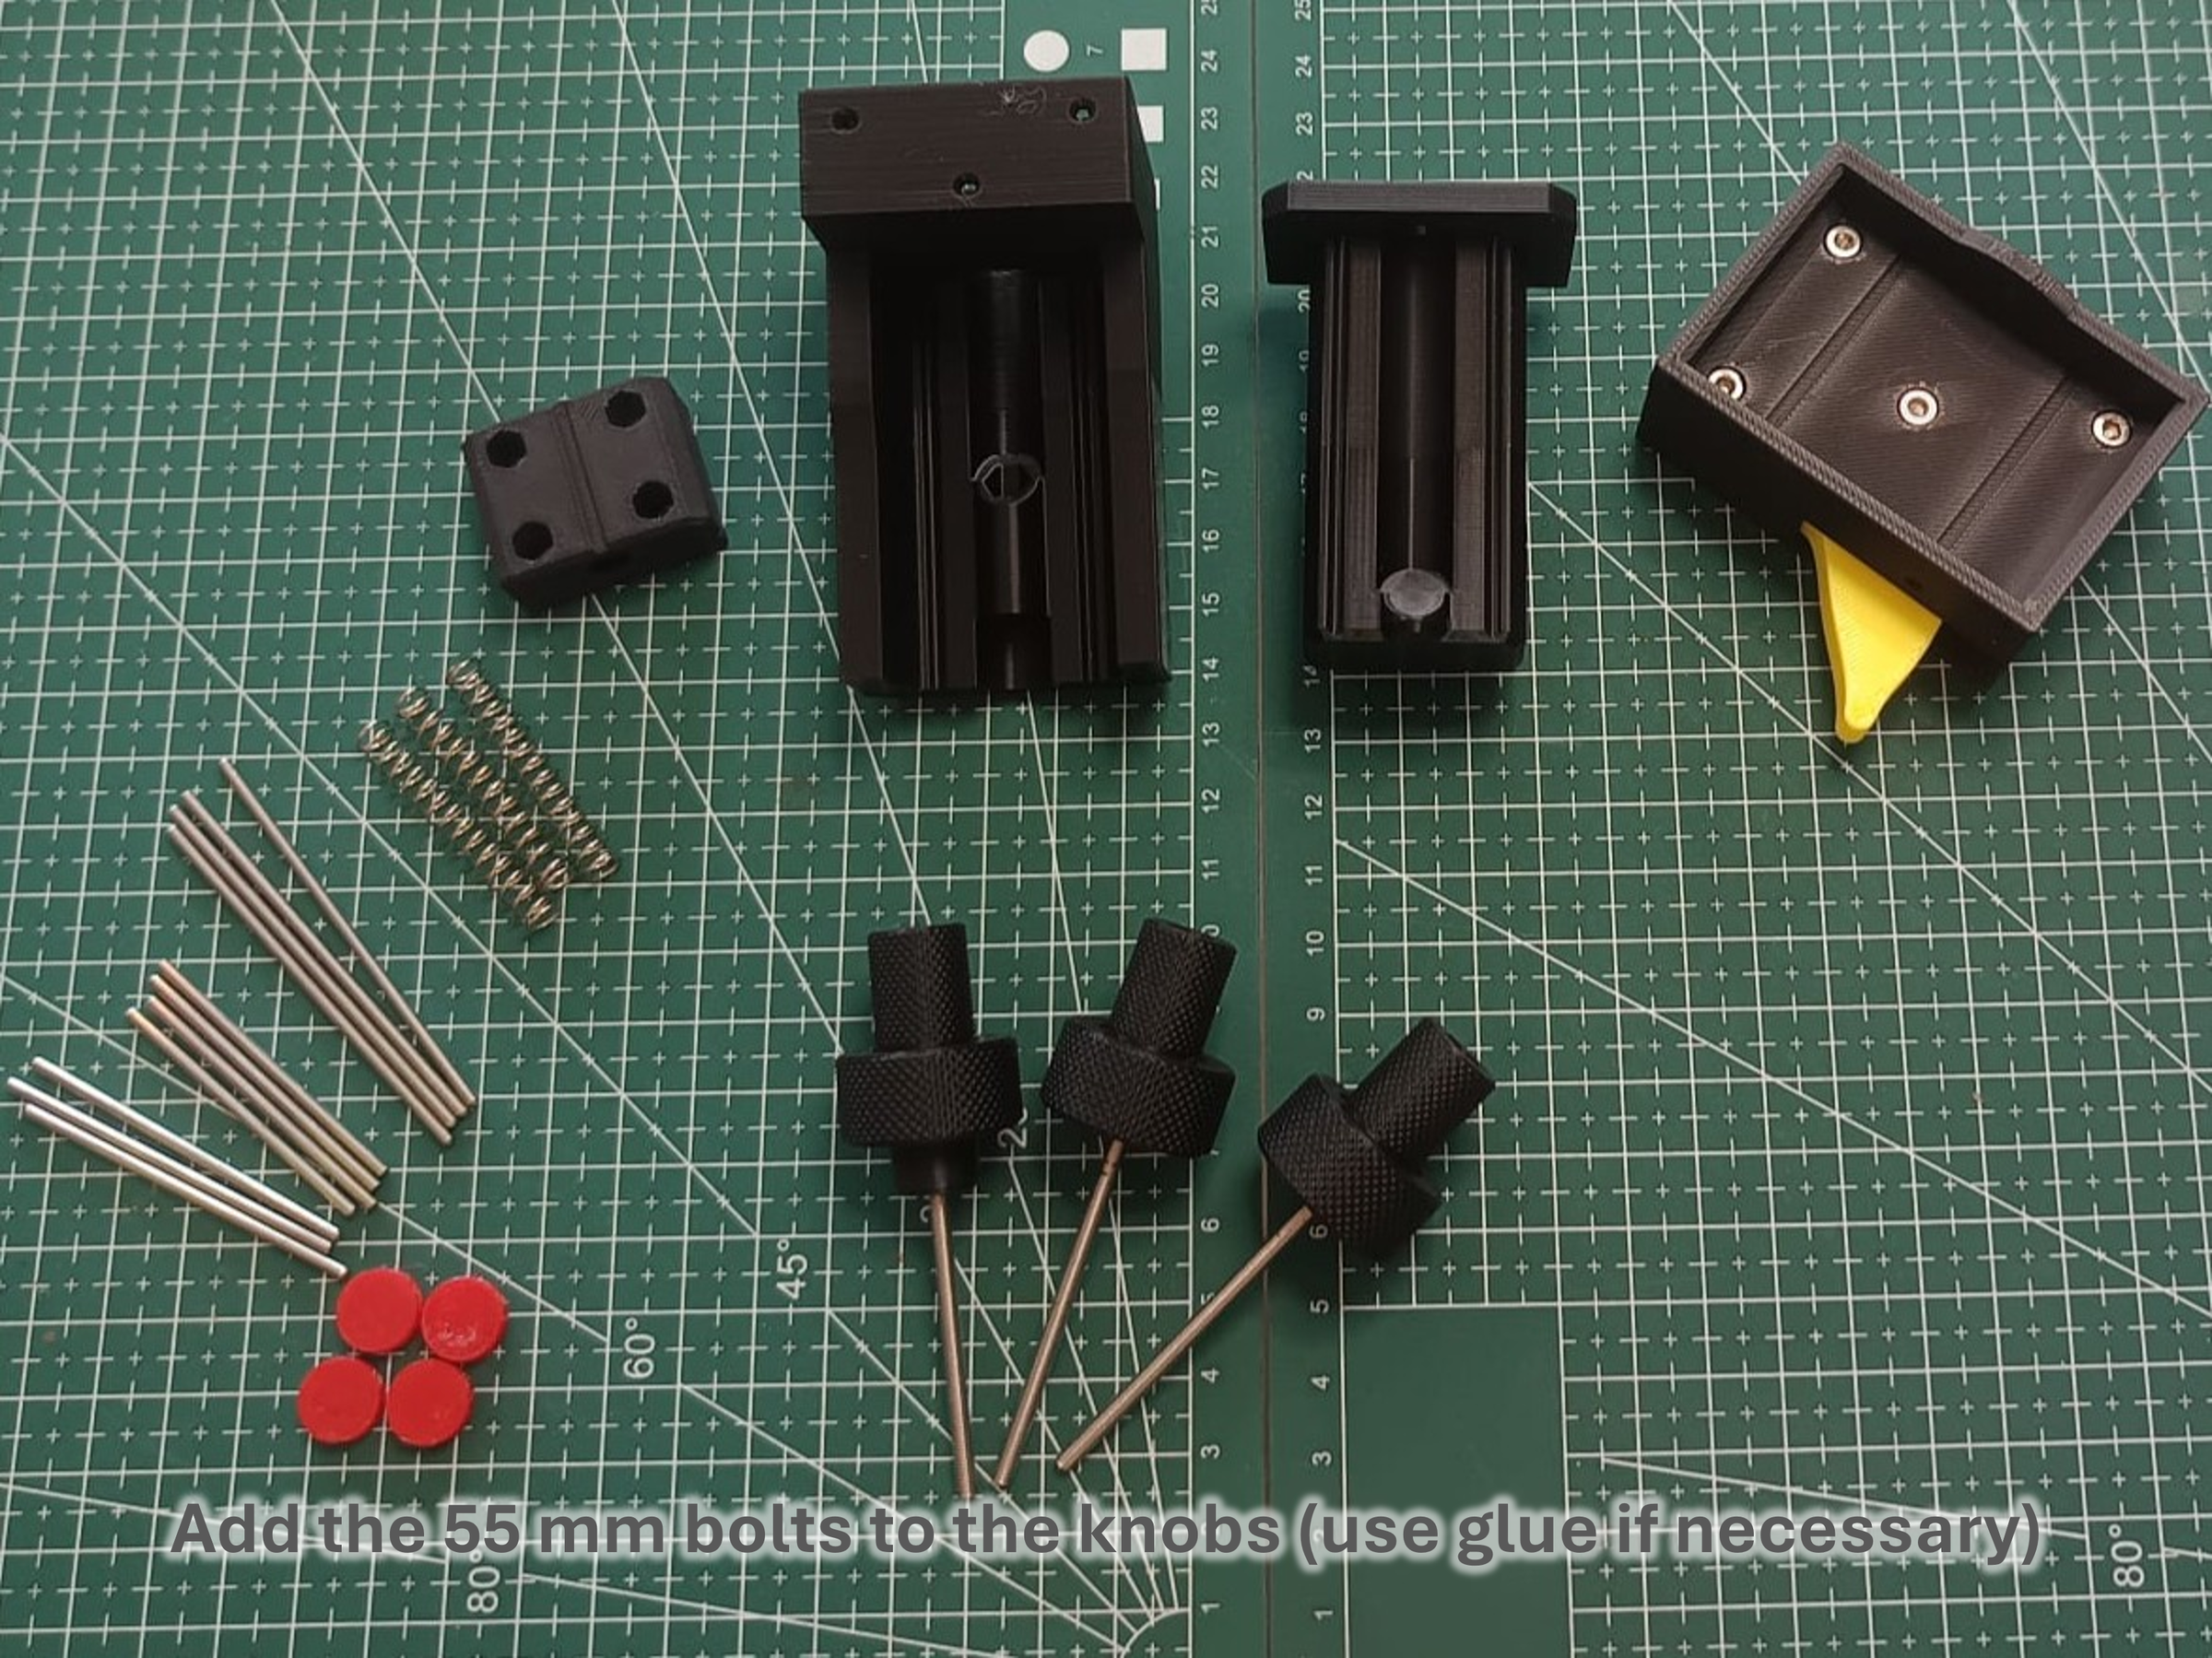
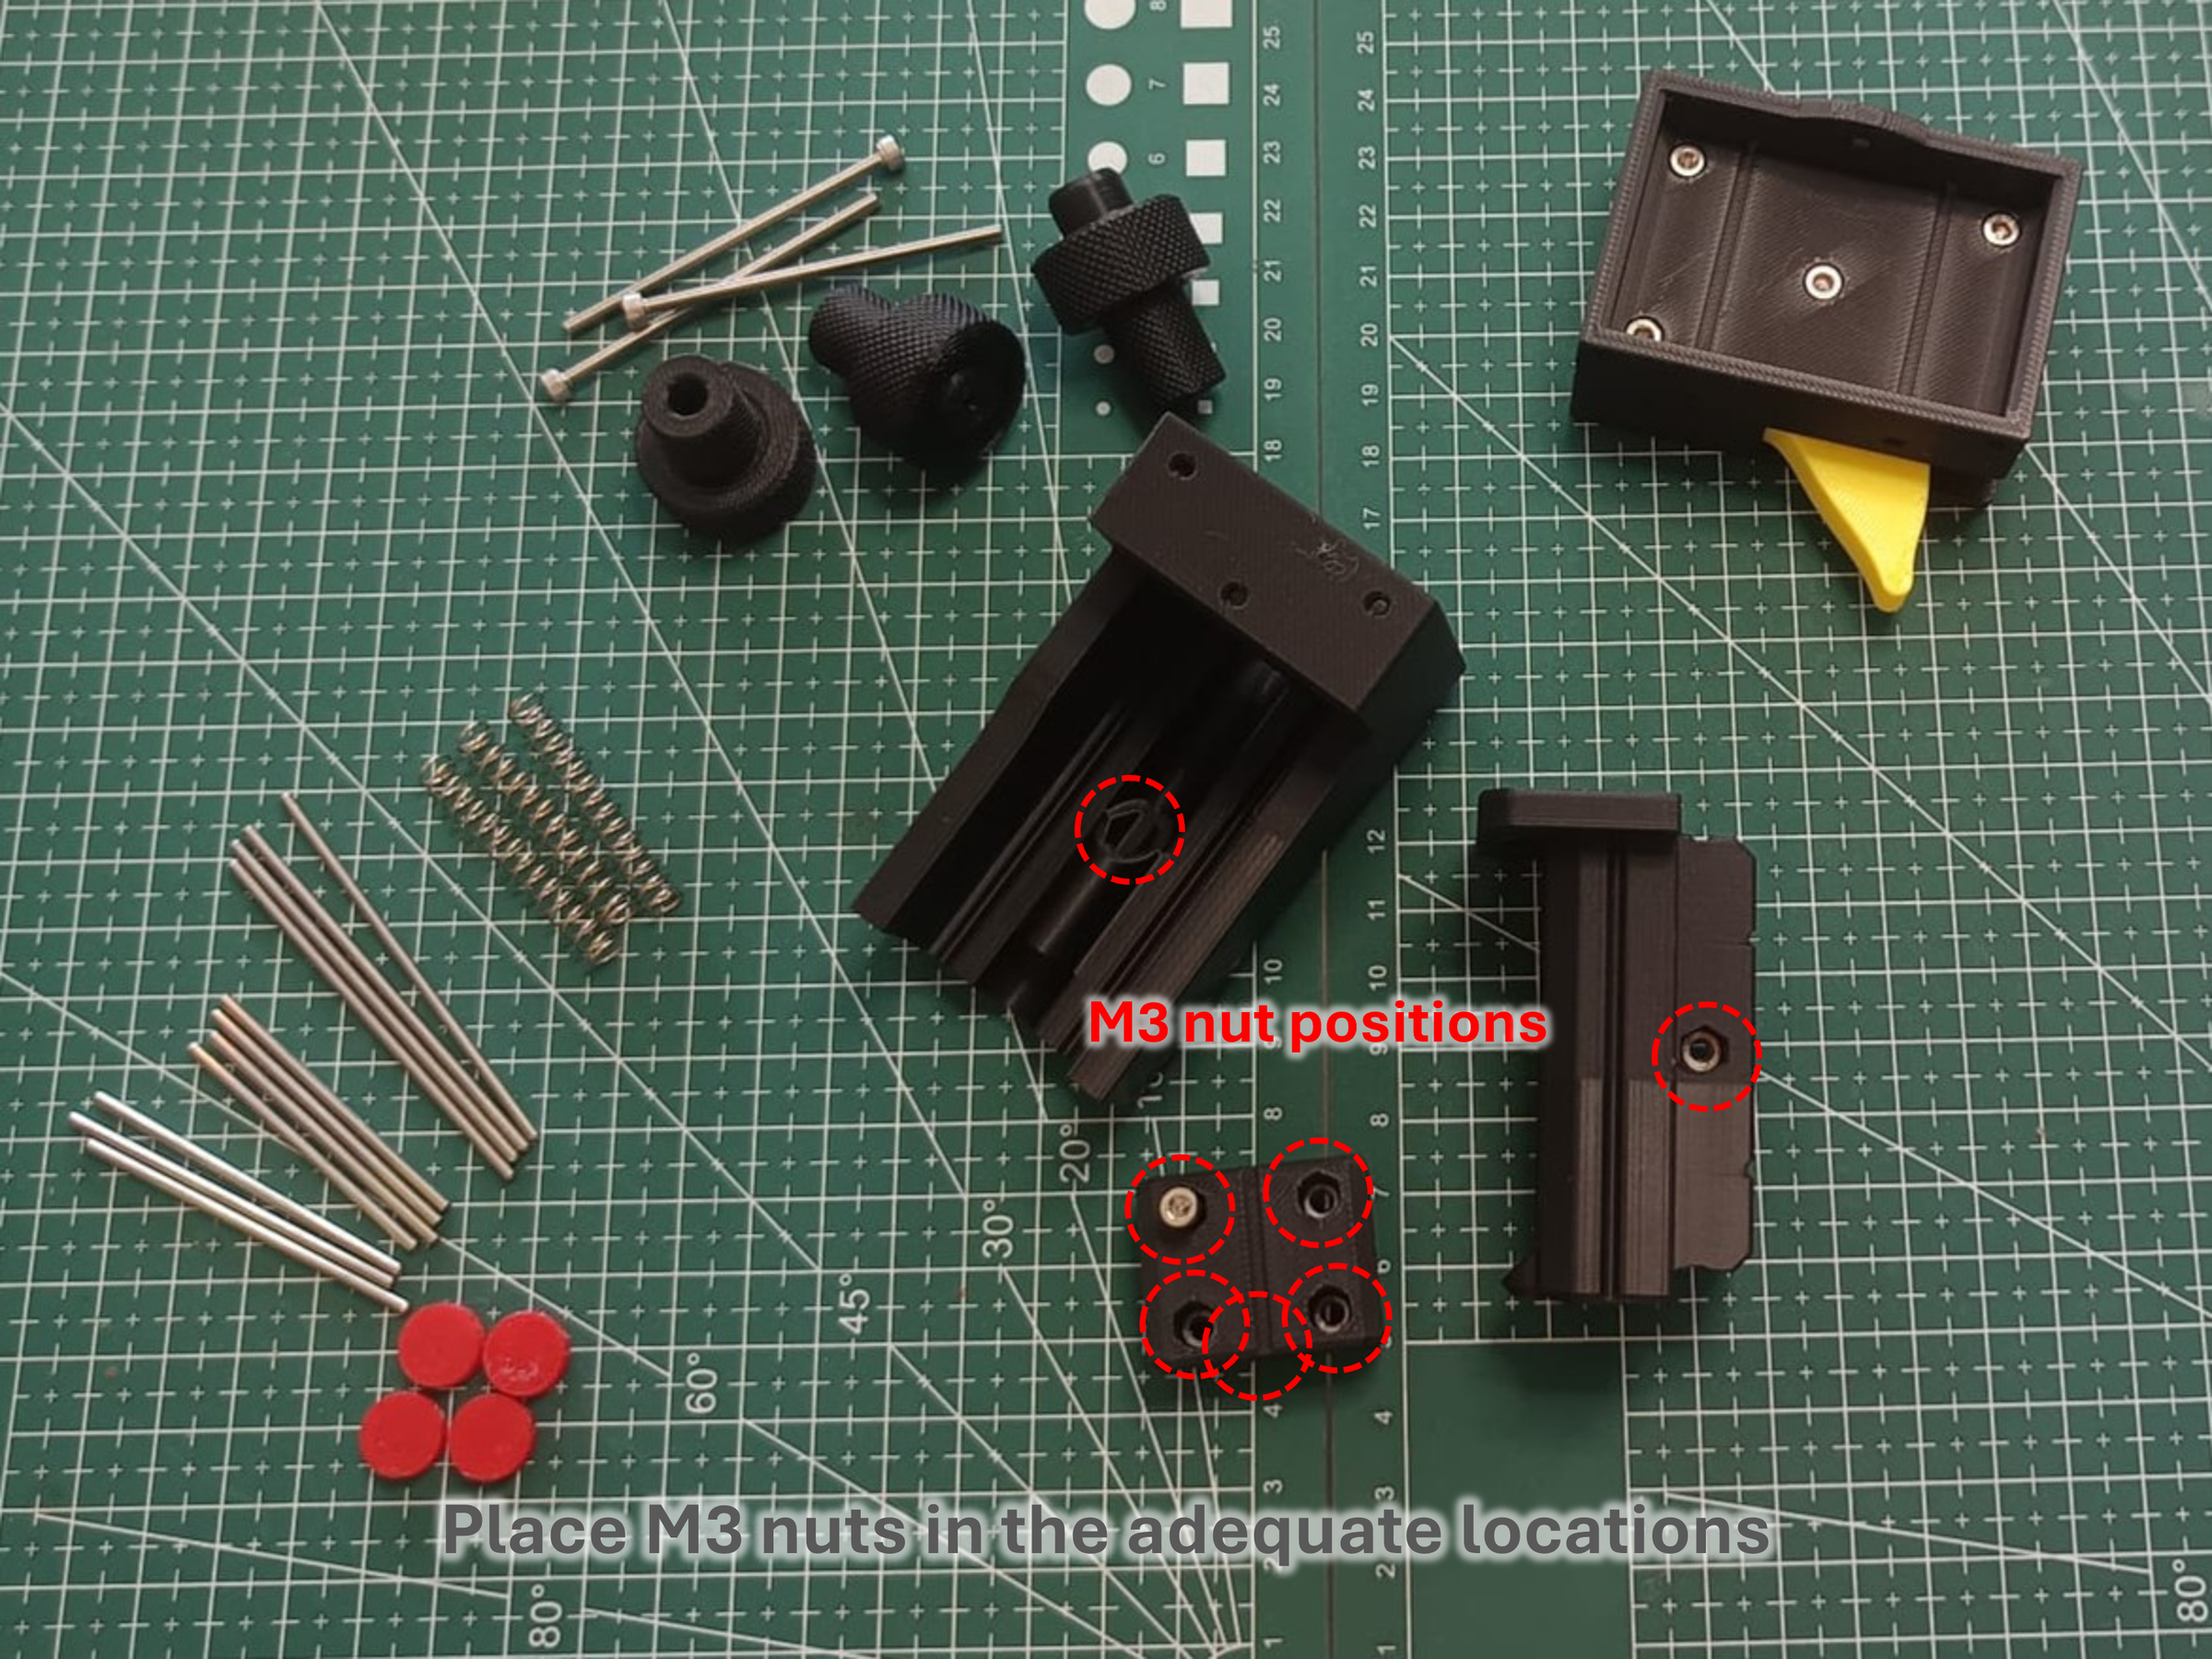
Use four M3 × 10 mm bolts to secure the Y carriage to the base assembly. Then insert the three 55 mm M3 bolts into the three knobs. The knobs are designed to fit tightly around the bolts, but secure them with glue if necessary.
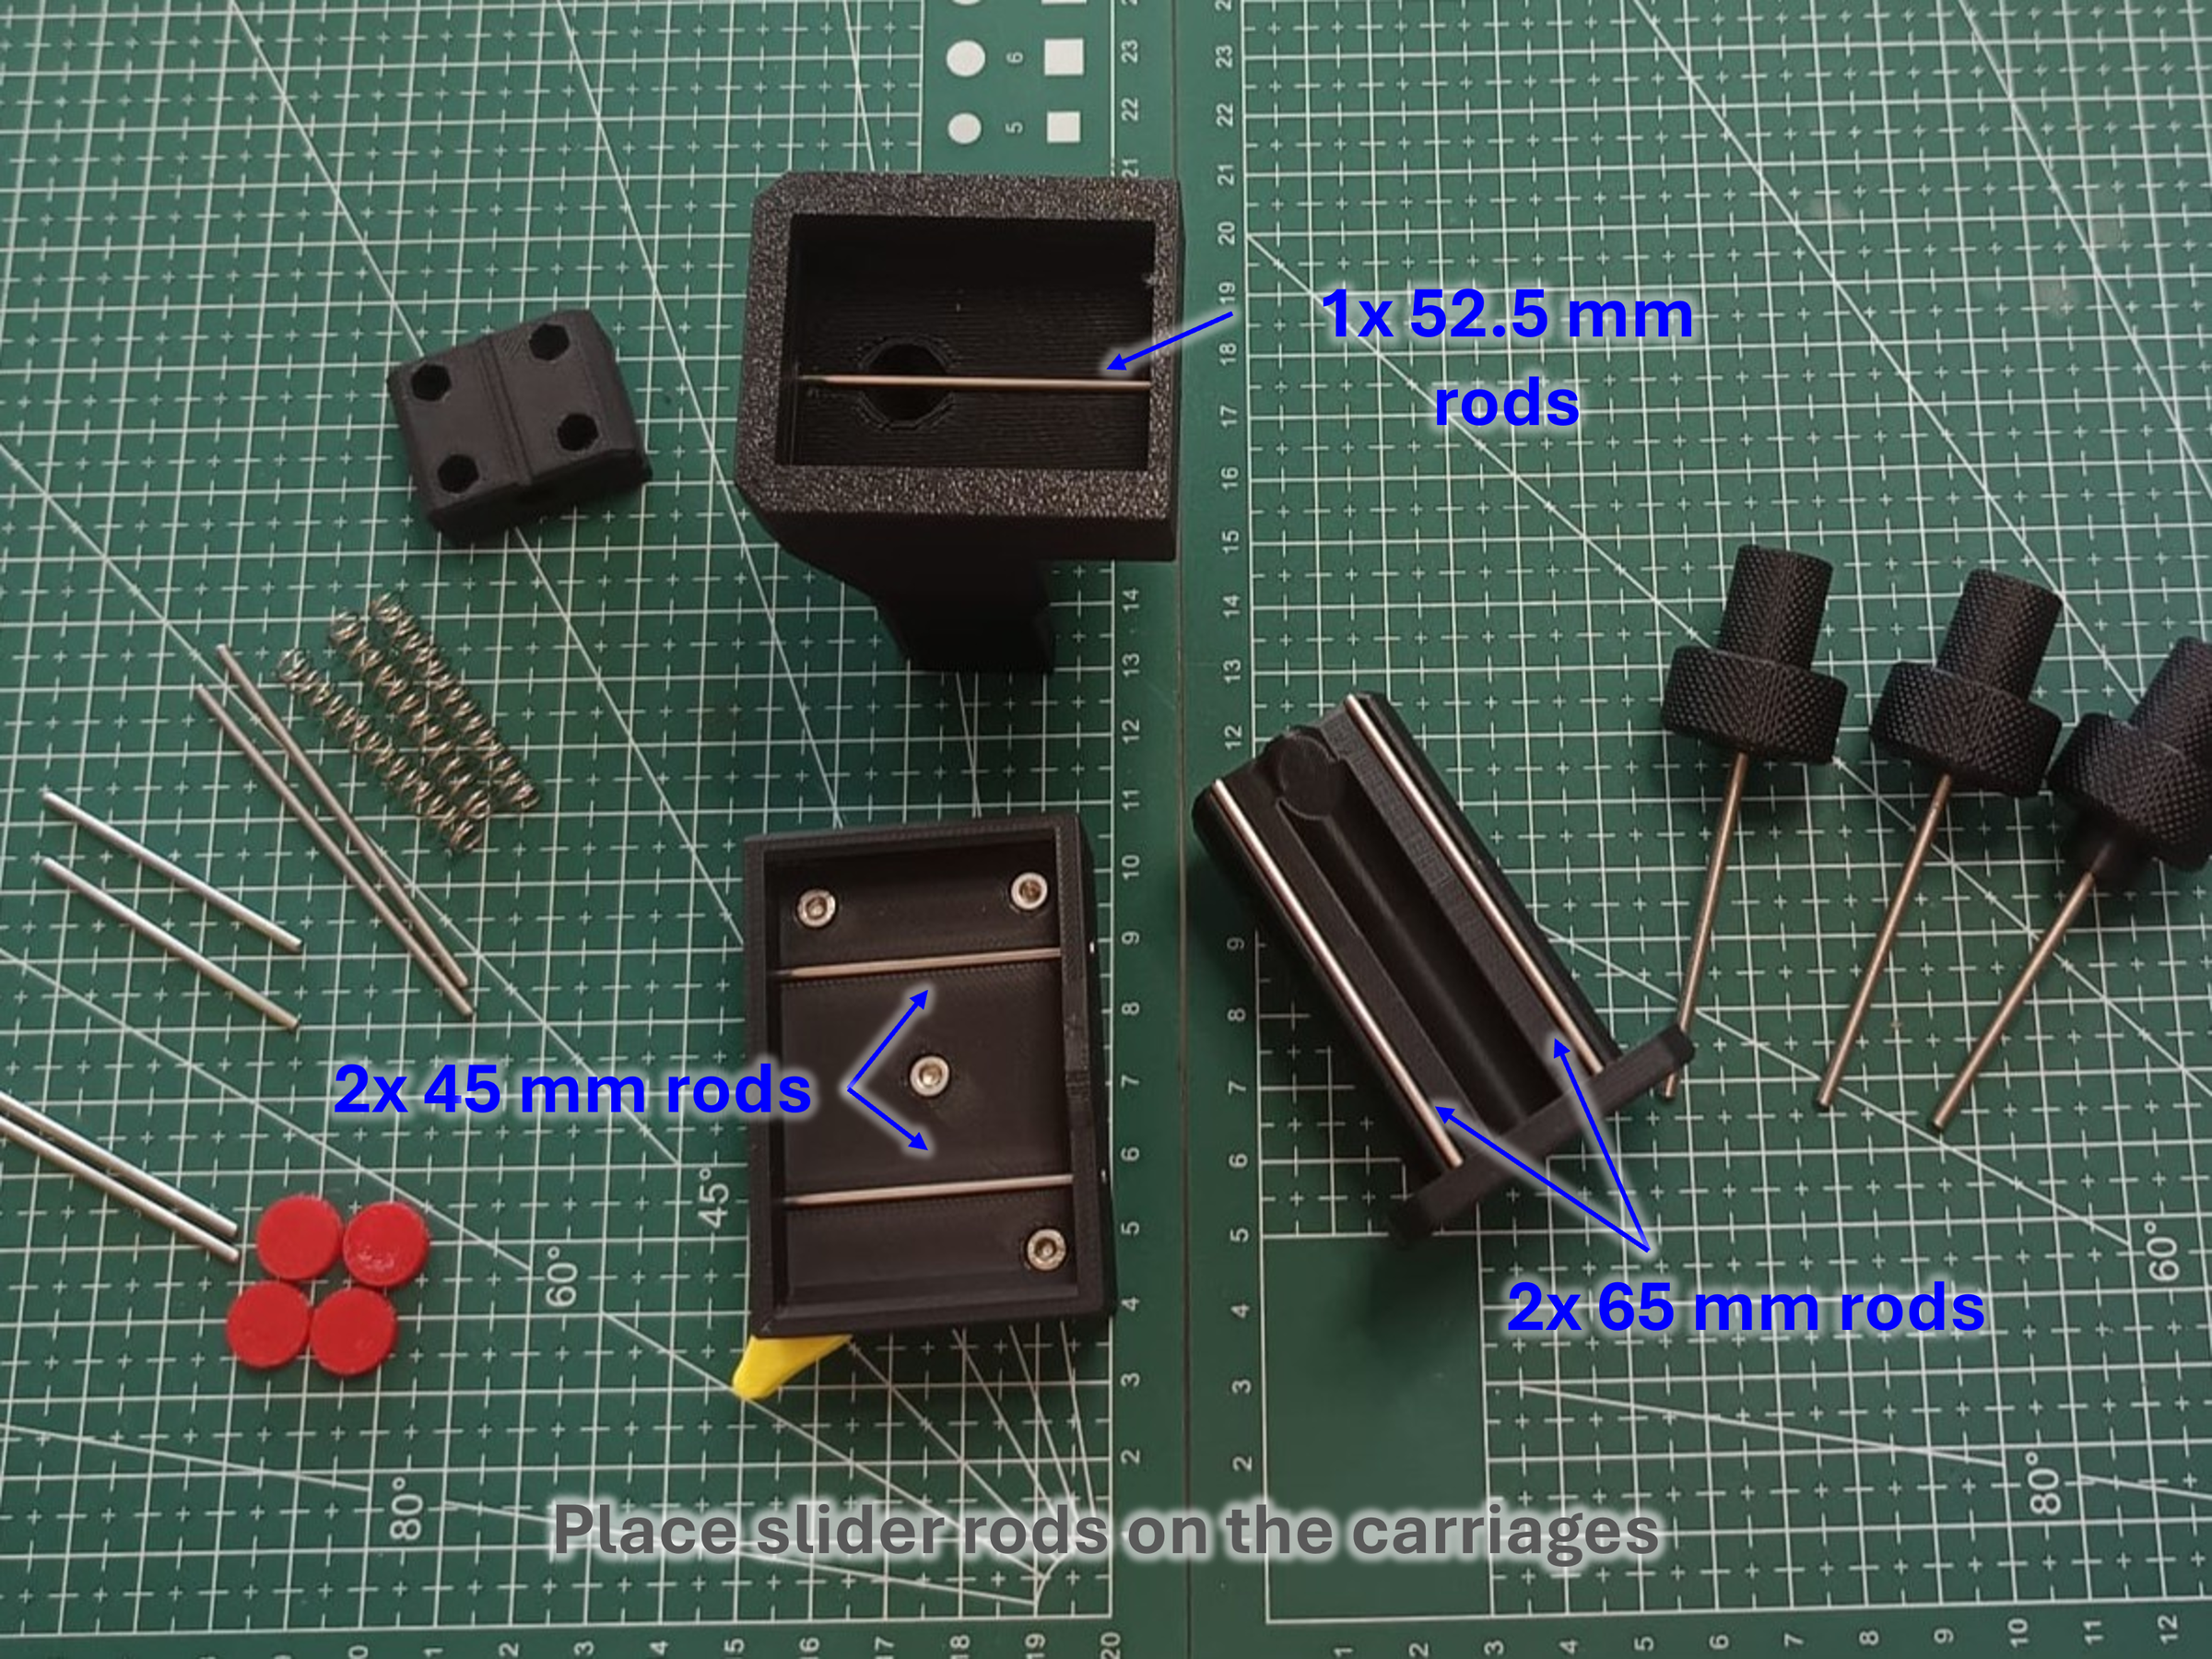
Use a vice or hammer to insert the M3 nuts into all the required locations (seven nuts in total). Then insert the slider rods only at the positions indicated in the illustration.
Assemble the Z Axis

Place the Z slider inside the Z carriage and insert the 52.5 mm rods to hold it in position. Move the carriage up and down and check how much force is required. The objective is to obtain a tight fit that provides sufficient rigidity while still allowing the part to slide easily enough for the spring to move it.
If the fit is too tight, mount a longer piece of rod in a drill and spin it inside the hole. While moving the Z slider up and down, keep the rod spinning until friction generates enough heat to slightly deform the hole.
Take your time and be careful not to overheat the parts. For the best result, stop when the fit is still slightly tight, then apply a small amount of oil or grease to the slider rod.
Assemble the X Axis


You can then use the same process for the X axis, using the 65 mm rods. Be careful when inserting these rods, as they can be very difficult to remove once they are fully pushed into place.
Assemble the Y Axis


For the Y axis, it is easier to install the knob and spring before inserting the rods. Make sure to use the Y knob, which is slightly longer than the other two. Place an M3 washer on the bolt, then pass the tip of the bolt through the appropriate opening in the Y carriage. Use the bolt to hold one end of the spring, and place the other end into the opening in the X carriage. Bring the X carriage closer and it will fall in position. Screw the knob into place, then insert the two 45 mm rods as described in the previous steps.
Add the Springs and Knobs
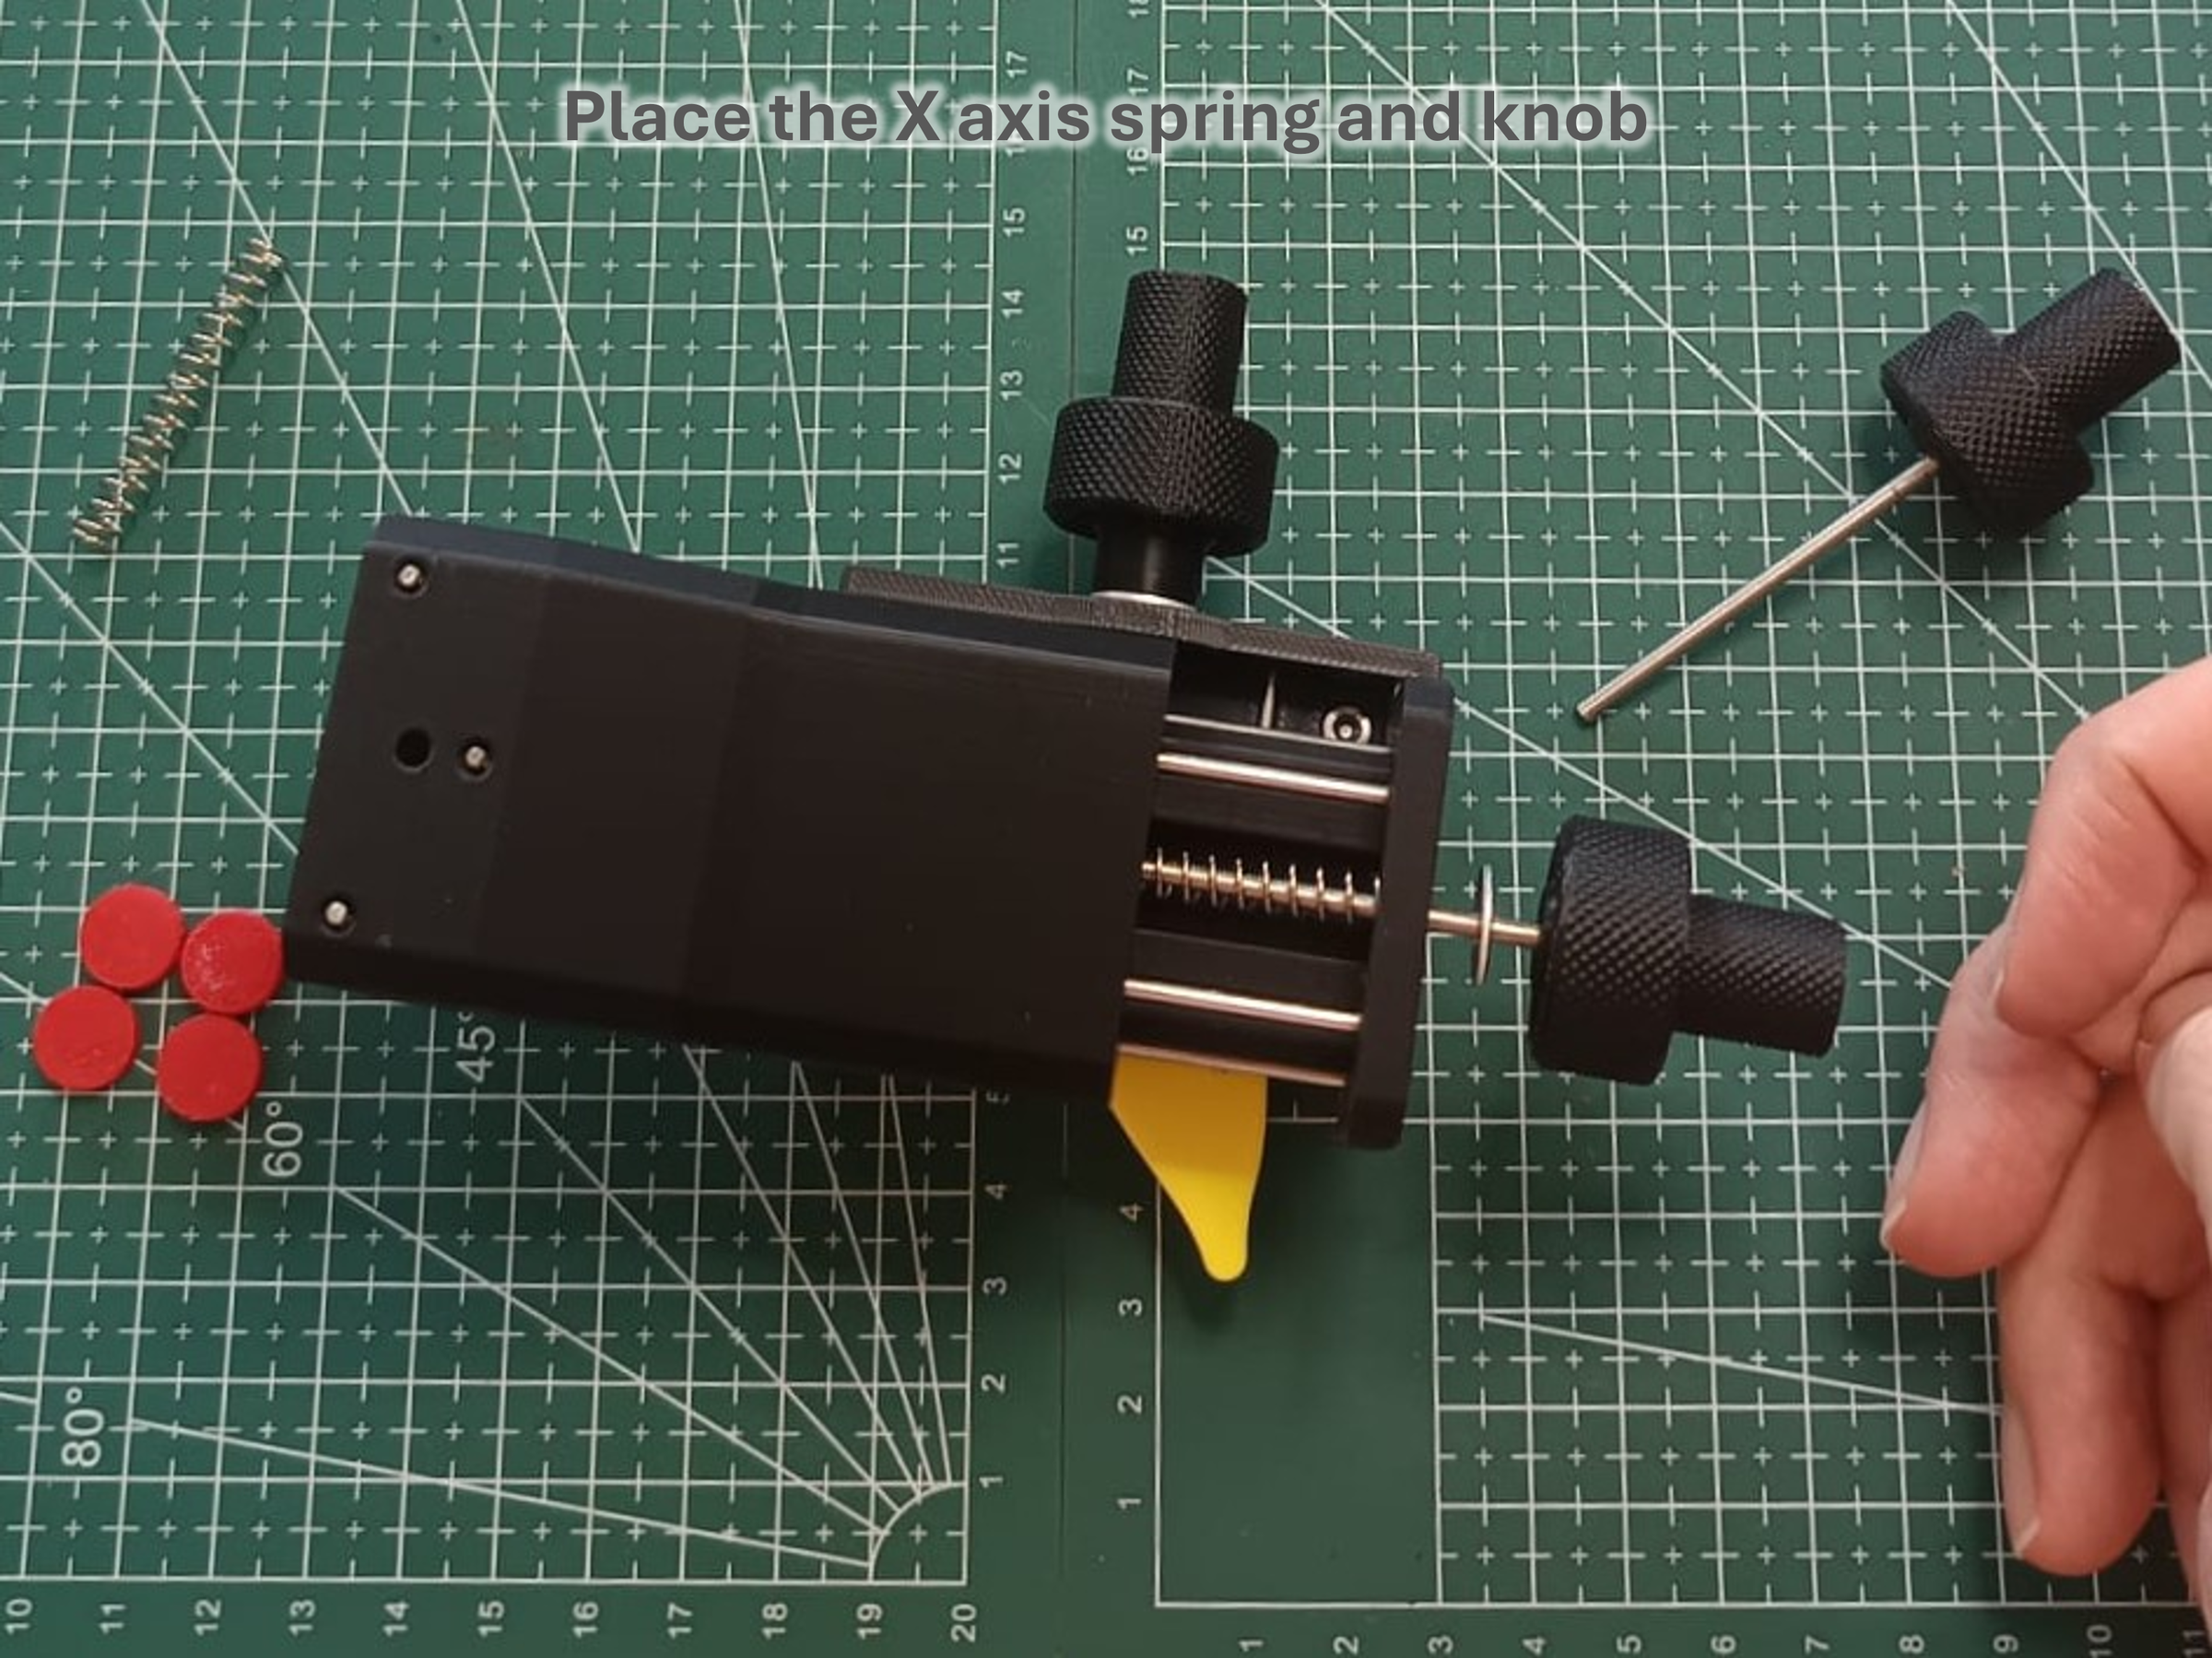
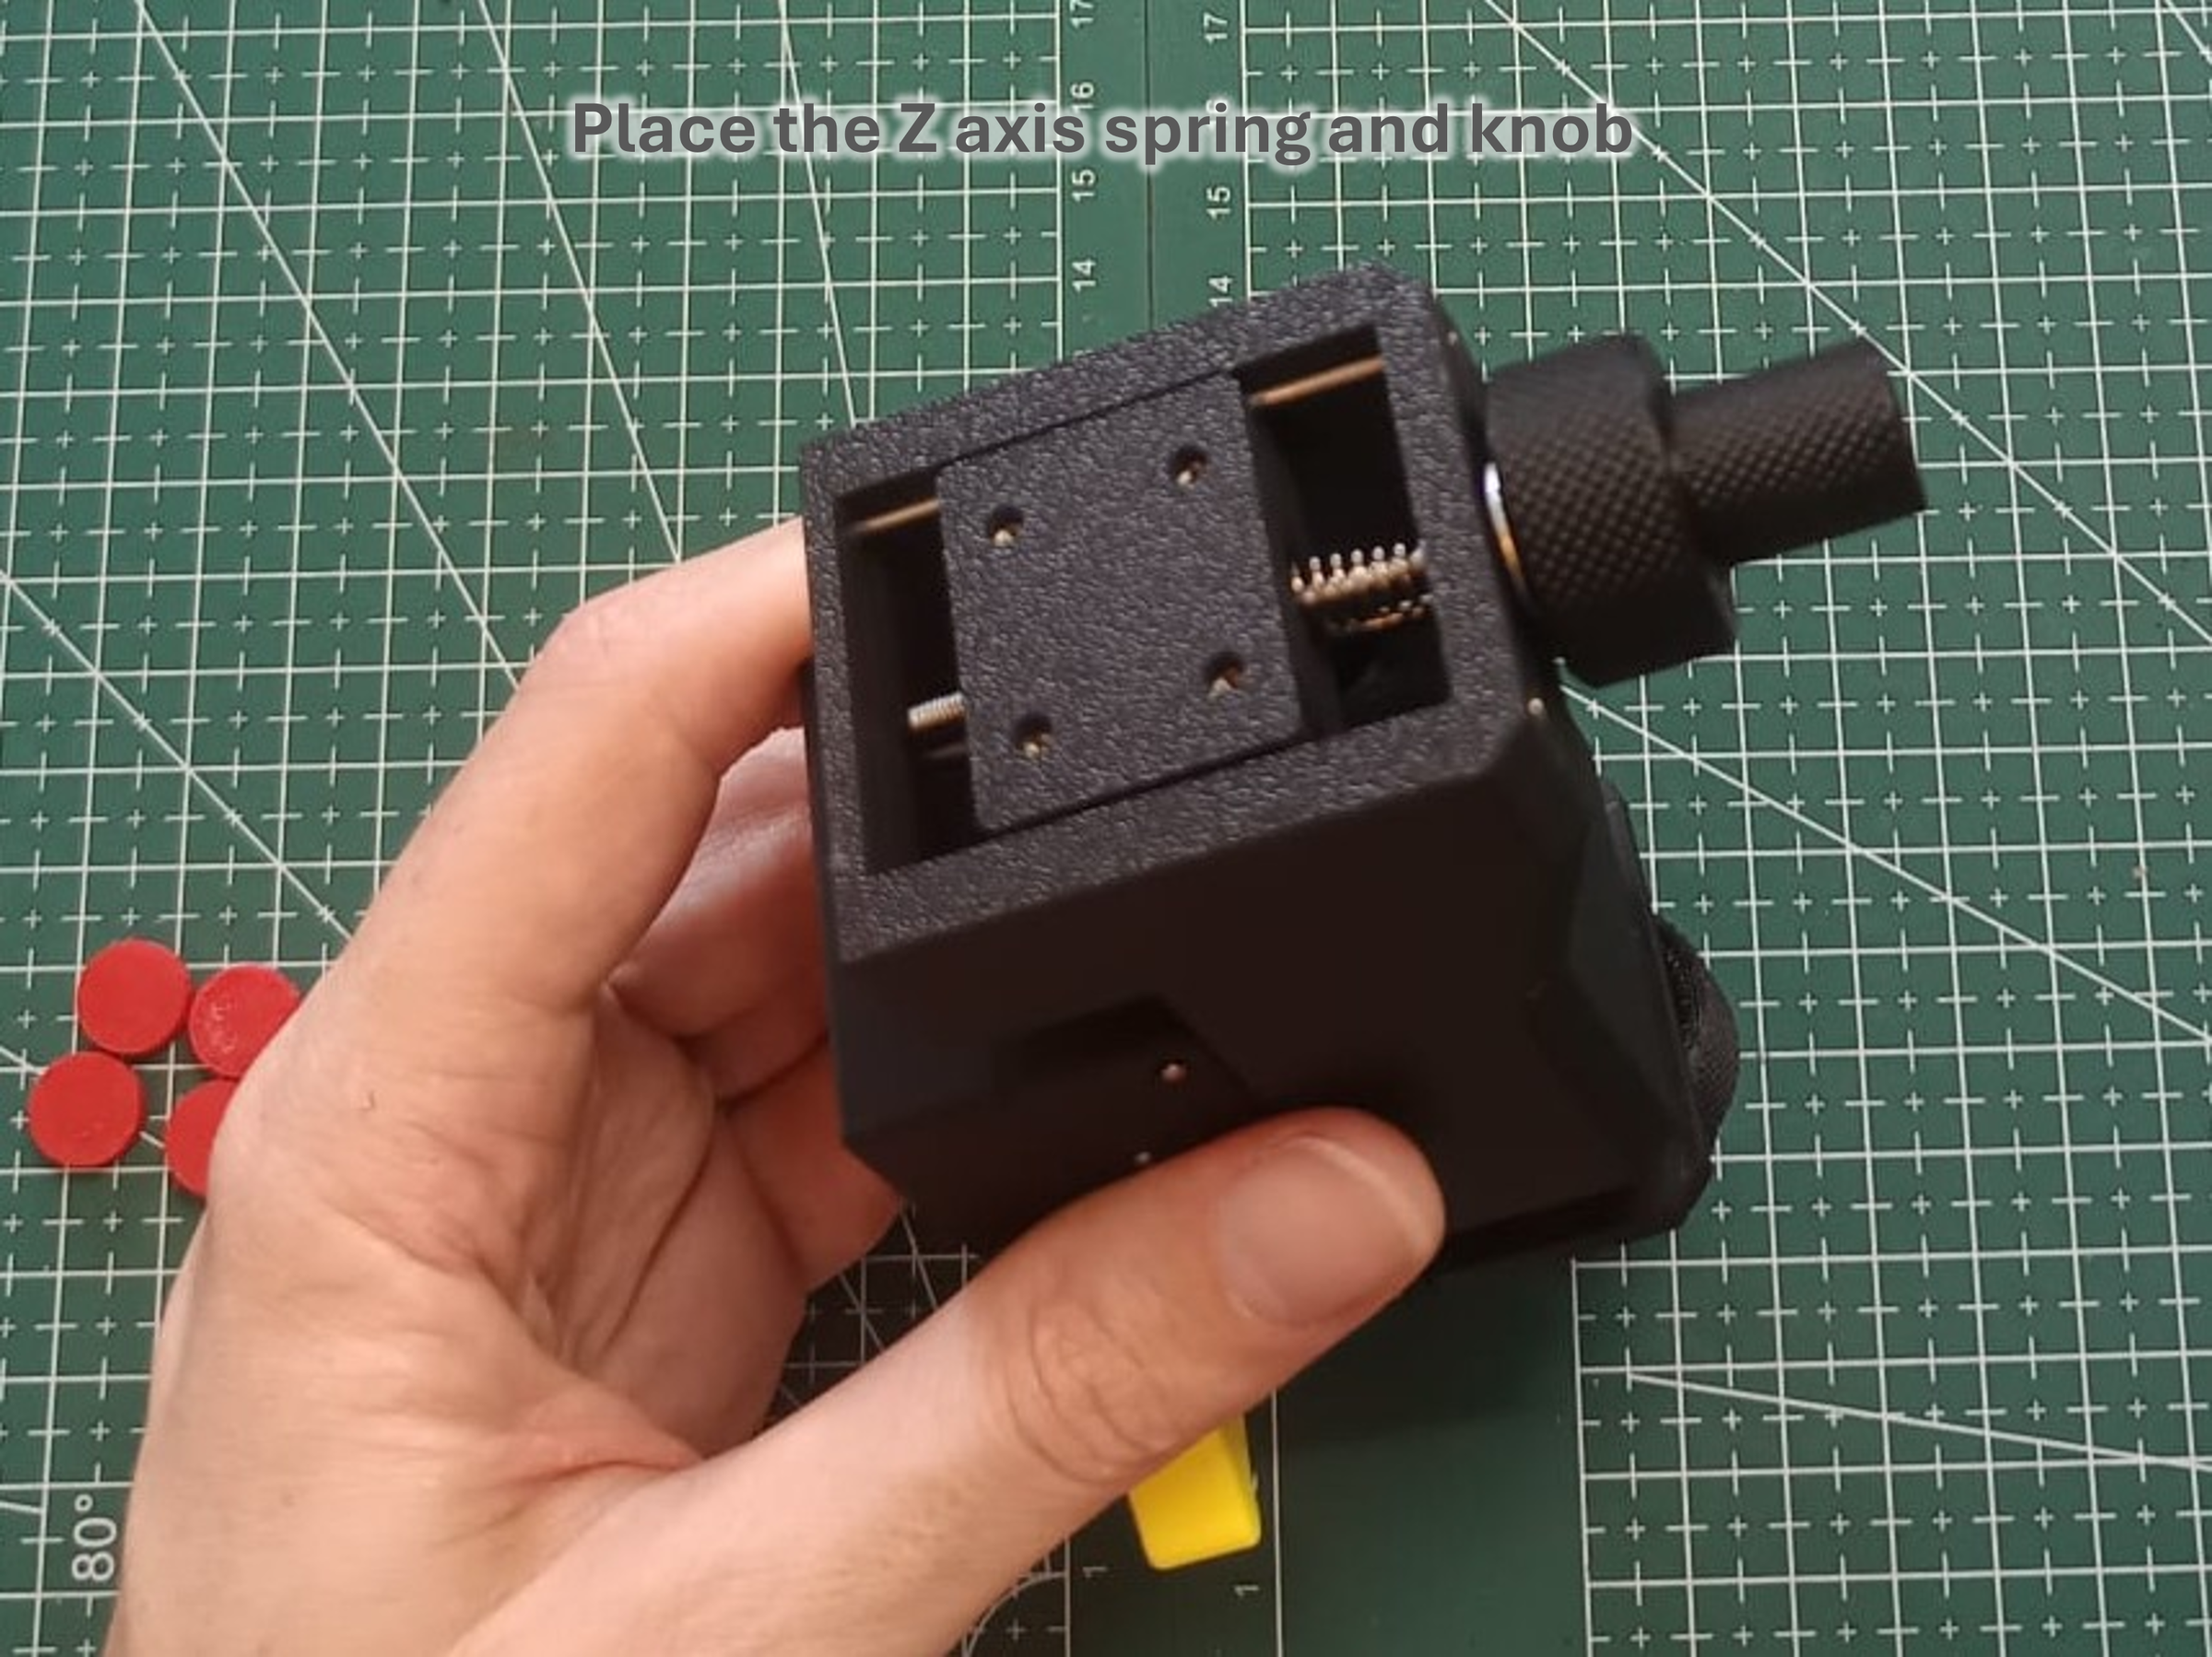

Place the X and Z springs and knobs, then add the TPU pads on the base.
Congratulations, your micromanipulator is essentially finished!
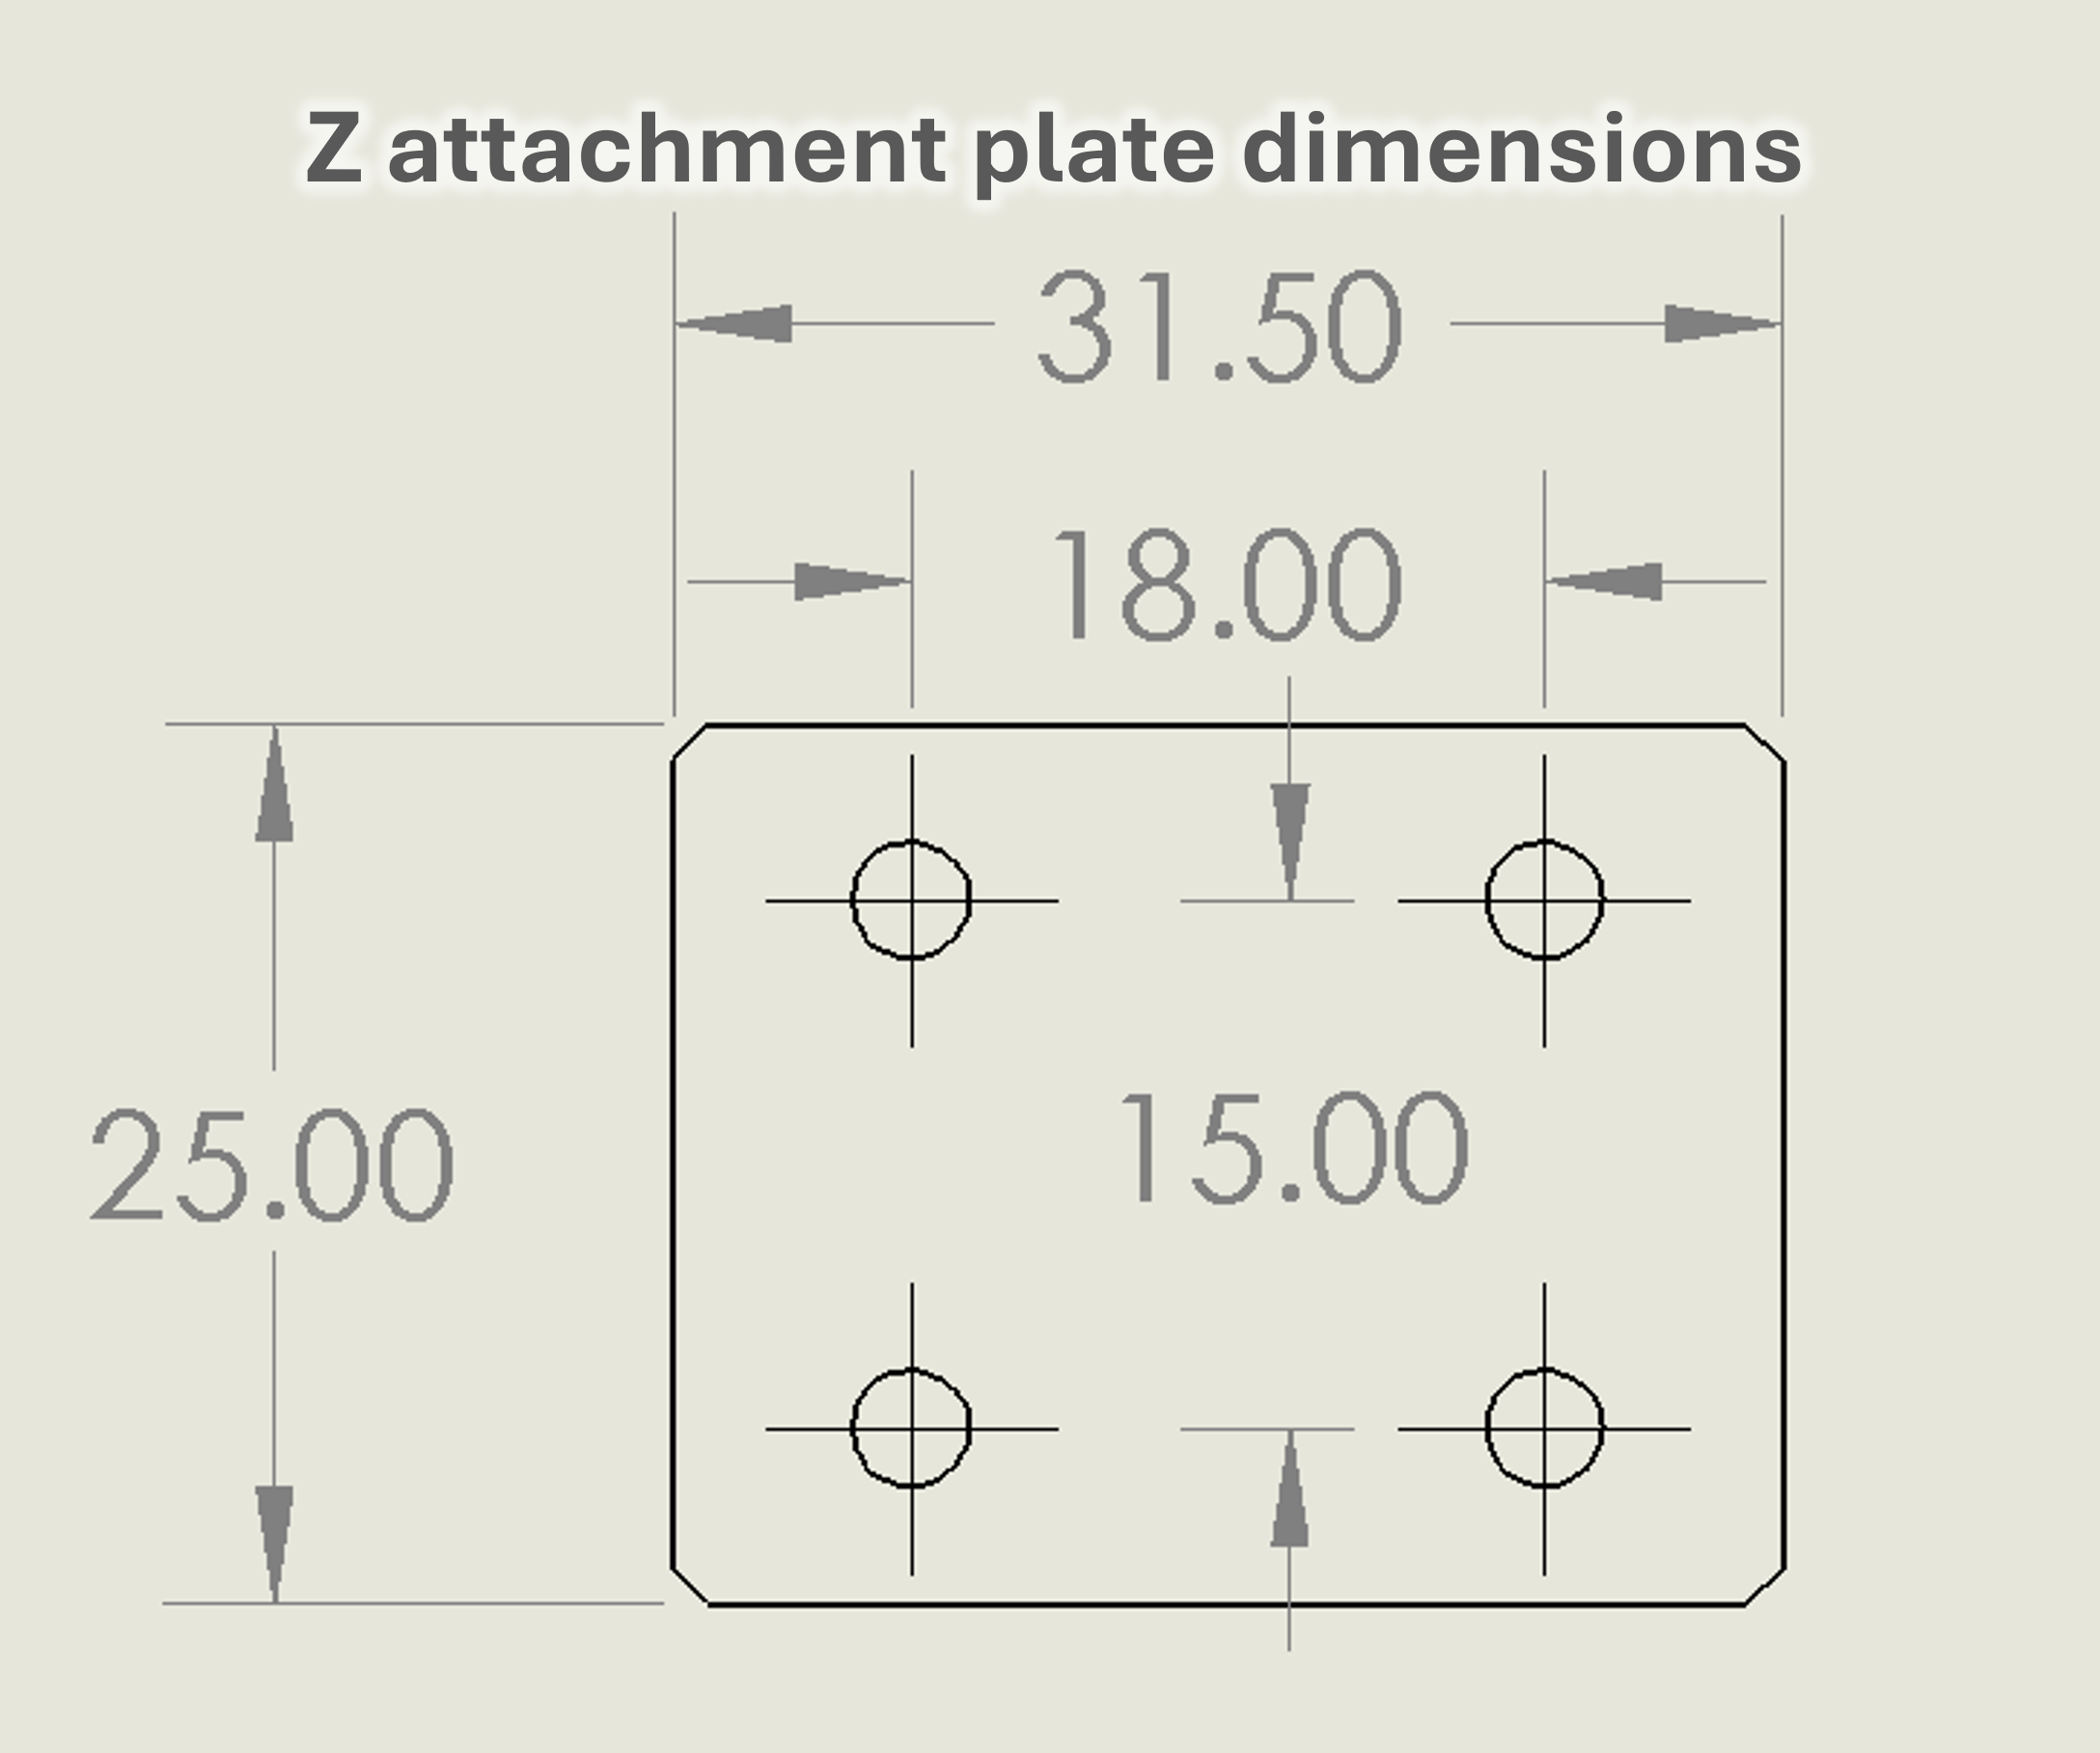
If you want to design custom tools, the Z attachment plate has four attachment points, spaced 15 mm and 18 mm apart, as shown in the illustration.
Alternatively, for most electronics applications, you can use my tip holder system. The following steps will show you how to build it.
Build an Adjustable-Angle Holder




Depending on your application, you may want to use different types of tools with your micromanipulator. However, if your objective is to probe electronic components, you will most likely need a tip holder. I previously designed two tip holders for standard microelectronic connectors: one for straight connectors and one for 90°-bent connectors. For the bent holder, please refer to Step 9 of this tutorial. For straight connectors, I have updated my adjustable-angle holder to ensure that tightening it in place does not cause the holder to rotate. This step will show you how to build it.
First, print all the "tip holder" parts from the micromanipulator page on your favorite 3D-file repository. Keep the orientation specified in the STL files and use supports.
You will also need need
- 2x M3 4.2 mm OD 4 mm long melt inserts
- 2x 10 mm M3 bolts
- 1x 14 to 20 mm M3 bolt
- 4x 10 to 15 mm M3 bolt
- 1x M3 nut
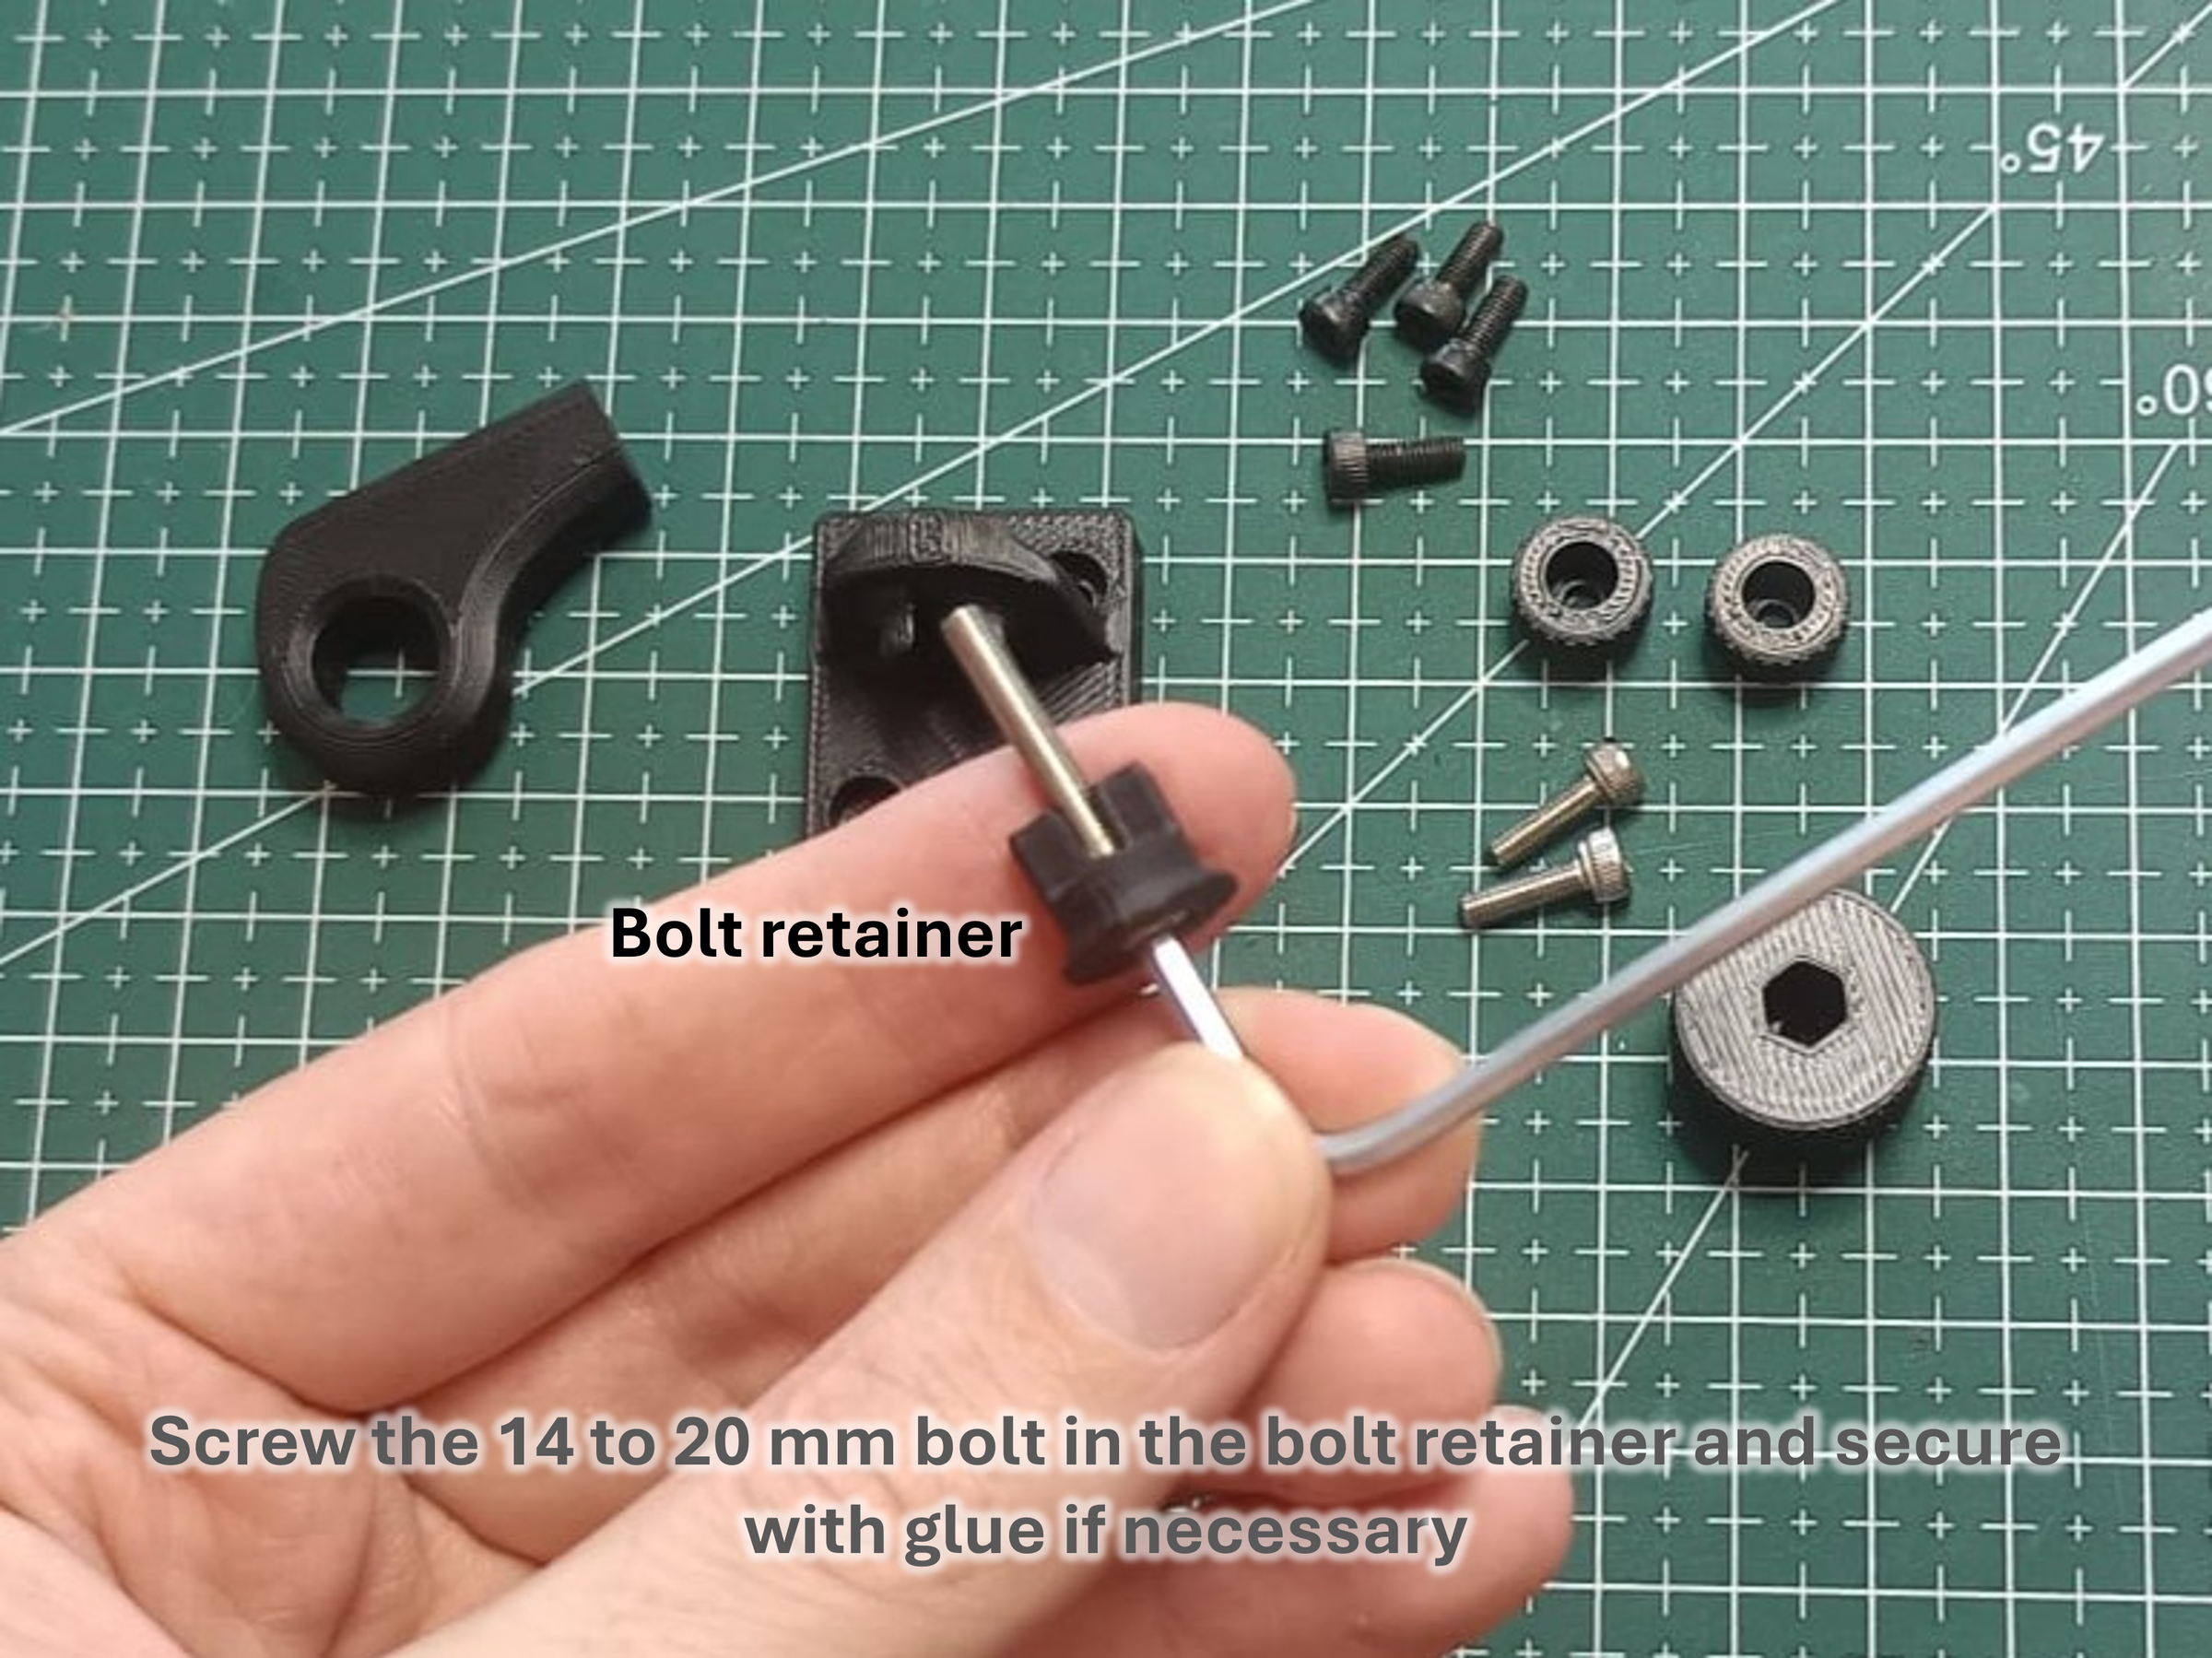
Start the assembly by inserting the M3 × 14–20 mm bolt into the bolt retainer and the two M3 × 10 mm bolts into the knobs. Secure them in place with glue if necessary. Insert the M3 nut into the main knob, then use it to attach the arm to the base. Holding the arm at 90°, you can conveniently insert the two melt inserts with a soldering iron. Once the inserts are installed, disassemble the arm from the base and attach the base to the micromanipulator Z slider using four M3 × 10–15 mm bolts. Reattach the arm, install the knobs, and your adjustable-angle holder is ready to use. If you do not use a commercial needle tip holder, refer to the following step to build one.
Build a Needle Tip Holder



Electronic probing usually requires needle tips with an electrical connection. Commercial tip holders typically use a metallic clamping system that provides both reliable electrical and mechanical connections.
3D-printed parts alone cannot reliably provide an electrical connection, but you can use my tip holder for micromanipulator to hold stainless-steel or tungsten needles, as well as drawn-glass capillaries.
For electrical measurements, you will need to connect your tip to a wire. I use the warping method to achieve a reliable connection, but you can also solder you tips. From my experience, stainless-steel sewing needles work well for contacting 50-micrometer pads or larger. For smaller pads, you will need to use electrochemically etched tips, as described below.
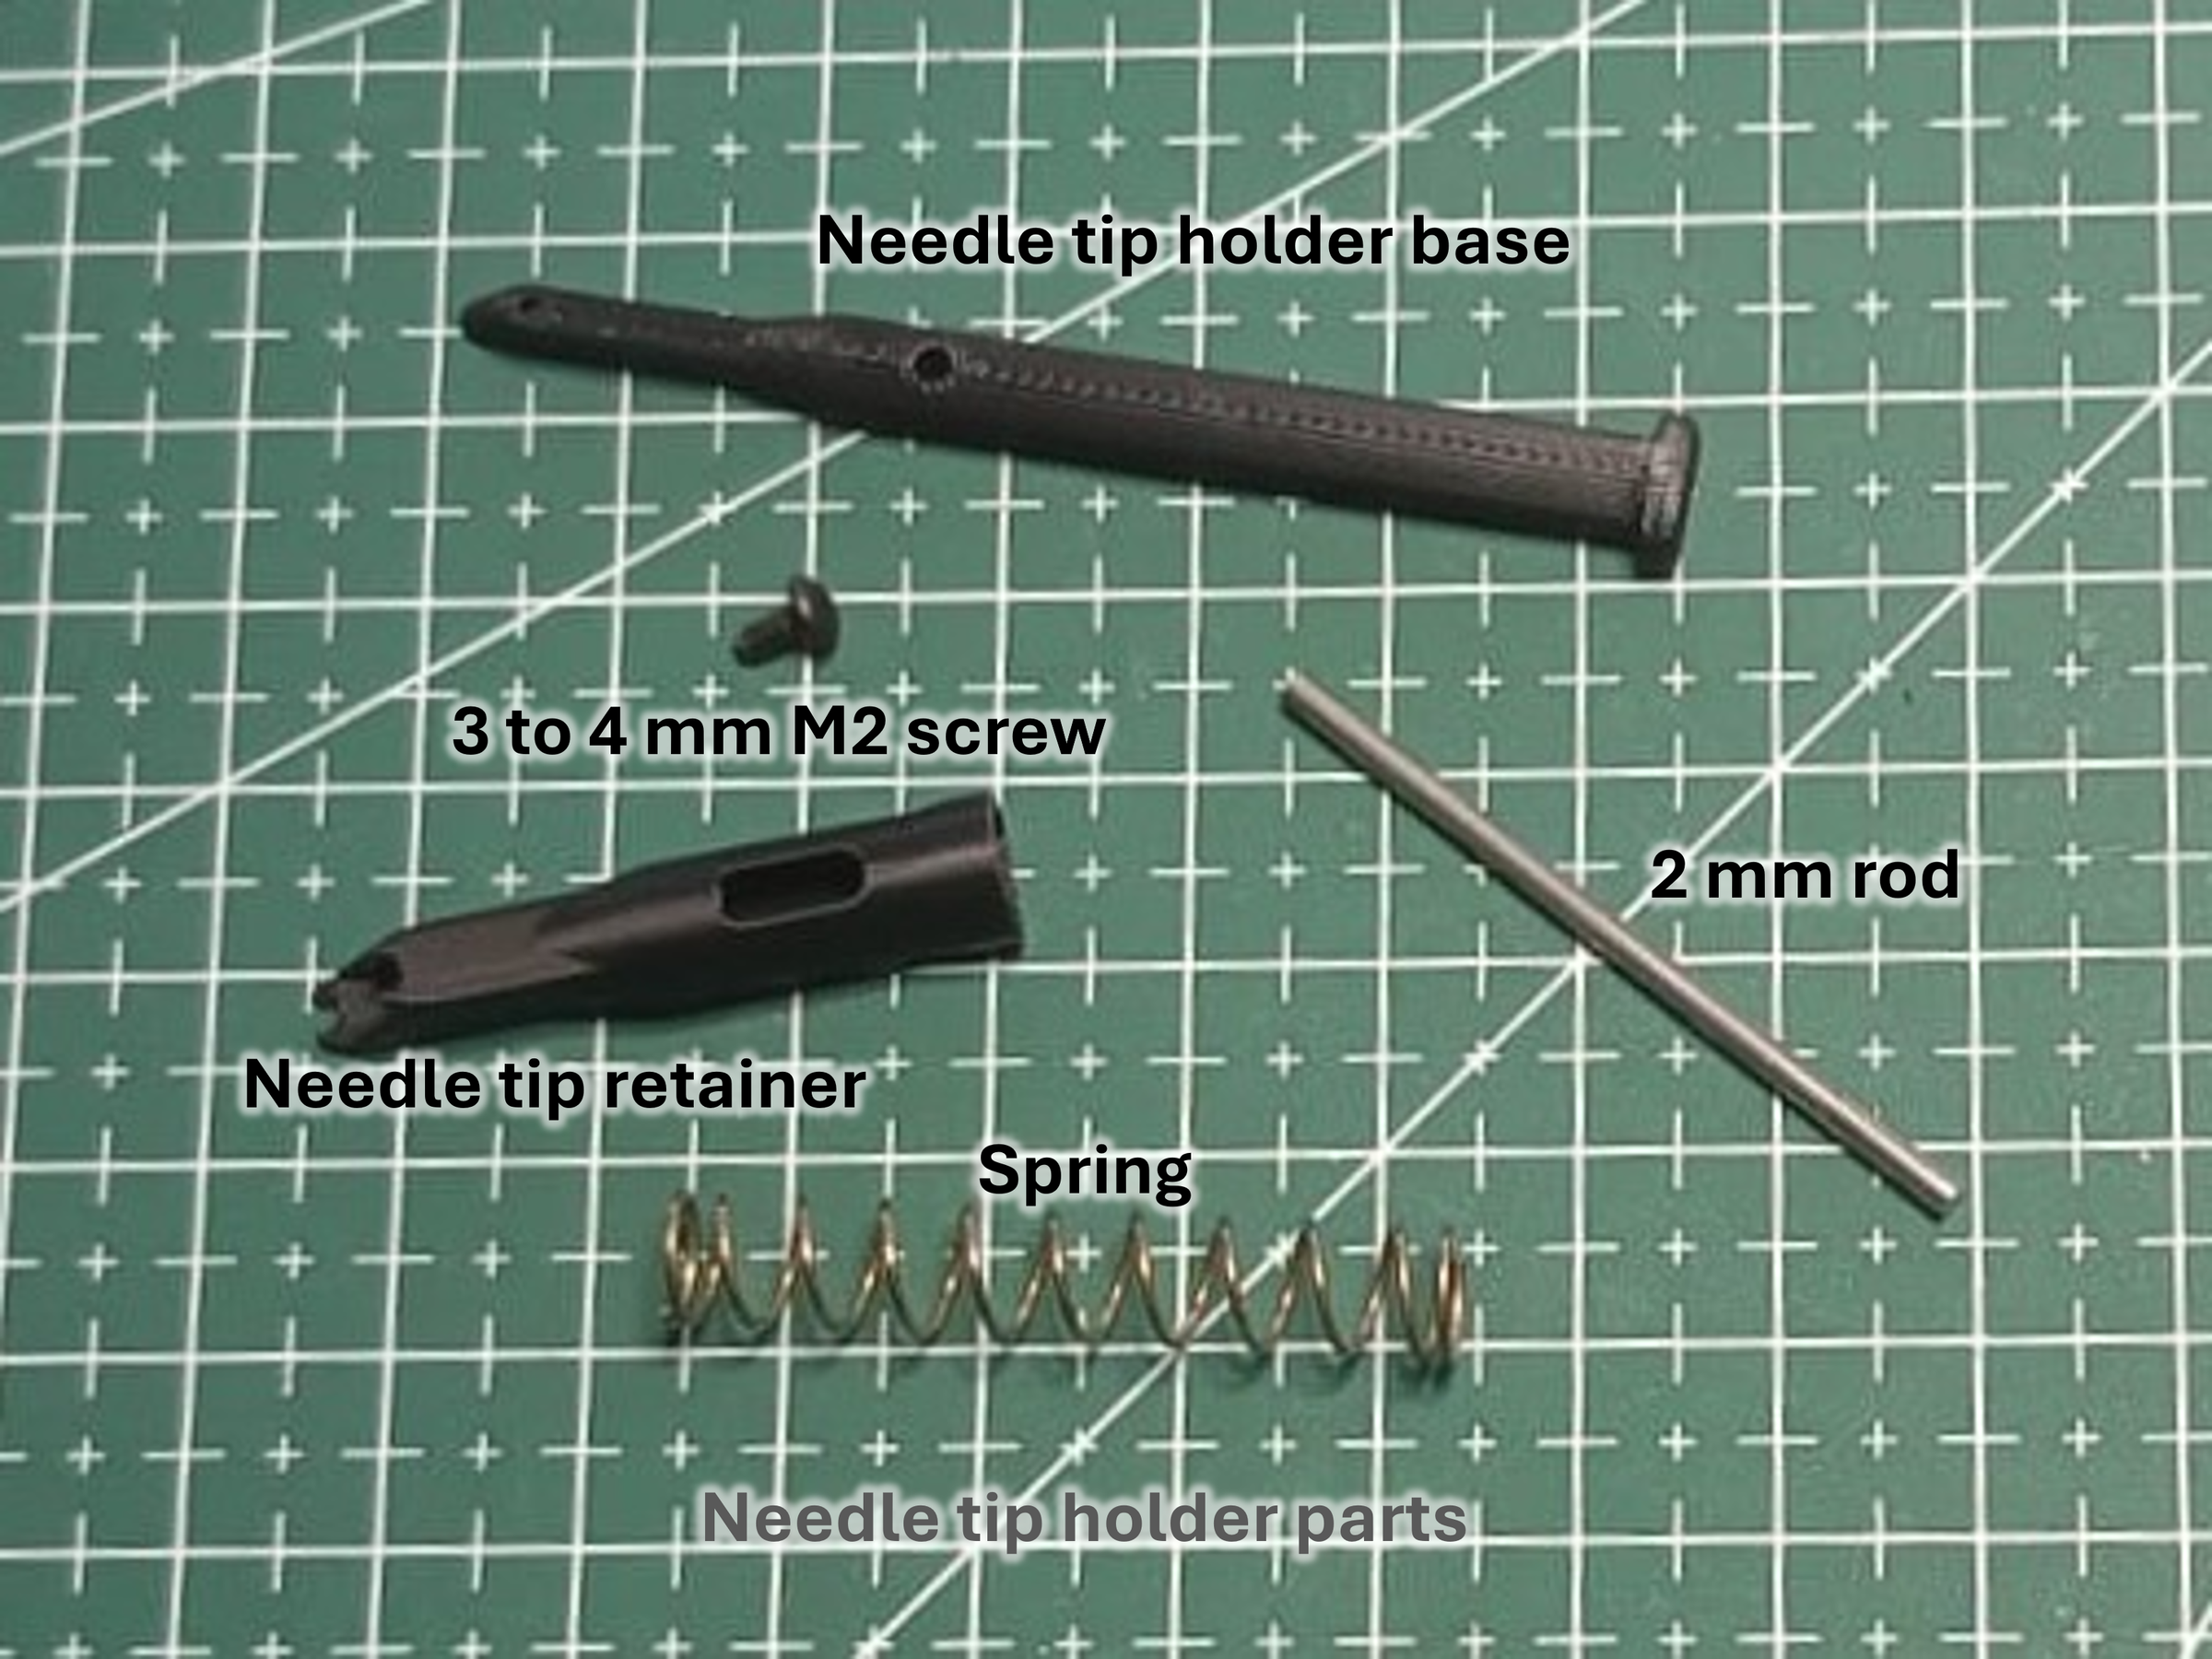
To build this needle tip holder, first, download the files from Thingiverse, Printables, or MakerWorld. Print the parts in the orientation shown in the illustration, and use a brim for the retainer part. You will also need:
- 1x 35 to 50 mm long 2mm thick metal rod
- 1x 3 to 4 mm M2 screw
- 1x spring 6-7 mm OD about 30 mm long
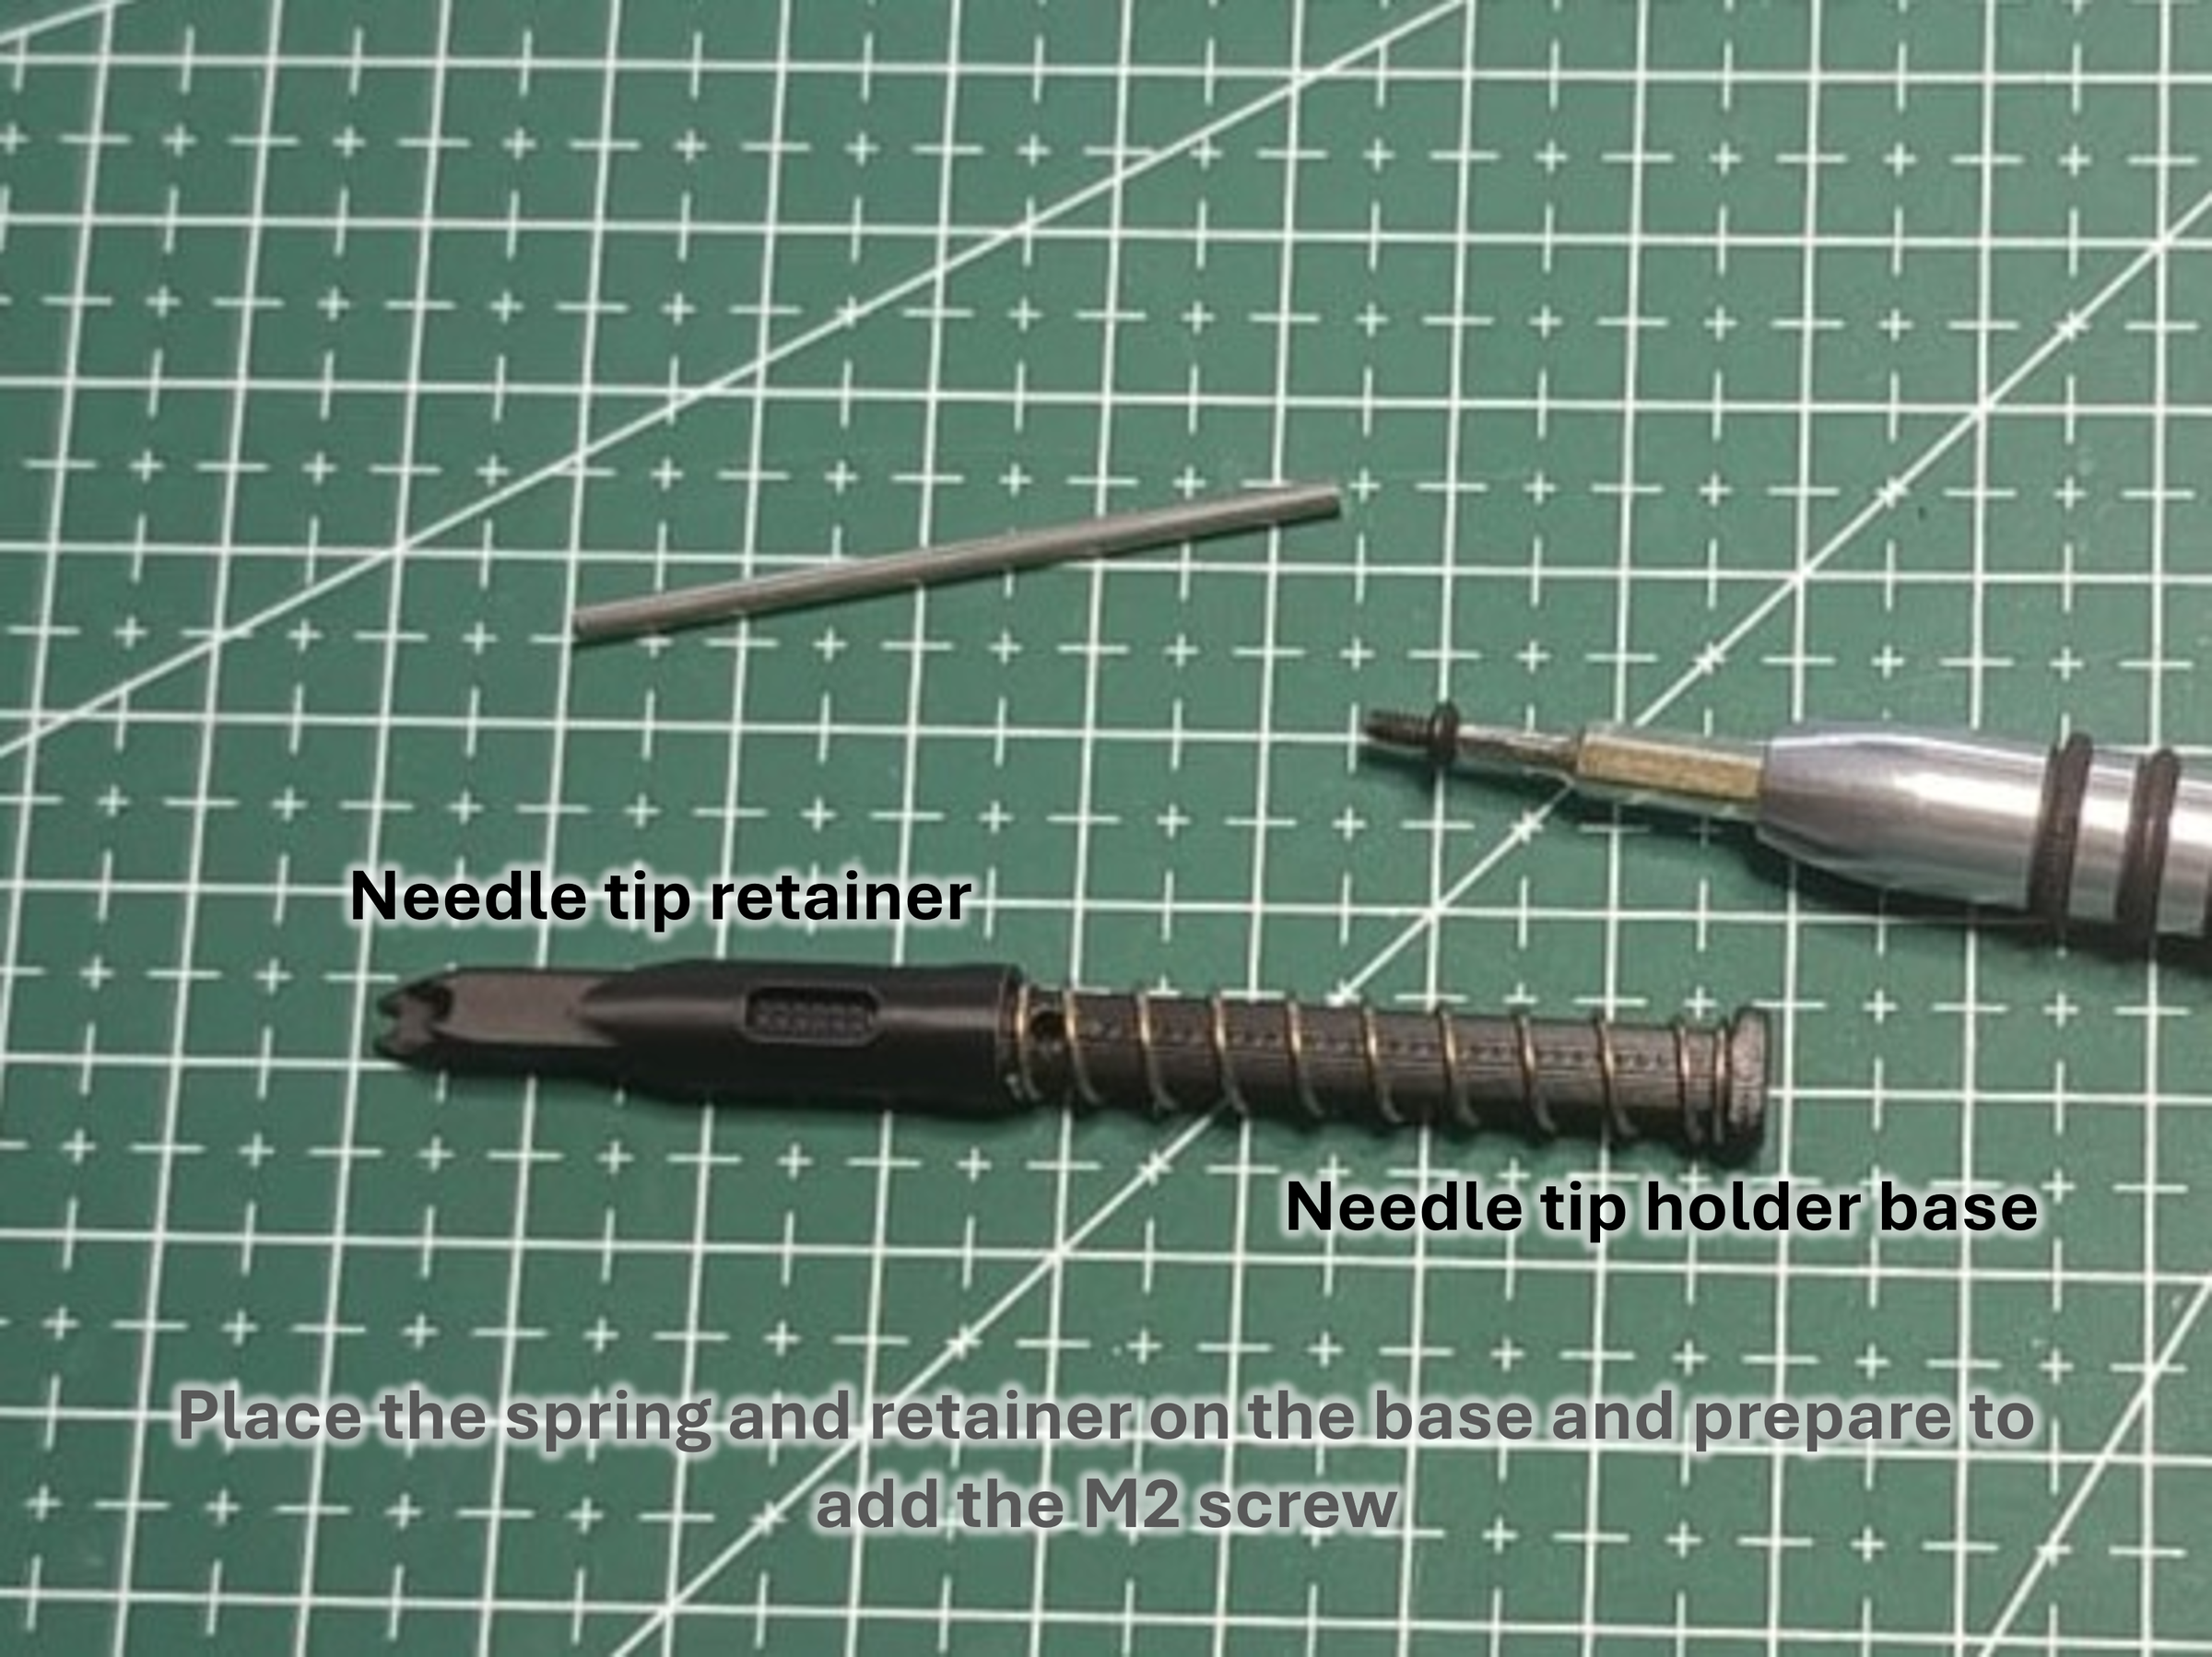
To assemble the holder, place the spring and retainer on the base, compress the spring, and lock the retainer in place with the M2 screw. Push the 2 mm rod into the base and secure it with glue.
The completed holder can then be secured to the adjustable-angle holder using the two knobs.
To install a needle tip, pull the retainer back, insert the needle, and release the retainer.
Links to the Hardware
I sourced most of my components from Taobao, as it is particularly convenient and economical given my location in Hong Kong. However, Taobao can be challenging to use for non-Chinese speakers, so I have also included links to other suppliers. Please bear in mind this is not an endorsement and those links are only here as reference.
- 12 mm diameter, 3mm thick magnets: Taobao, Aliexpress, Amazon
- 12 mm diameter, 1mm thick washers: Taobao, Aliexpress, Amazon
- 2 or 3 mm rods: Taobao, Aliexpress, Amazon
- M3 bolts and nuts: Taobao, Aliexpress, Amazon
- M3 melt inserts 4.2 mm OD and 4 mm thick: Taobao, Aliexpress, Amazon
- Springs: Taobao, Aliexpress or Aliexpress, Amazon or Amazon,
Use It
