DIY Cricket Bowling Machine

DIY Cricket Bowling Machine
This project describes the design and construction of a DIY cricket bowling machine developed for practice with plastic, tennis, rubber and cricket balls.
The machine uses two RS775 DC motors driving 4-inch PU wheels. The two wheels grip and accelerate the ball between them, providing a simple and compact way of generating bowling speed.
The machine was developed through several stages of mechanical and electrical experimentation. Wheel size, wheel spacing, motor performance, spring loading, vibration, battery capacity and ball speed were tested and modified during development.
An ESP8266-based control and measurement system was also developed to monitor the wheel speeds and measure the ball speed.
The completed machine was tested with repeated bowling trials and was found to operate reliably using a 12 V, 7.2 Ah battery.
This Instructable describes the mechanical construction, electronics, control system, testing and the lessons learned during the development.
Supplies


The machine accelerates and throws the ball forward using friction generated between two high-speed wheels rotating in opposite directions. The gap between the wheels is set slightly smaller than the ball's diameter to compress it enough for a solid grip. Higher wheel speeds directly equal higher ball speeds.
Component Checklist:
- Main Throwing System: 2 × RS775 DC motors, 2 × 4-inch Polyurethane (PU) wheels, machined wheel hubs/couplings, motor clamps, wooden mounting blocks, and rubber vibration pads.
- Ball Feeding System: 2½-inch PVC pipe (for the vertical chute and horizontal barrel), custom PVC piston (1¾" wide), crank disc, connecting link, and a 30 RPM geared DC motor.
- Ball Control & Electronics: 12V Solenoid with a blocking pin, microswitches (for home-position detection), 555 timer-based PWM speed controllers, 12V 7.2Ah battery, master switches, and wiring.
- Main Structure: Hardwood base plank, metal brackets, bolts, nuts, and adjustment springs.
Motor Arrangement & Wheel Gap Evolution


In the final design, both motors are locked rigidly onto a hardwood base. Slots in the mounting brackets allow manual adjustments of the wheel gap to handle varying ball sizes. Once set, bolts are tightened firmly to ensure alignment stays perfectly fixed during fast rotation.
Lessons from Failed Spring-Loaded Trials:
- First & Second Attempts: Designs were tested where one or both wheel assemblies were spring-loaded to automatically swing outward when a ball entered.
- The Flaw (Caught on Slow-Motion Video): Video analysis showed that instead of opening cleanly, the unconstrained wheel mounts tilted awkwardly under stress. This misaligned the wheels, ruined energy transfer, and caused inconsistent deliveries.
- Conclusion: A dynamic spring system requires a properly engineered pivot supported by heavy-duty bearings. For simplicity in this DIY build, a rigid, manual slot-adjustment design proved far superior and completely satisfactory.
Eliminating System Vibration
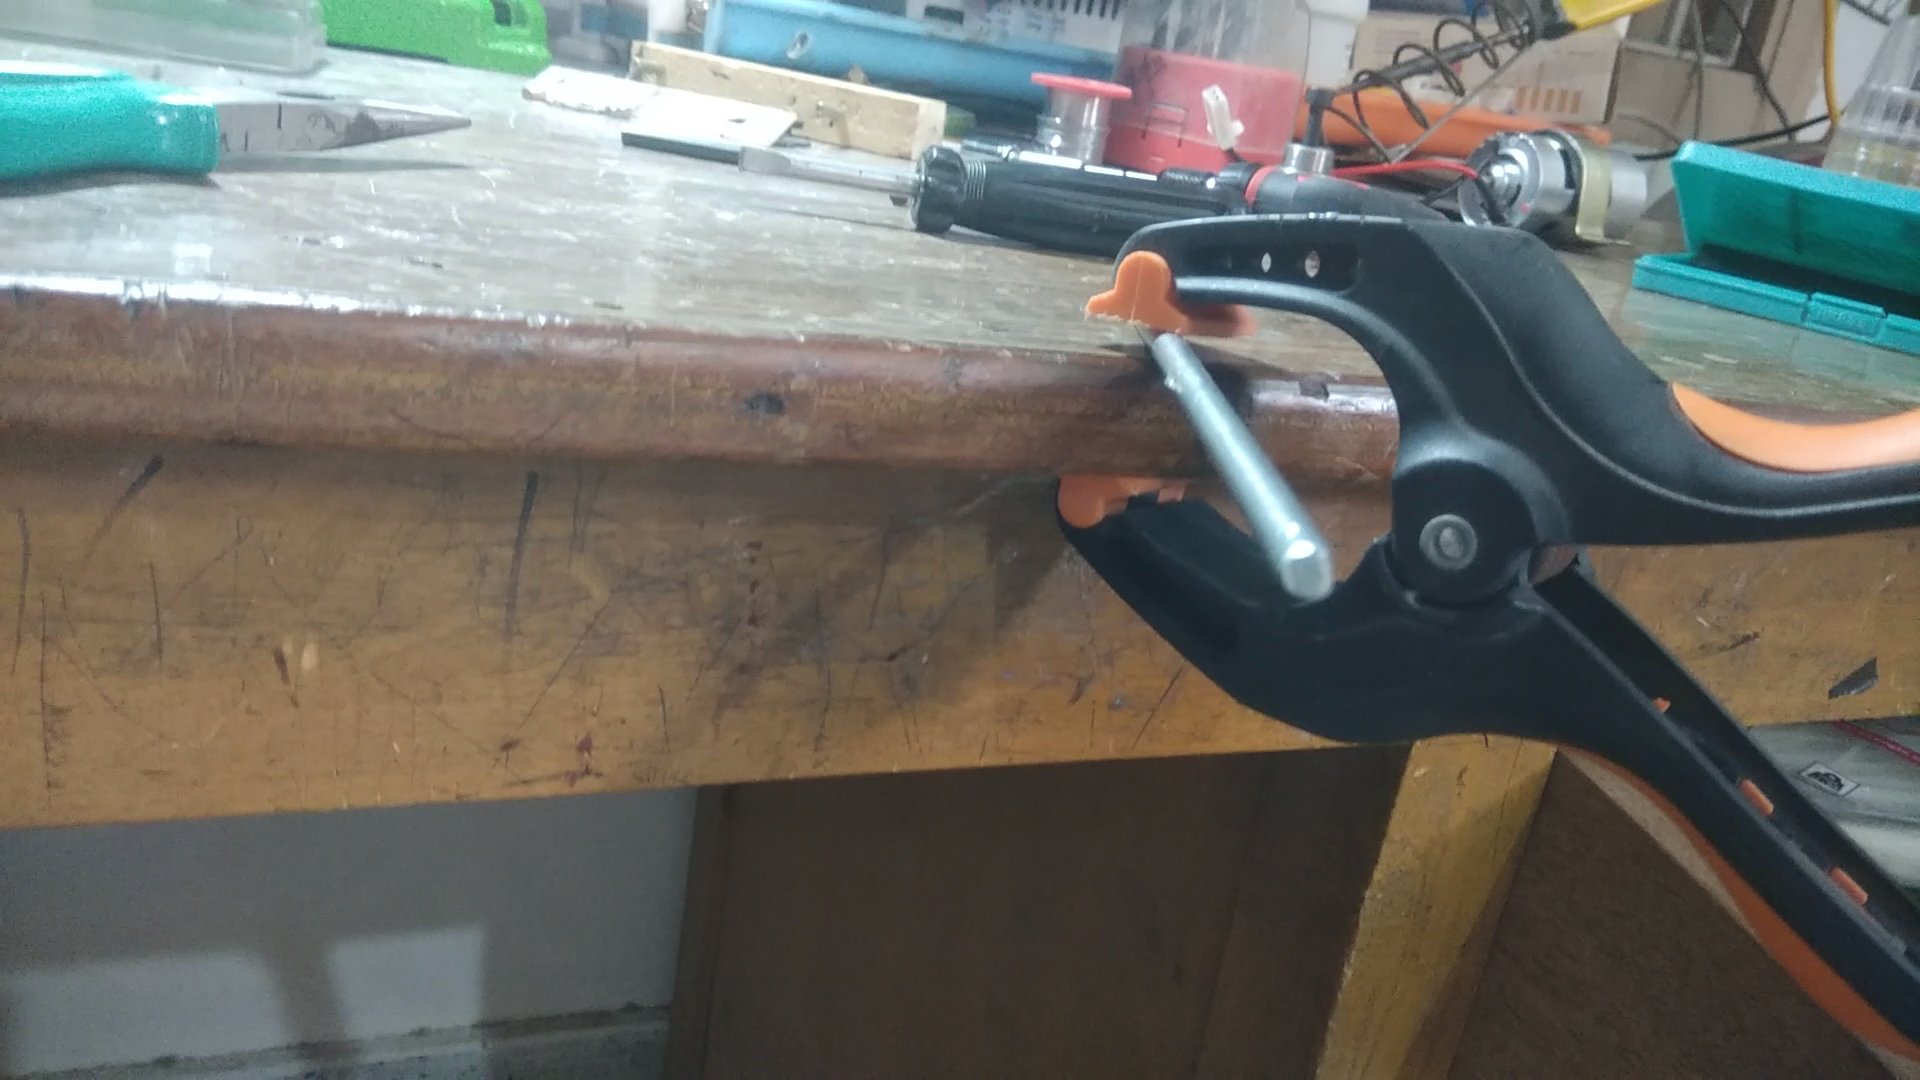

High-RPM rotation easily triggers extreme noise and violent structural vibration. It required a multi-layered mechanical solution to fix:
1. Wheel Upgrade & Hub Precision
The initial plastic wheels with rubber treads suffered from poor manufacturing run-out, face wobble, a loose bore fit, and peeling treads. Replacing them with premium 4-inch PU wheels paired with custom-machined MS hubs drastically improved mounting alignment on the motor shafts.
2. Custom DIY Static Wheel Balancing
Because dynamic balancing equipment wasn't available, a highly effective workshop method was created:
- Each wheel was mounted on a smooth 6mm rod supported by free-spinning bearings.
- When spun, the wheel naturally settled with its heaviest point at the bottom.
- Trial weights (like cable ties or nuts) were added to the exact opposite side.
- Results: The first wheel required a permanently attached 2.19g bolt/nut combo to achieve balance; the second wheel required a 1.17g trimmed weight. Both now spin smoothly without catching at a single heavy point.
3. Structural Isolation
Even balanced wheels pass micro-vibrations into a chassis. Strips of rubber sheeting and vibration isolation pads were layered tightly between the motor clamps, the FR4 support pieces, and the wooden mounting blocks. Together, balancing and isolation reduced system noise to near-silent levels below 70% motor speed, and safely manageable levels above it.
Mechanical Ball-Feeding & Control Sequence


The feeding assembly is driven entirely by gravity and simple mechanical timing, removing the need for complex digital programming.
Key Subsystems:
- The PVC Piston Gate: Machined with a 1–2mm clearance inside the barrel to prevent friction . Its 1¾-inch width is intentional: when it moves forward to push a ball out, its solid body slides directly under the vertical chute, blocking the remaining balls from dropping down until it returns.
- Solenoid Blocking Pin: A physical pin sits in front of the ball when the machine is waiting. This positively stops a ball from accidentally rolling premature into the wheels until the cycle actively triggers.
- Crank Mechanism: A 30 RPM geared motor spins a disc connected to a mechanical link arm, converting rotary spin into a clean, repeatable back-and-forth linear piston stroke.
The 6-Step Delivery Sequence:
- Wait State: The piston sits fully retracted. One ball drops into the barrel; the solenoid pin is up and blocking the ball movement in to the wheel gap.
- Cycle Starts: The 30 RPM feed motor engages, turning the crank disc.
- Release: The solenoid energizes and retracts the blocking pin.
- Feed Stroke: The piston travels forward, pushing the ball in to the wheel gap while simultaneously blocking the vertical ball feeding chute.
- Launch: The ball hits the high-speed wheel nip, and shoots forward.
- Reset: The piston pulls back, the solenoid drops and the blocking pin comes up again , when the piston moves sufficiently back, the next ball drops into the barrel, and a microswitch stops the feed motor precisely at the "home" position.
Real-World Testing & Key Findings
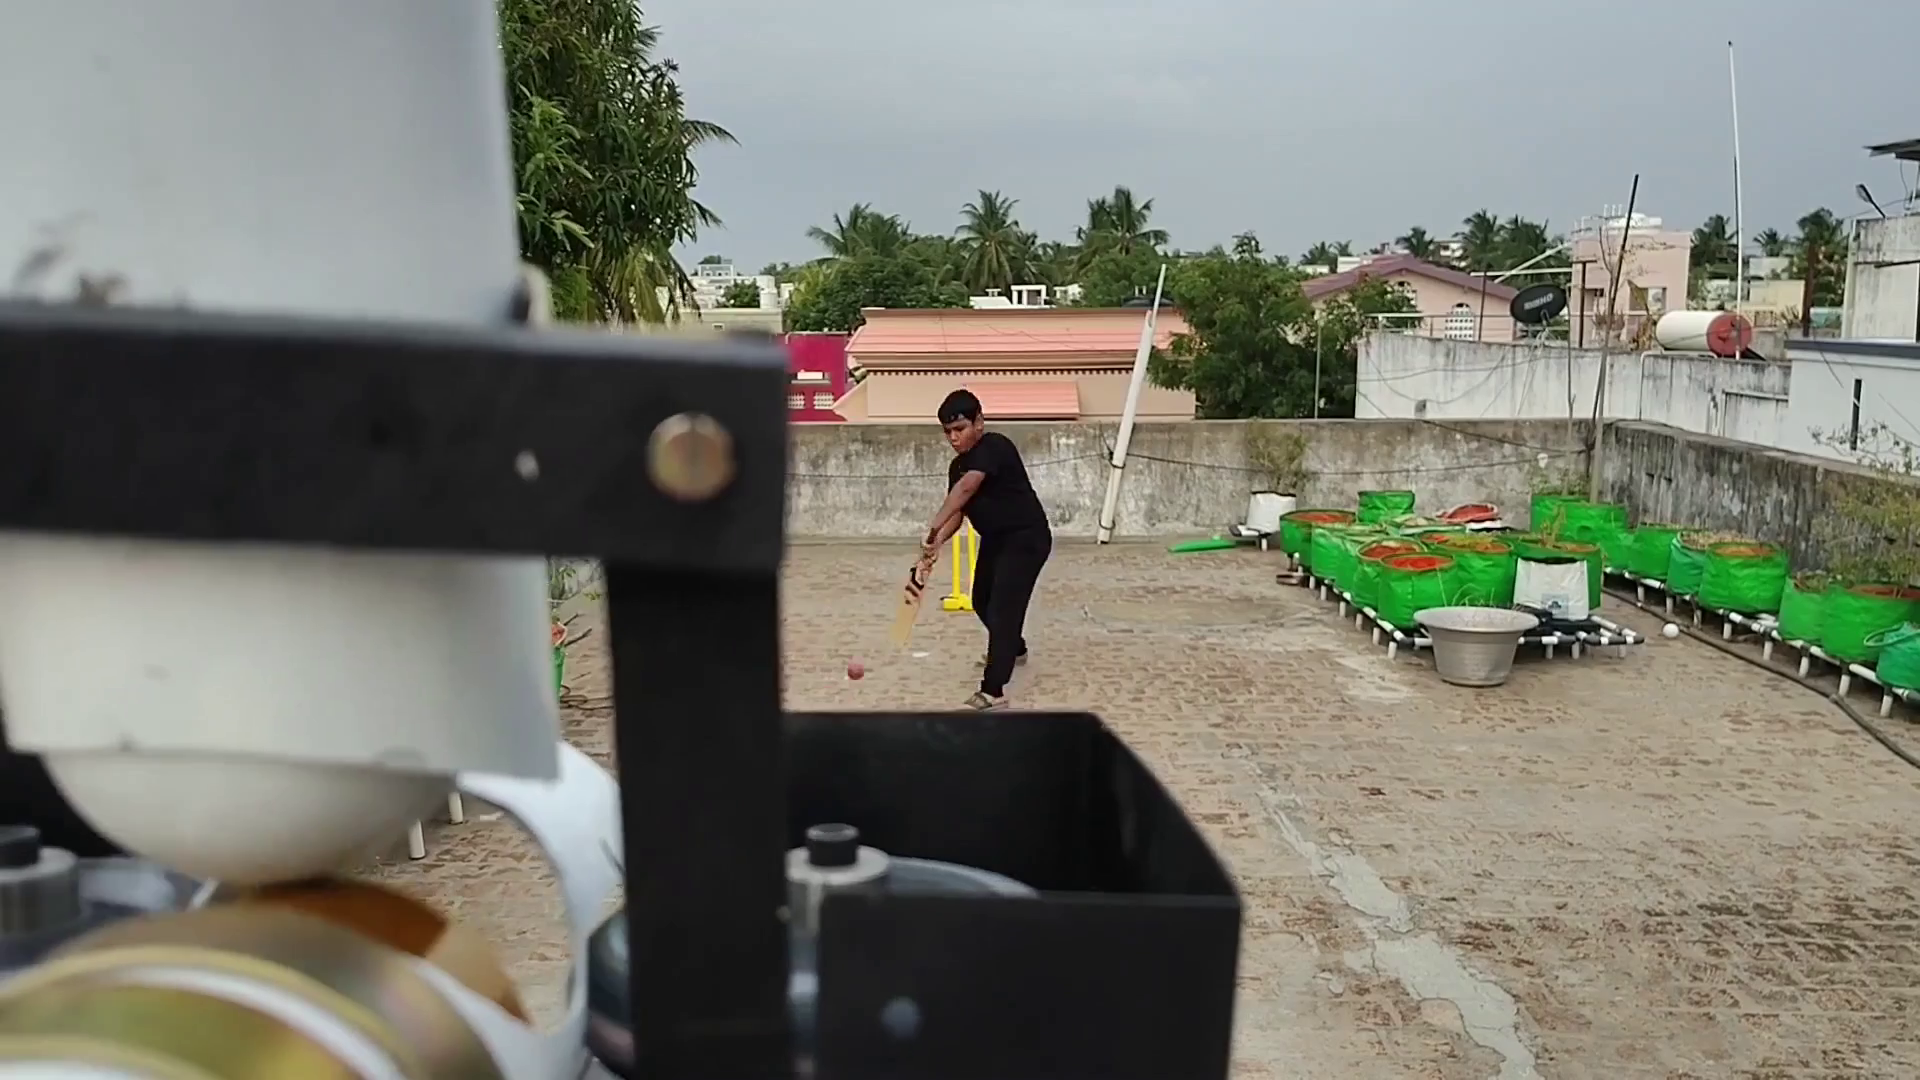


The prototype underwent extended testing sessions (including consecutive 8-over and 10-over trials) with excellent results.
- Trajectory & Tracking: Deliveries were straight and highly repeatable. The initial ball exit velocity was so fast that tracking it visually right out of the machine was difficult.
- Electrical Reliability: The 12V 7.2Ah battery ran flawlessly without visible voltage drops, and the RS775 motors stayed at safe, warm operating temperatures.
- Ball Entry Behaviour: Small white contact marks on the wheel rubber showed that balls entered slightly above centre due to natural rolling clearance inside the pipe guide. Adjusting the wheel height did not change this, but performance remained highly satisfactory.
- Ball Hardness Impact: Tests proved that firm, rigid plastic balls maintained higher exit velocities. Softer, worn-out balls deformed under wheel pressure, absorbed energy, slipped, and launched with significantly lower speeds.
- Tennis Ball Limitations: A brief trial was conducted with tennis balls using maximum possible adjusted 50mm wheel gap. While the machine successfully launched them, the resulting exit velocity was low due to torque limits or insufficient compression.
Smartphone Speed Tracking Limitations:
Attempts were made to calculate exact exit speeds using a smartphone camera (30 FPS) over 1-meter and 5-meter distances. At 1 meter, the ball moved too fast to capture across frames. At 5 meters, the ball spanned roughly 12 to 14 frames, pointing to a high average velocity. However, due to frame-counting uncertainty and rapid aerodynamic speed loss on lightweight plastic, standard phone cameras cannot accurately track true muzzle exit speed. No definitive speed rating will be published until professional radar or high-speed equipment is used.
Current Prototype Status & Future Plans
The bowling machine is considered a fully complete, working prototype and will remain completely unmodified for a 6-to-12-month observation window to track long-term part wear, battery cycle life, and structural reliability.
Next-Generation Upgrades Under Consideration:
- Larger Wheels: Moving to larger diameter wheels to achieve high ball speeds at lower motor RPM, reducing mechanical stress and vibration.
- Rigid Metal Base: Upgrading the wooden frame to a sleek, rigid 3mm to 4mm steel or aluminium plate.
- Enhanced Profiles: Adding a crowned profile to the wheel tread to wrap around the ball's curve for maximum surface grip.
- Smart ESP32 Integration: Implementing an ESP32 microcontroller running MicroPython to handle independent wheel speed variations (for spin/swing bowling), automated programmable sequences, random delivery patterns, and servo-controlled automatic tilt adjustments.
Project Links
- YouTube: YouTube video
- GitHub: GitHub Repository
- Hackaday.io: Hackaday.io project