Microbit Bug Robots: Popsicle StickBugs
by hypergami in Circuits > Microcontrollers
164 Views, 3 Favorites, 0 Comments
Microbit Bug Robots: Popsicle StickBugs

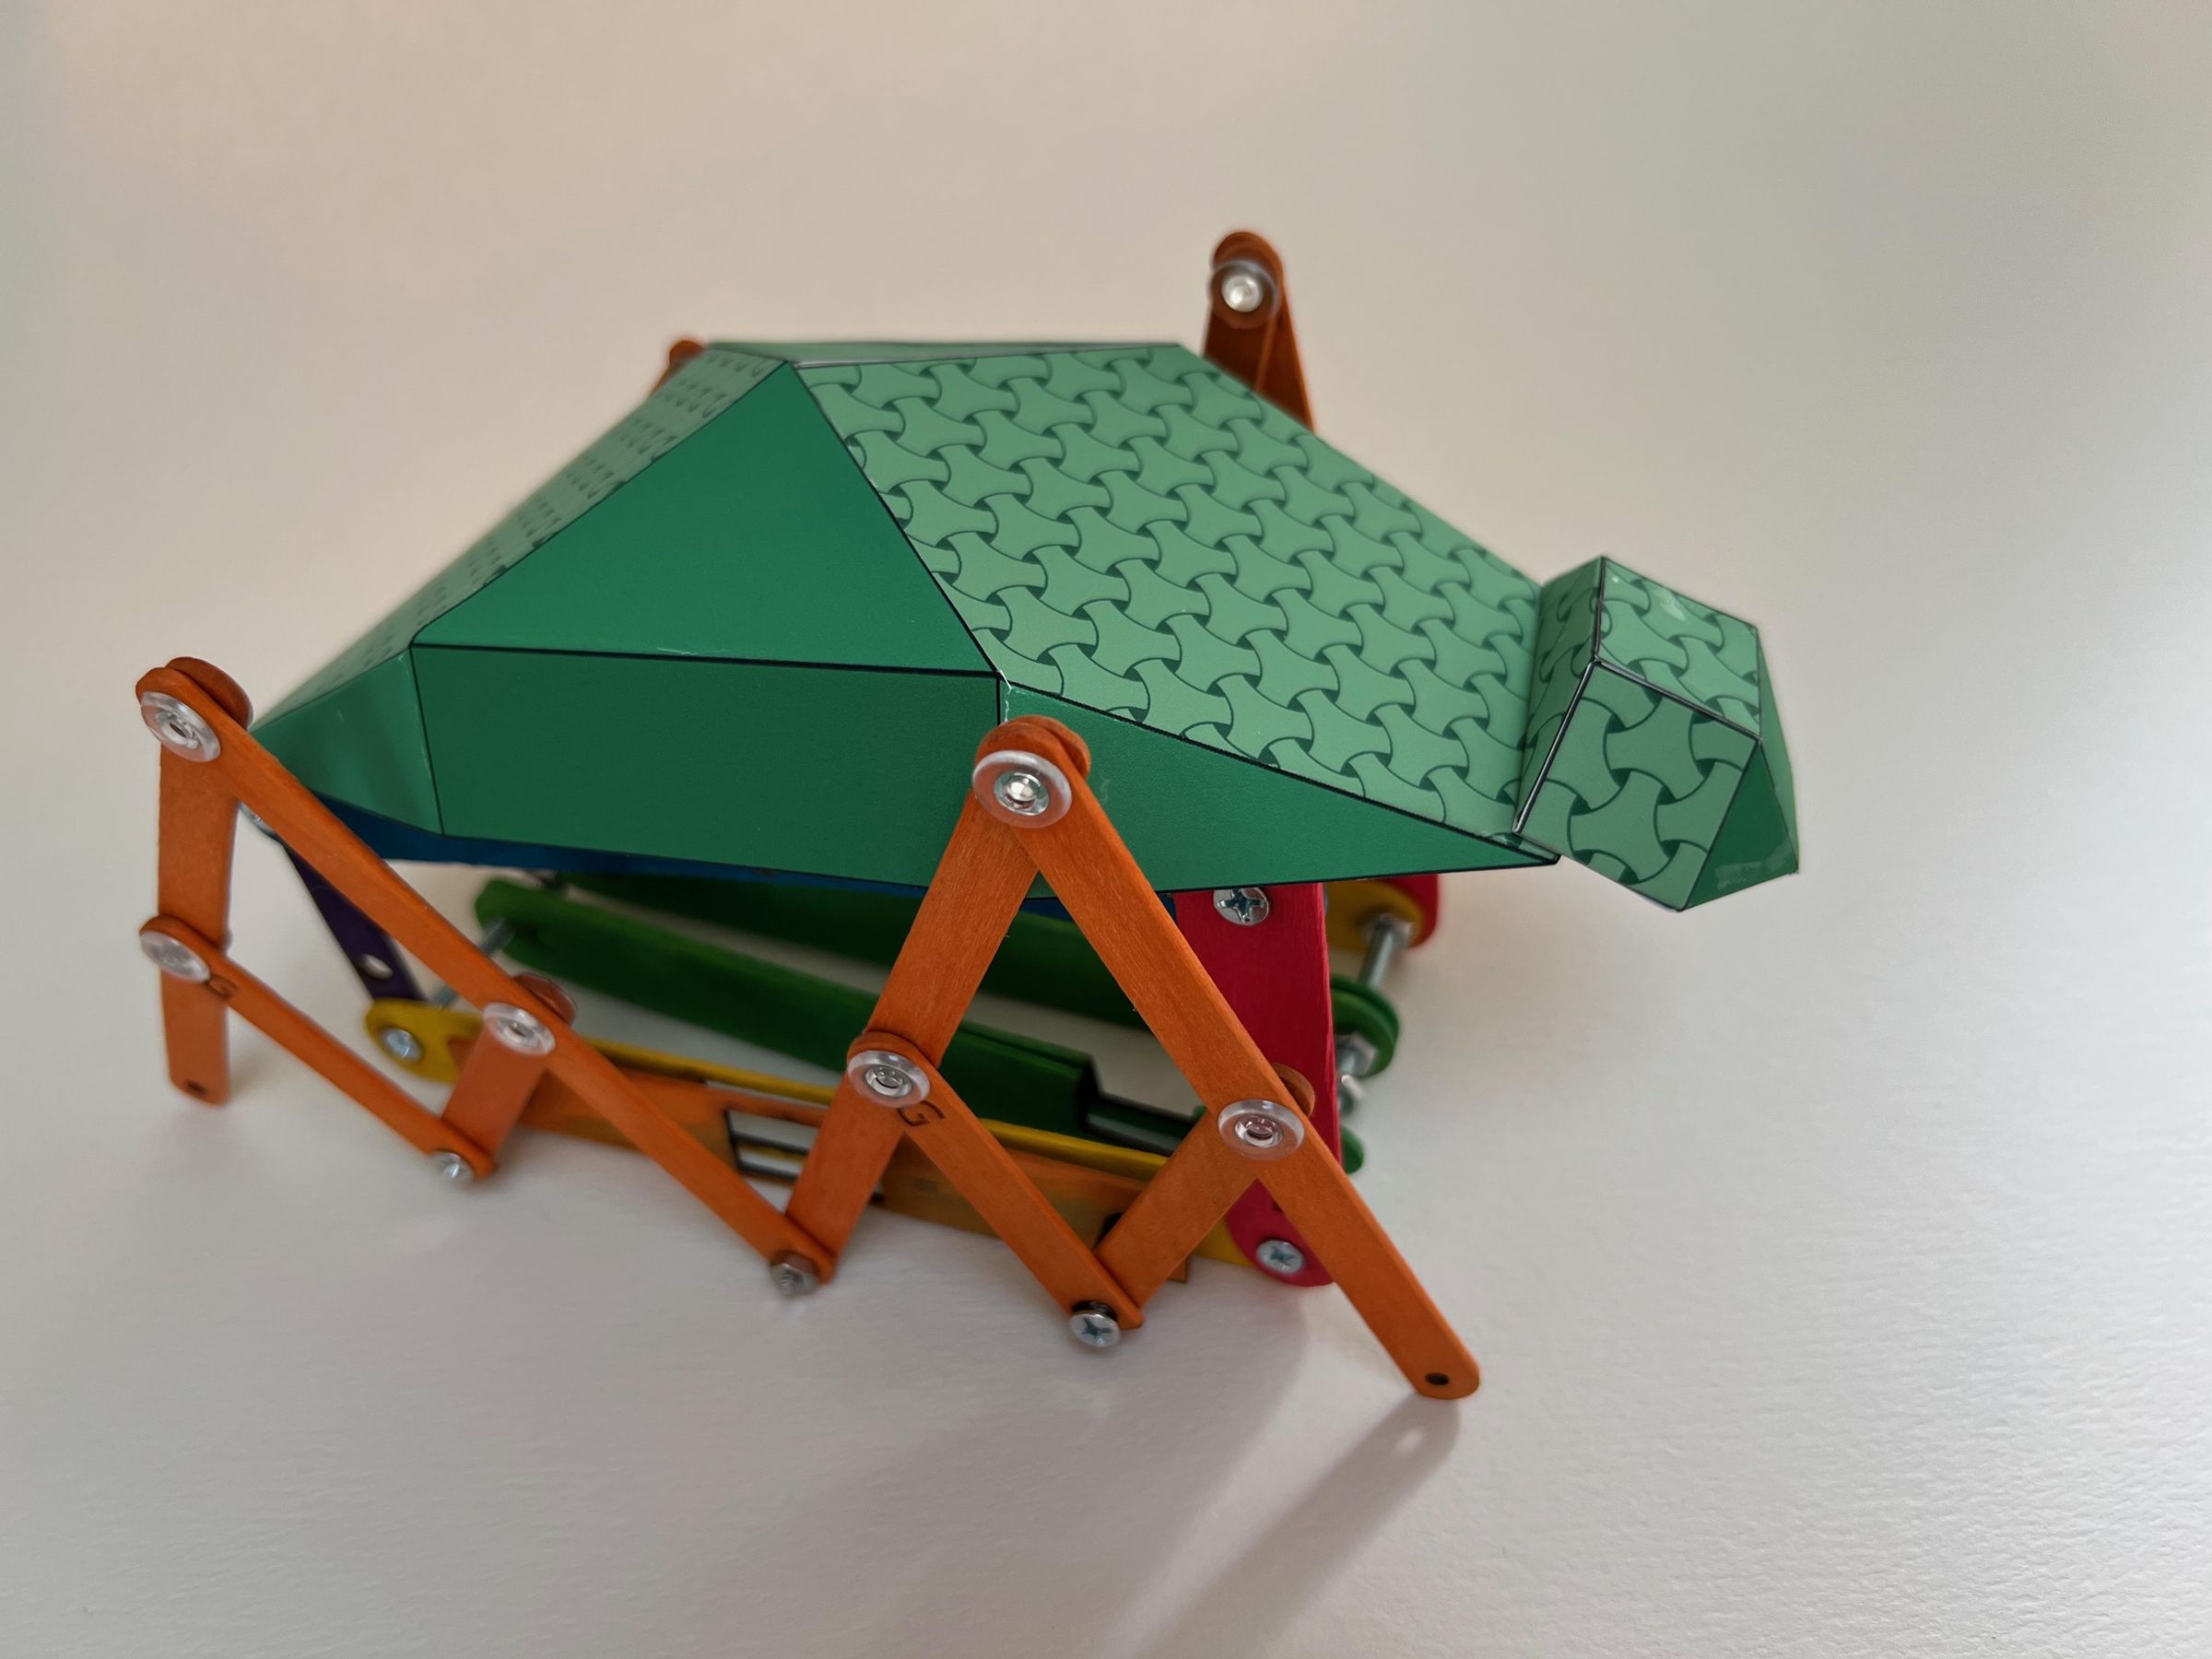
This is a micro:bit powered walking robot bug made with low-cost materials. It uses 2 servo motors, a micro:bit, breakout, popsicle sticks, and small hardware such as screws, nylon spacers, and fasteners. Video of fifth graders testing out the bug design is here.
Keywords: micro:bit, servo, STEM, bio-inspired design, robotics, K-12, education
Supplies
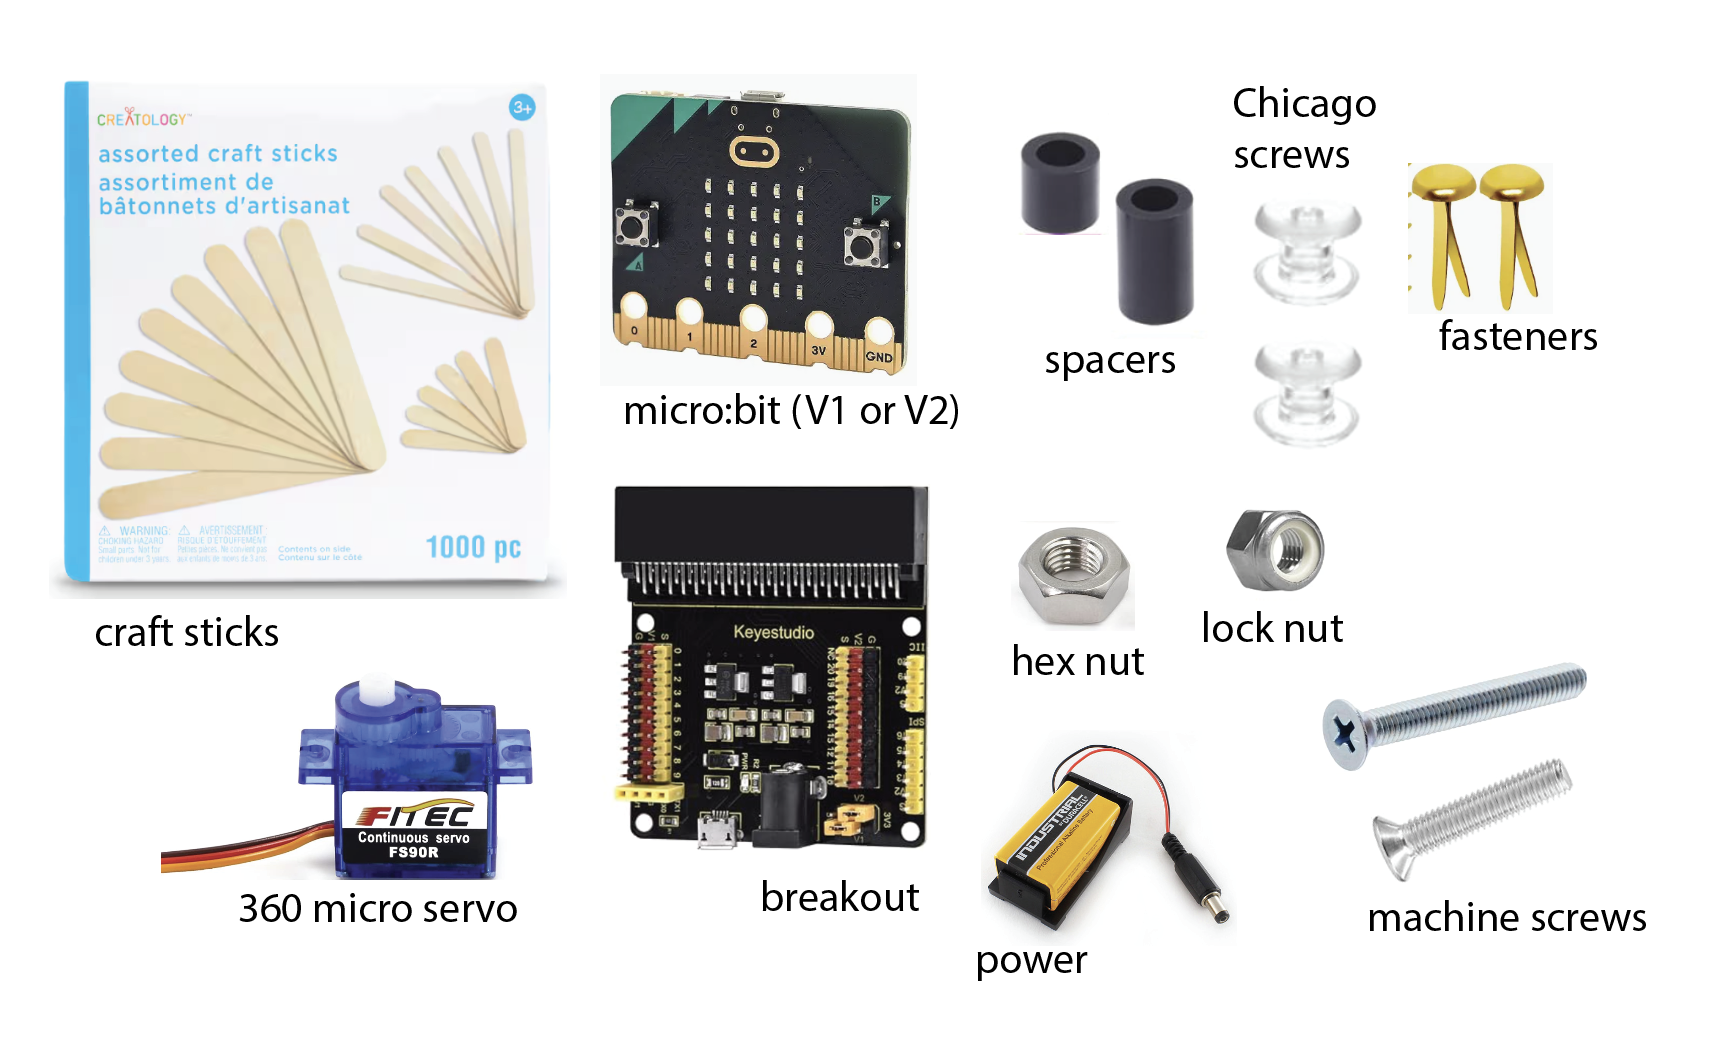
- (1) BBC micro:bit (V1 or V2)
- (1) micro:bit breakout of your choice (we use this one from Keyestudio)
- (1) power supply (we use a 9V battery with a barrel jack connector) - note that powering two servos requires more power than the on-board supply from the micro:bit.
- (2) 360 (continuous rotation) micro-servos, FS90R or similar. 2 servo horns and screws that come with them (these should be packaged with the servos).
- (8) Jumbo wood craft sticks (15 cm by 1.7 cm)
- (12) Smaller craft sticks (11.3 cm by .8 cm)
- (12) Paper fasteners OR (12) acrylic Chicago screws (M5 x 4 mm)
- (4) #6-32 x 1" machine screws
- (6) #6-32 hex nuts
- (4) #6-32 lock nuts
- (6) Long nylon spacers (N9-5*18) [or sturdy drinking straws cut to 18 mm that fit over the #6x32 screws, with an inner diameter of at least 5 mm]
- (4) Shorter nylon spacers (N9-5*10) [or sturdy drinking straws cut to 10 mm]
- (2) #6 x 32, 3" long machine screws
- craft supplies for creating bug details
- Either a laser cutter or a drill and Dremel to cut holes by hand
Prepare the Leg Sticks

- Cut the outer jig by anchoring a letter-sized sheet of cardboard or scrap wood to the bed of the laser cutter. Carefully remove the pieces without moving the jig.
- Place the craft sticks into the jig (12 small and 8 large).
- Run the cut file for the holes.
- Run the etch file for the labels.
- If you wish to laser cut the entire project without purchasing craft sticks, use 1/16" to 1/8" thick basswood.
Alternatively, if you do not have a laser cutter, print the Cut file as a template and use a drill and Dremel to create the holes. Write the stick numbers with a pencil.
Assemble the Legs

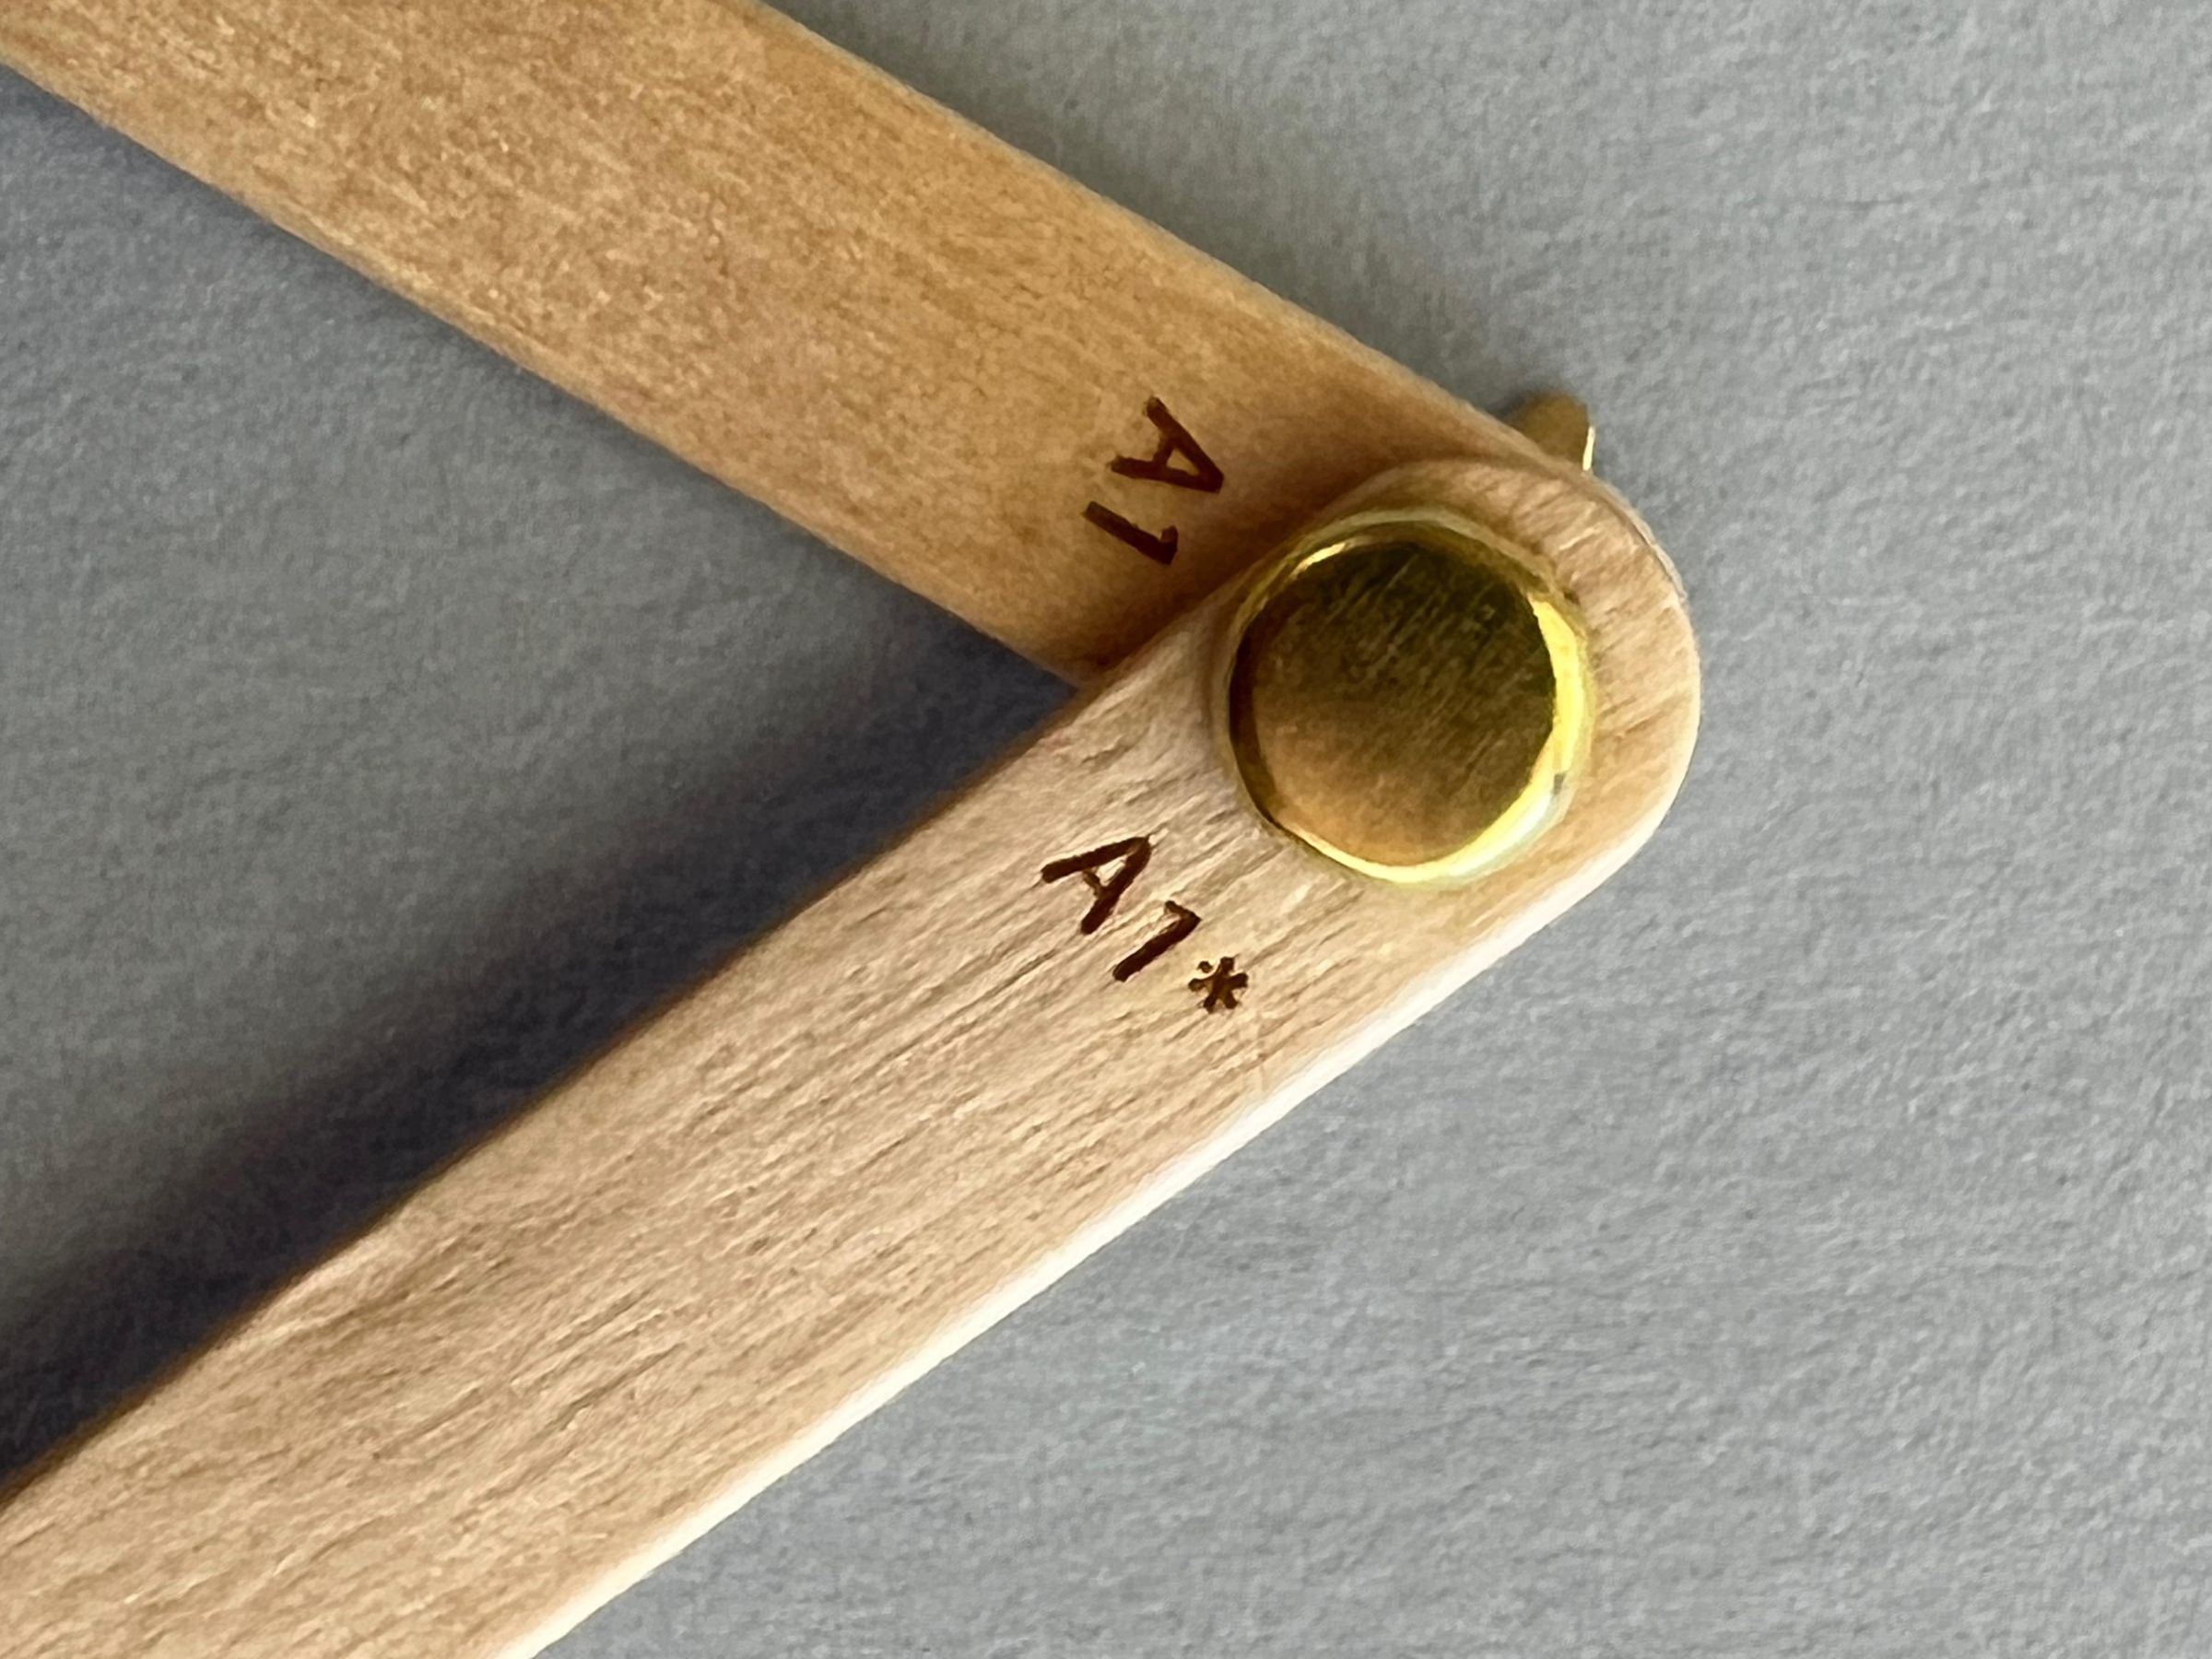
There are 4 sets: A, B, C, and D. Leg assemblies A and B are identical, as are C and D. Match holes by placing the same numbers together, taking care that the number with the * symbol goes on TOP (see the detail photo for an example). Attach with a metal fastener or acrylic Chicago screw. Note that these particular Chicago screws become permanently joined once snapped together, so double-check that things are correct before connecting them. Do not join the number 4 holes at the bottom center of each leg.
Add 1" Screws


Use the 1" machine screws to join the #4 hole for each assembly. Be careful to orient the hole with the * on top.
Add Spacers

Flip each leg assembly over so that the end of the machine screw is protruding, and add a (10 mm long) spacer. Do this for each set (A, B, C, D).
Join the Leg Assemblies

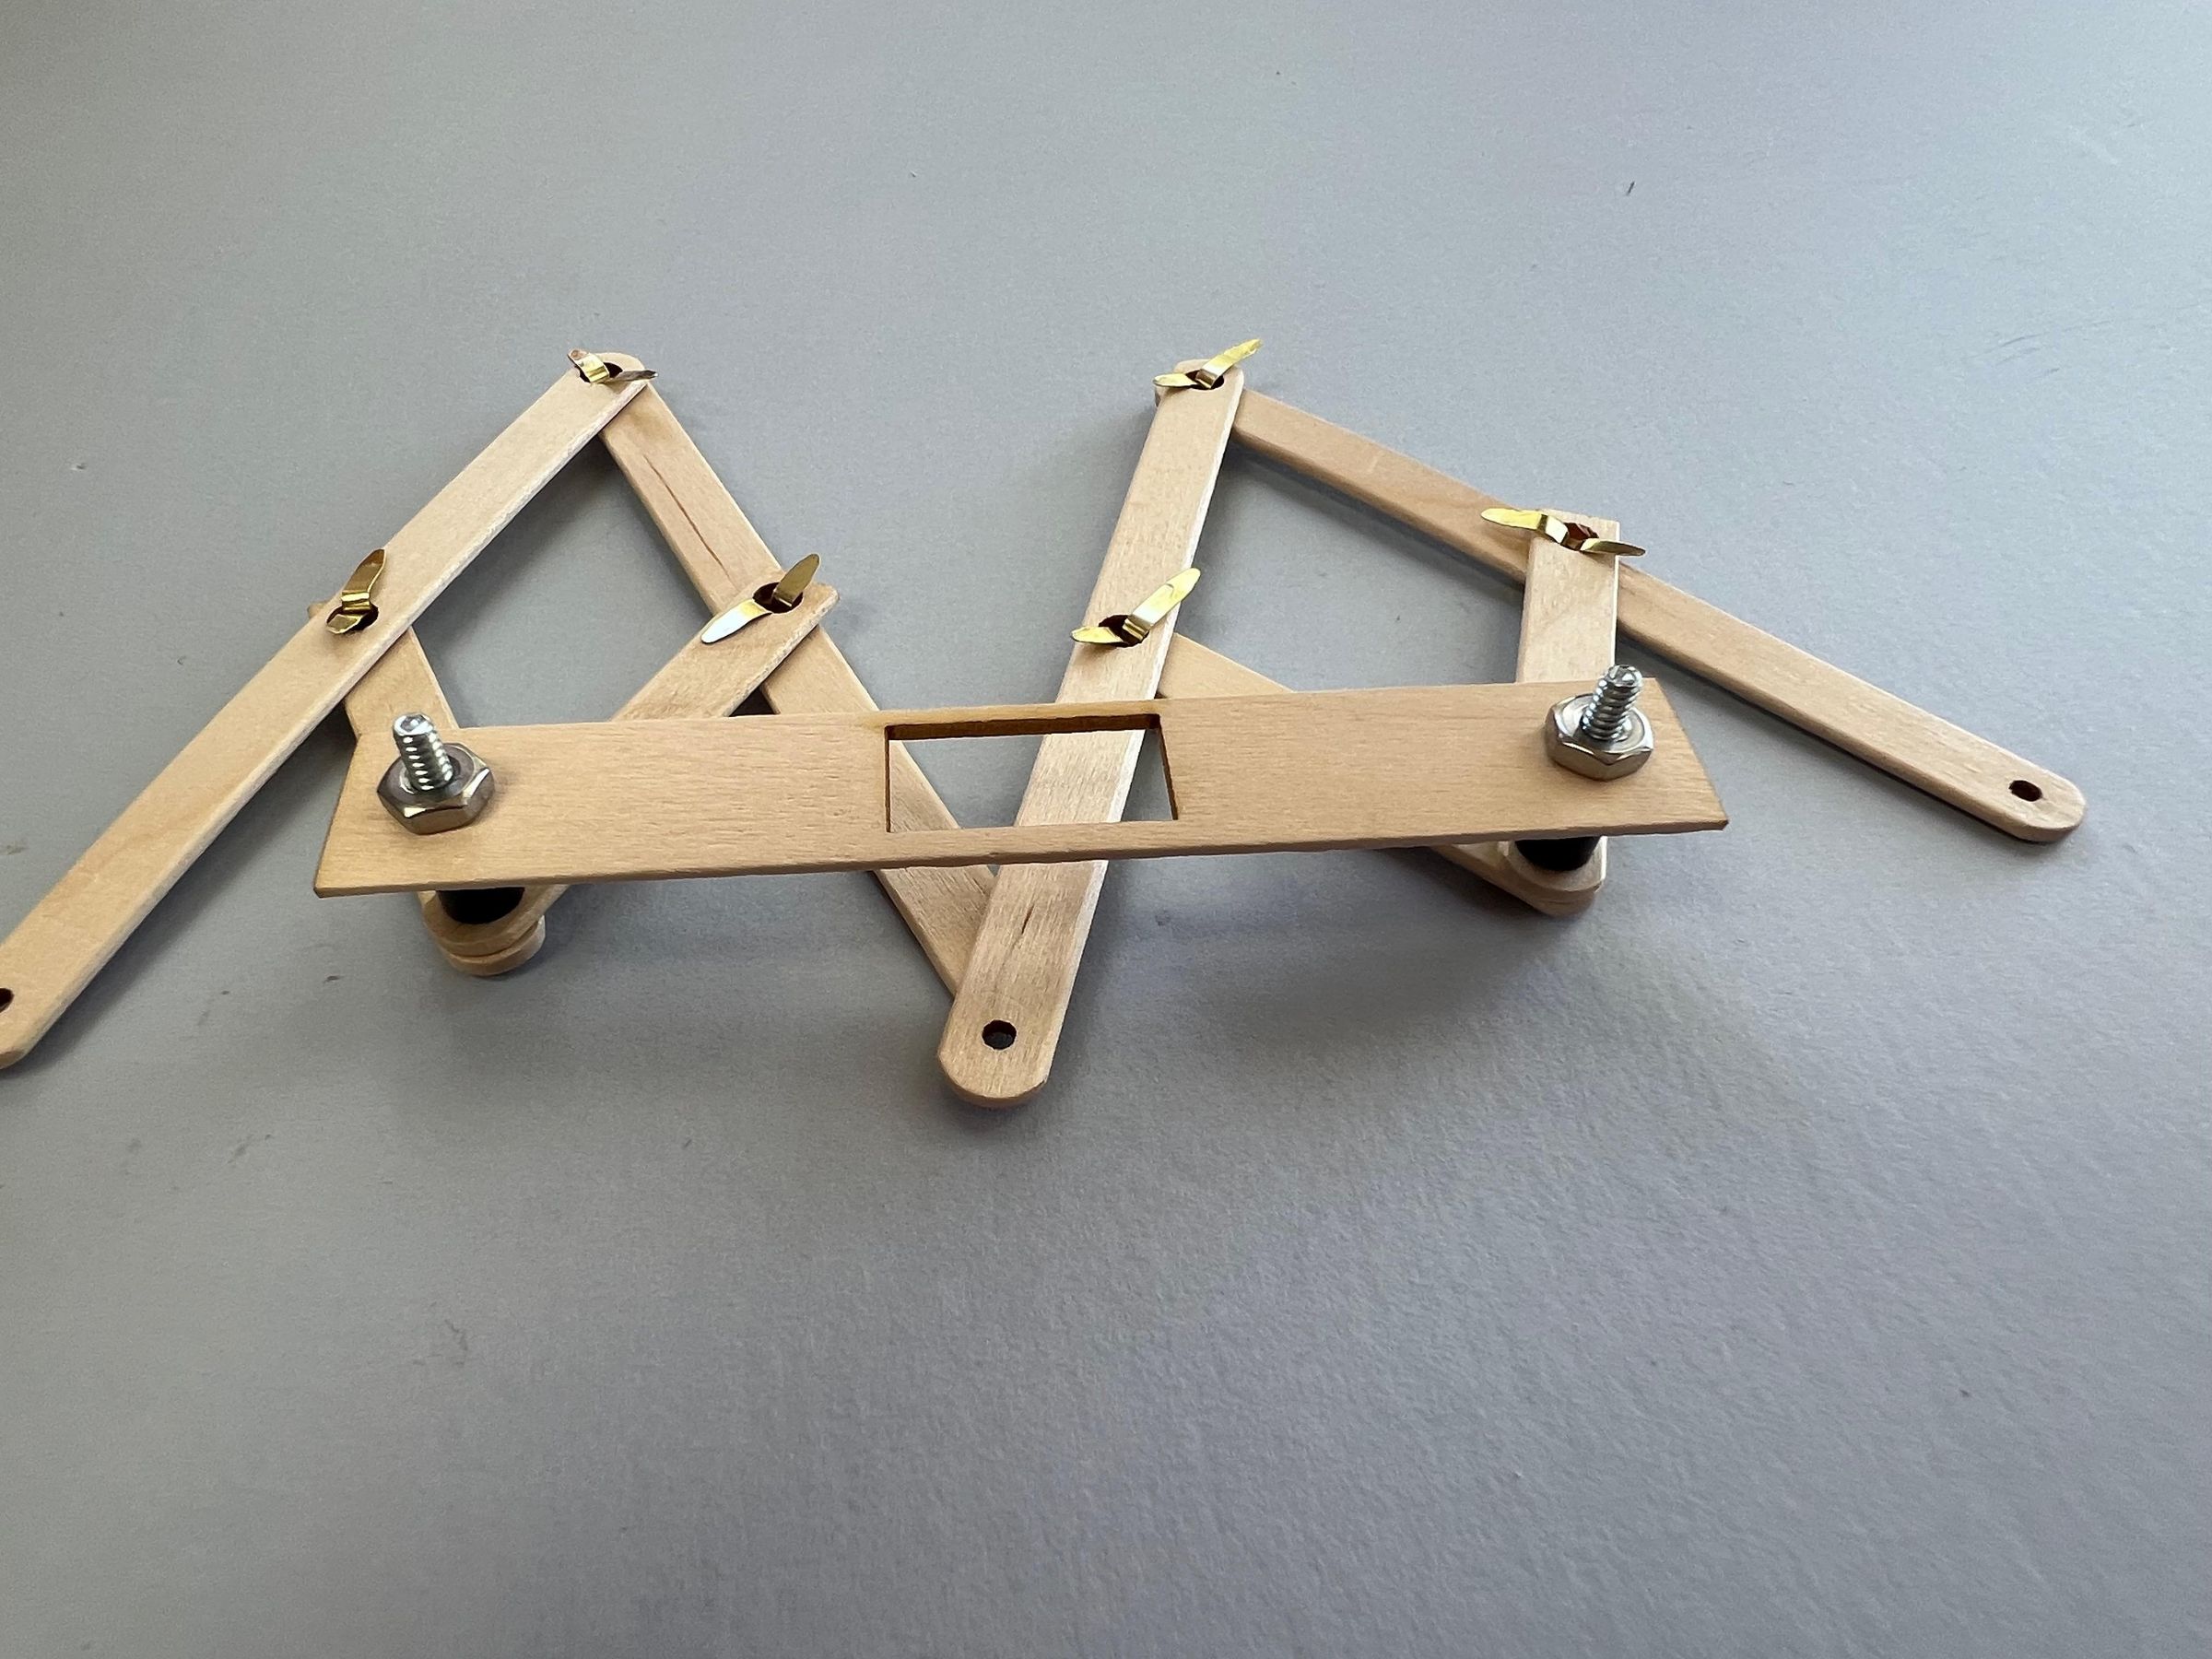
Use a rectangular piece to join leg assemblies A and B. Do the same to legs C and D. Secure each screw with a 6-32 hex nut.
Add the Long Window Piece
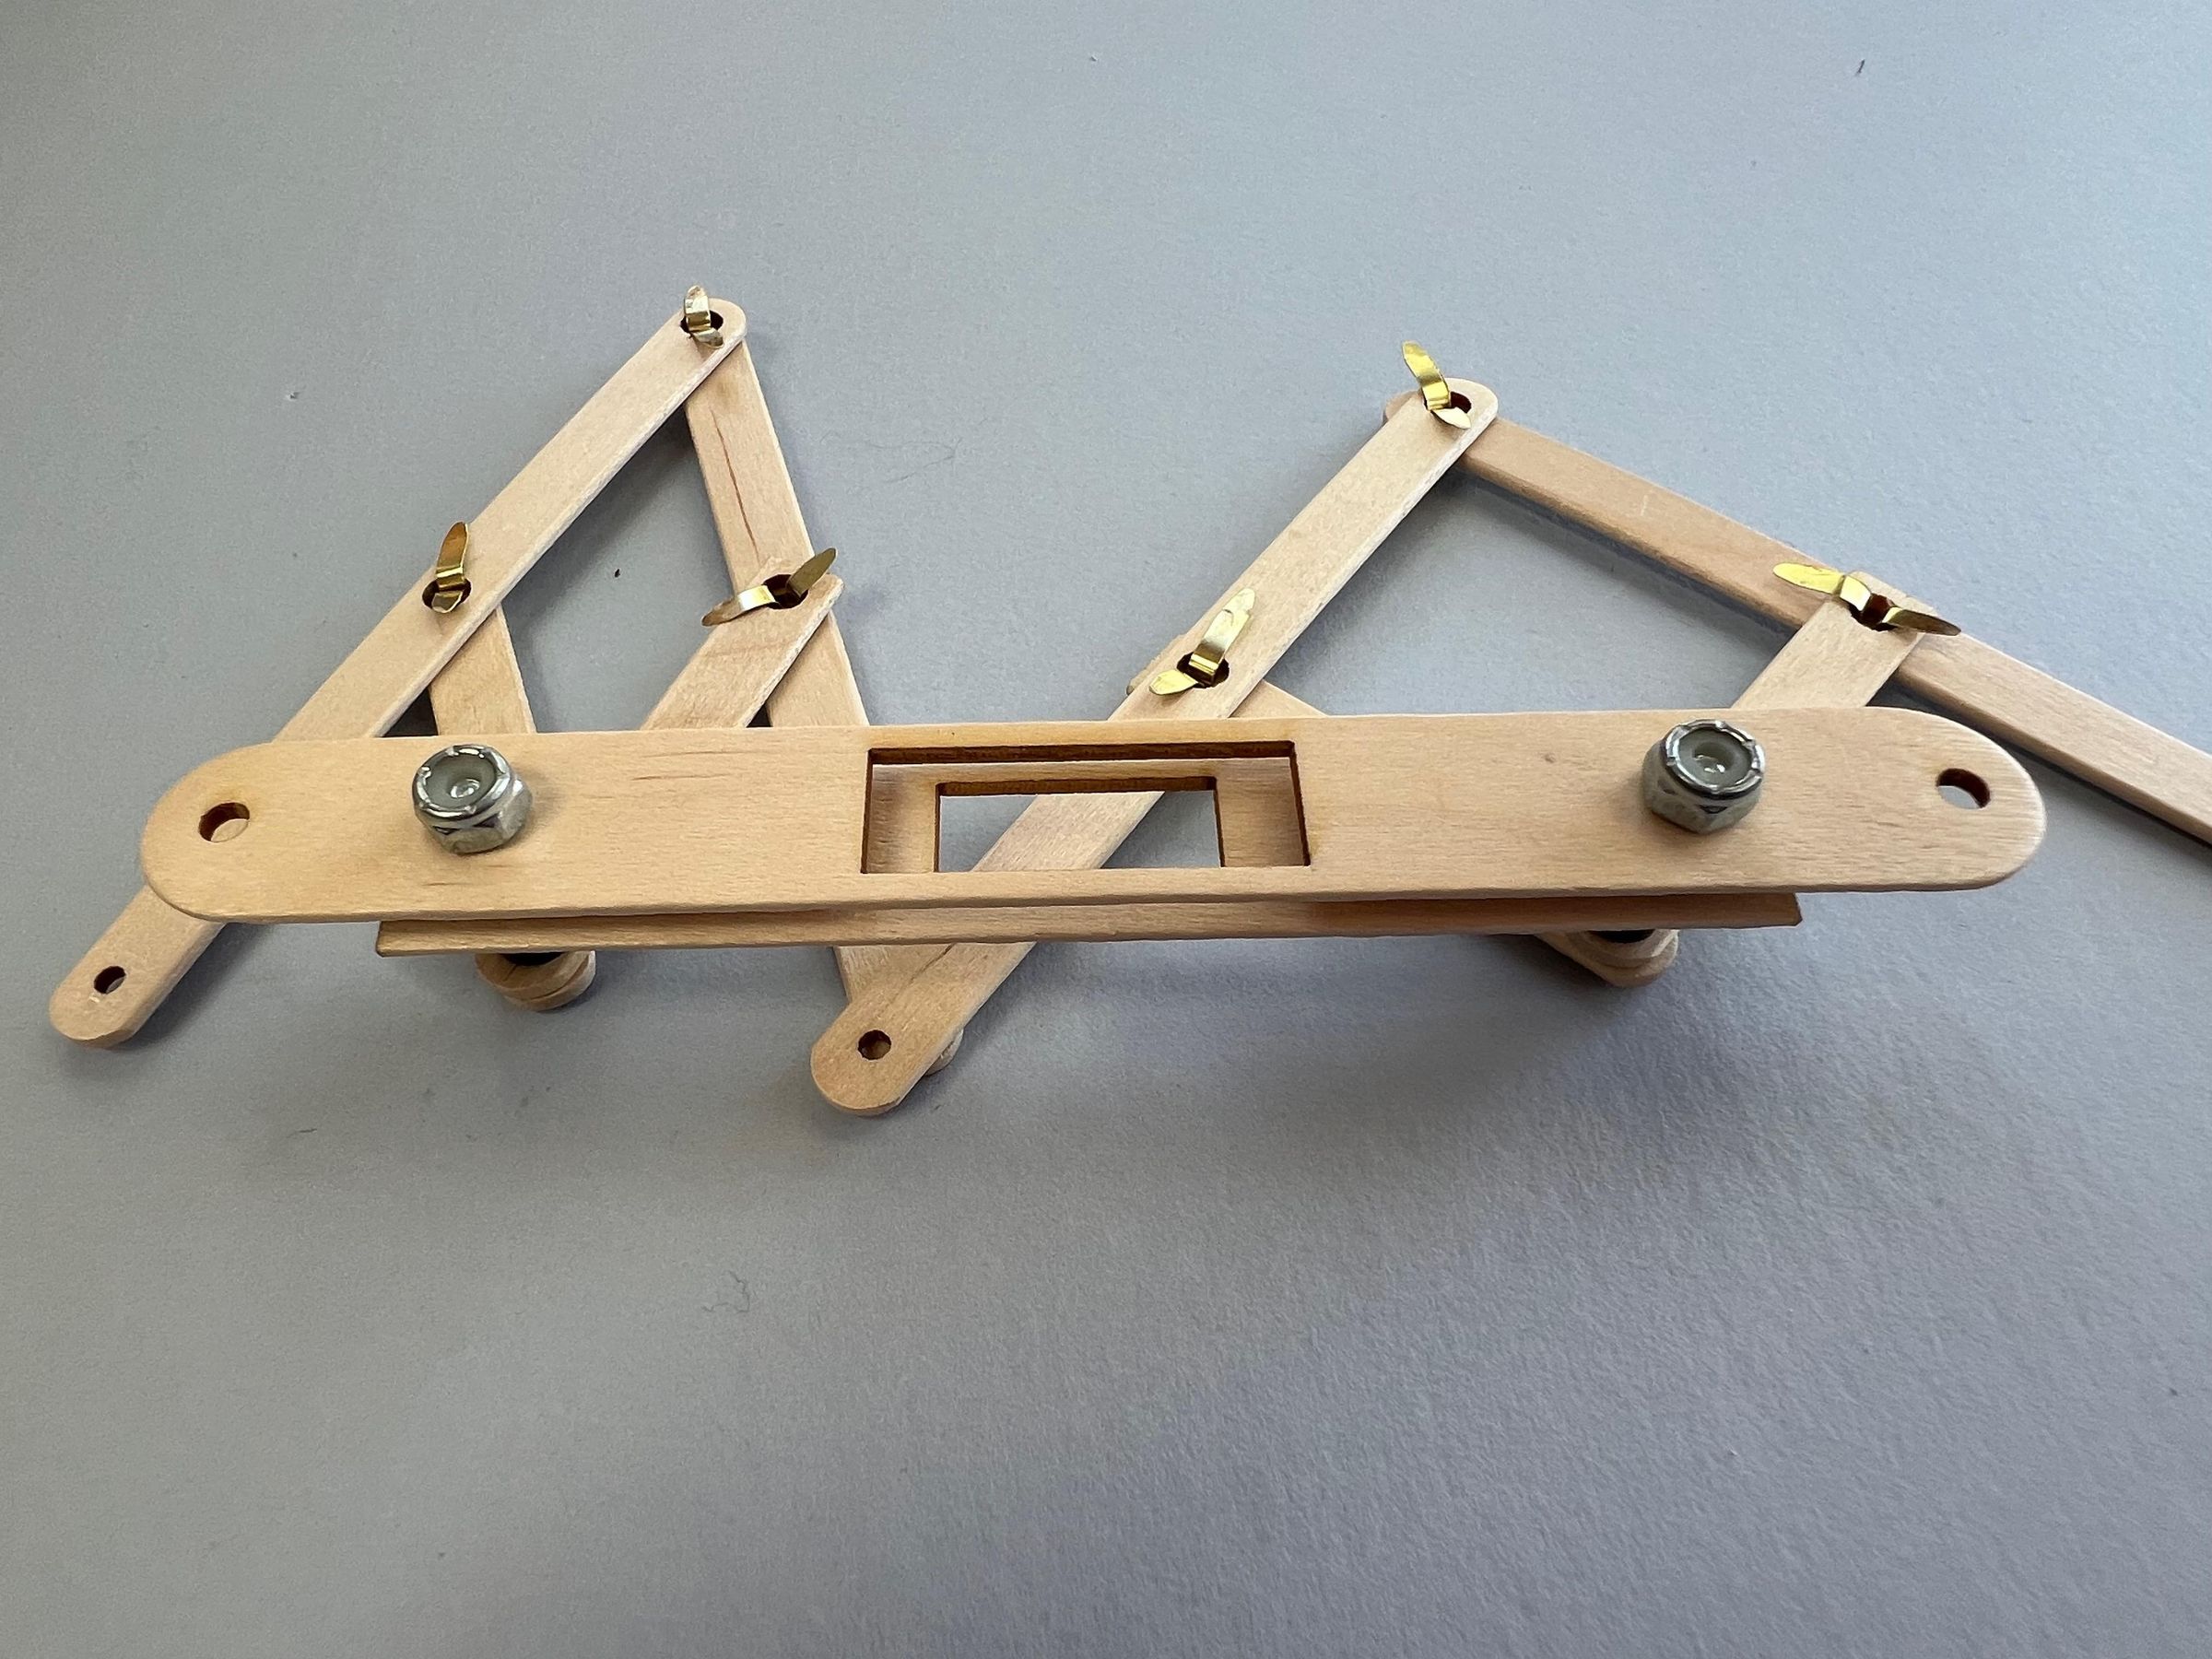
Add the longer piece with the central rectangular hole to each assembly. Secure it with a 6-32 locking nut. Do this for the A-B leg assembly and repeat for the C-D leg assembly.
Servo Motors
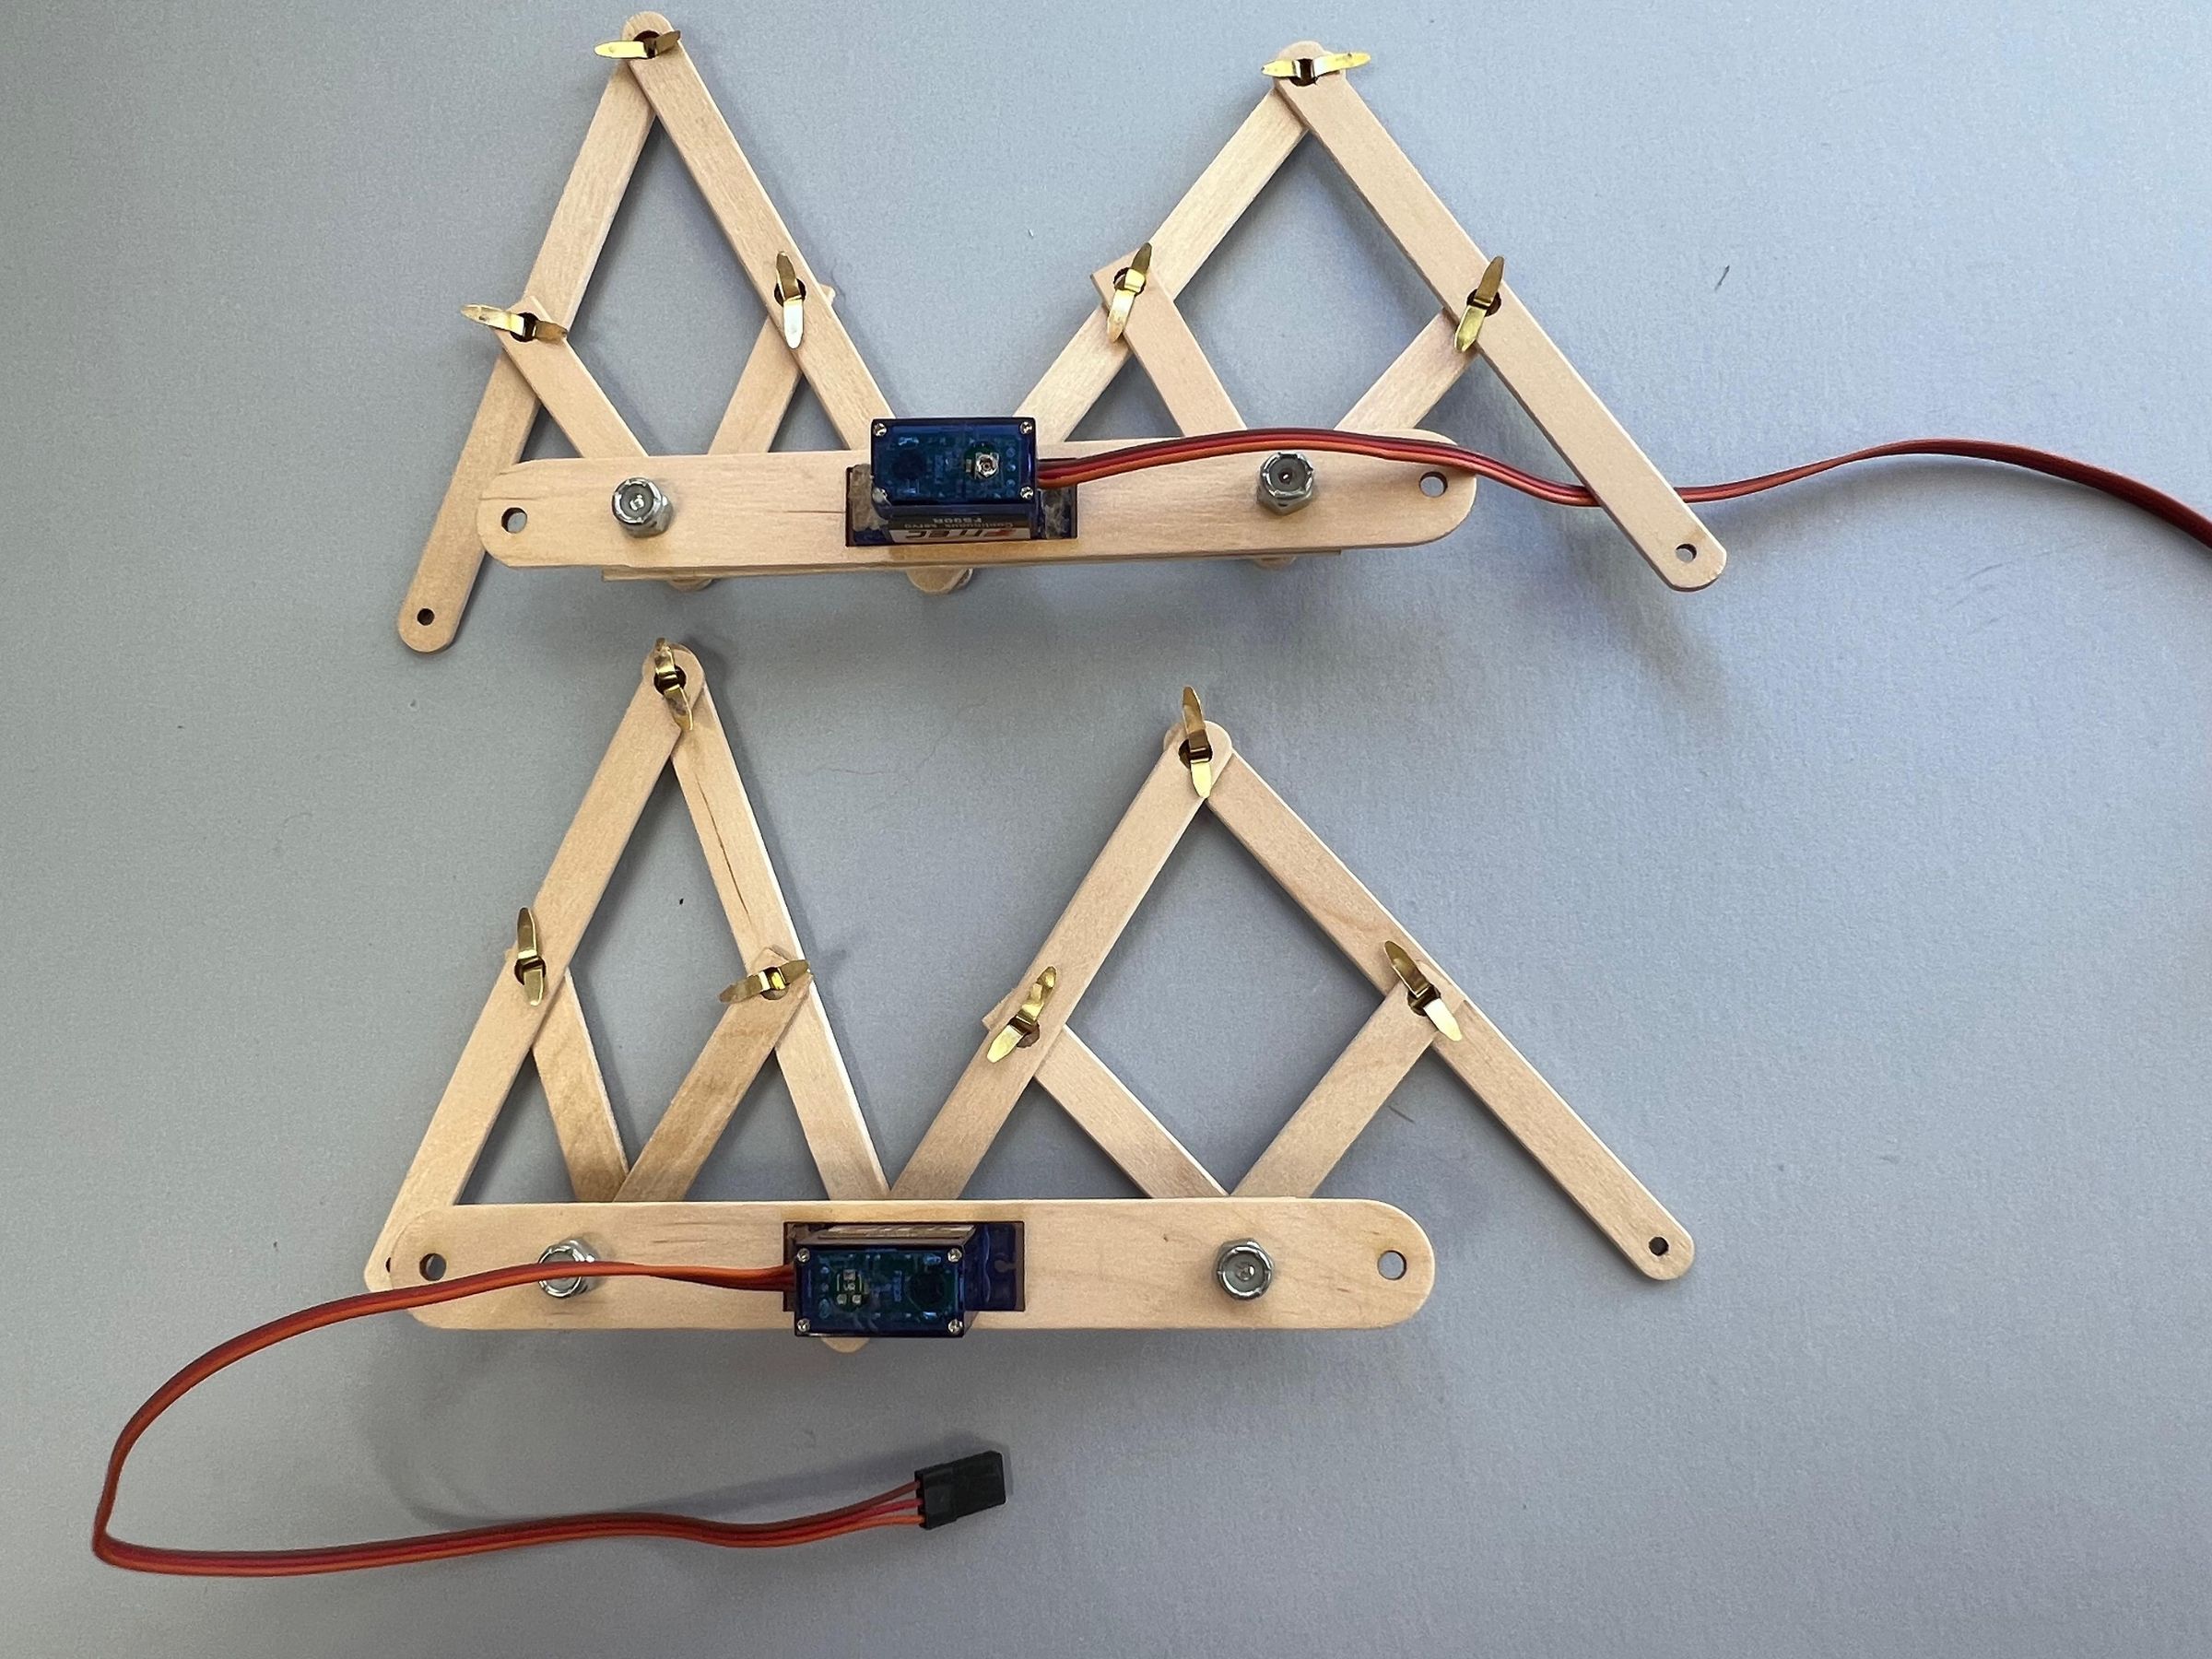

- First test your servos to be sure that they are working. These should be 360 (continuous) servos, not the standard 180.
- Attach a servo horn - just about any shape will work.
- Carefully insert one servo into the A-B assembly and another into the C-D assembly. Be sure that they are sitting in opposite orientations as shown in the photo (note that the wire is located on different sides). Optional: Use some hot glue or duct tape to hold the motor more firmly in place.
Bottom Frame


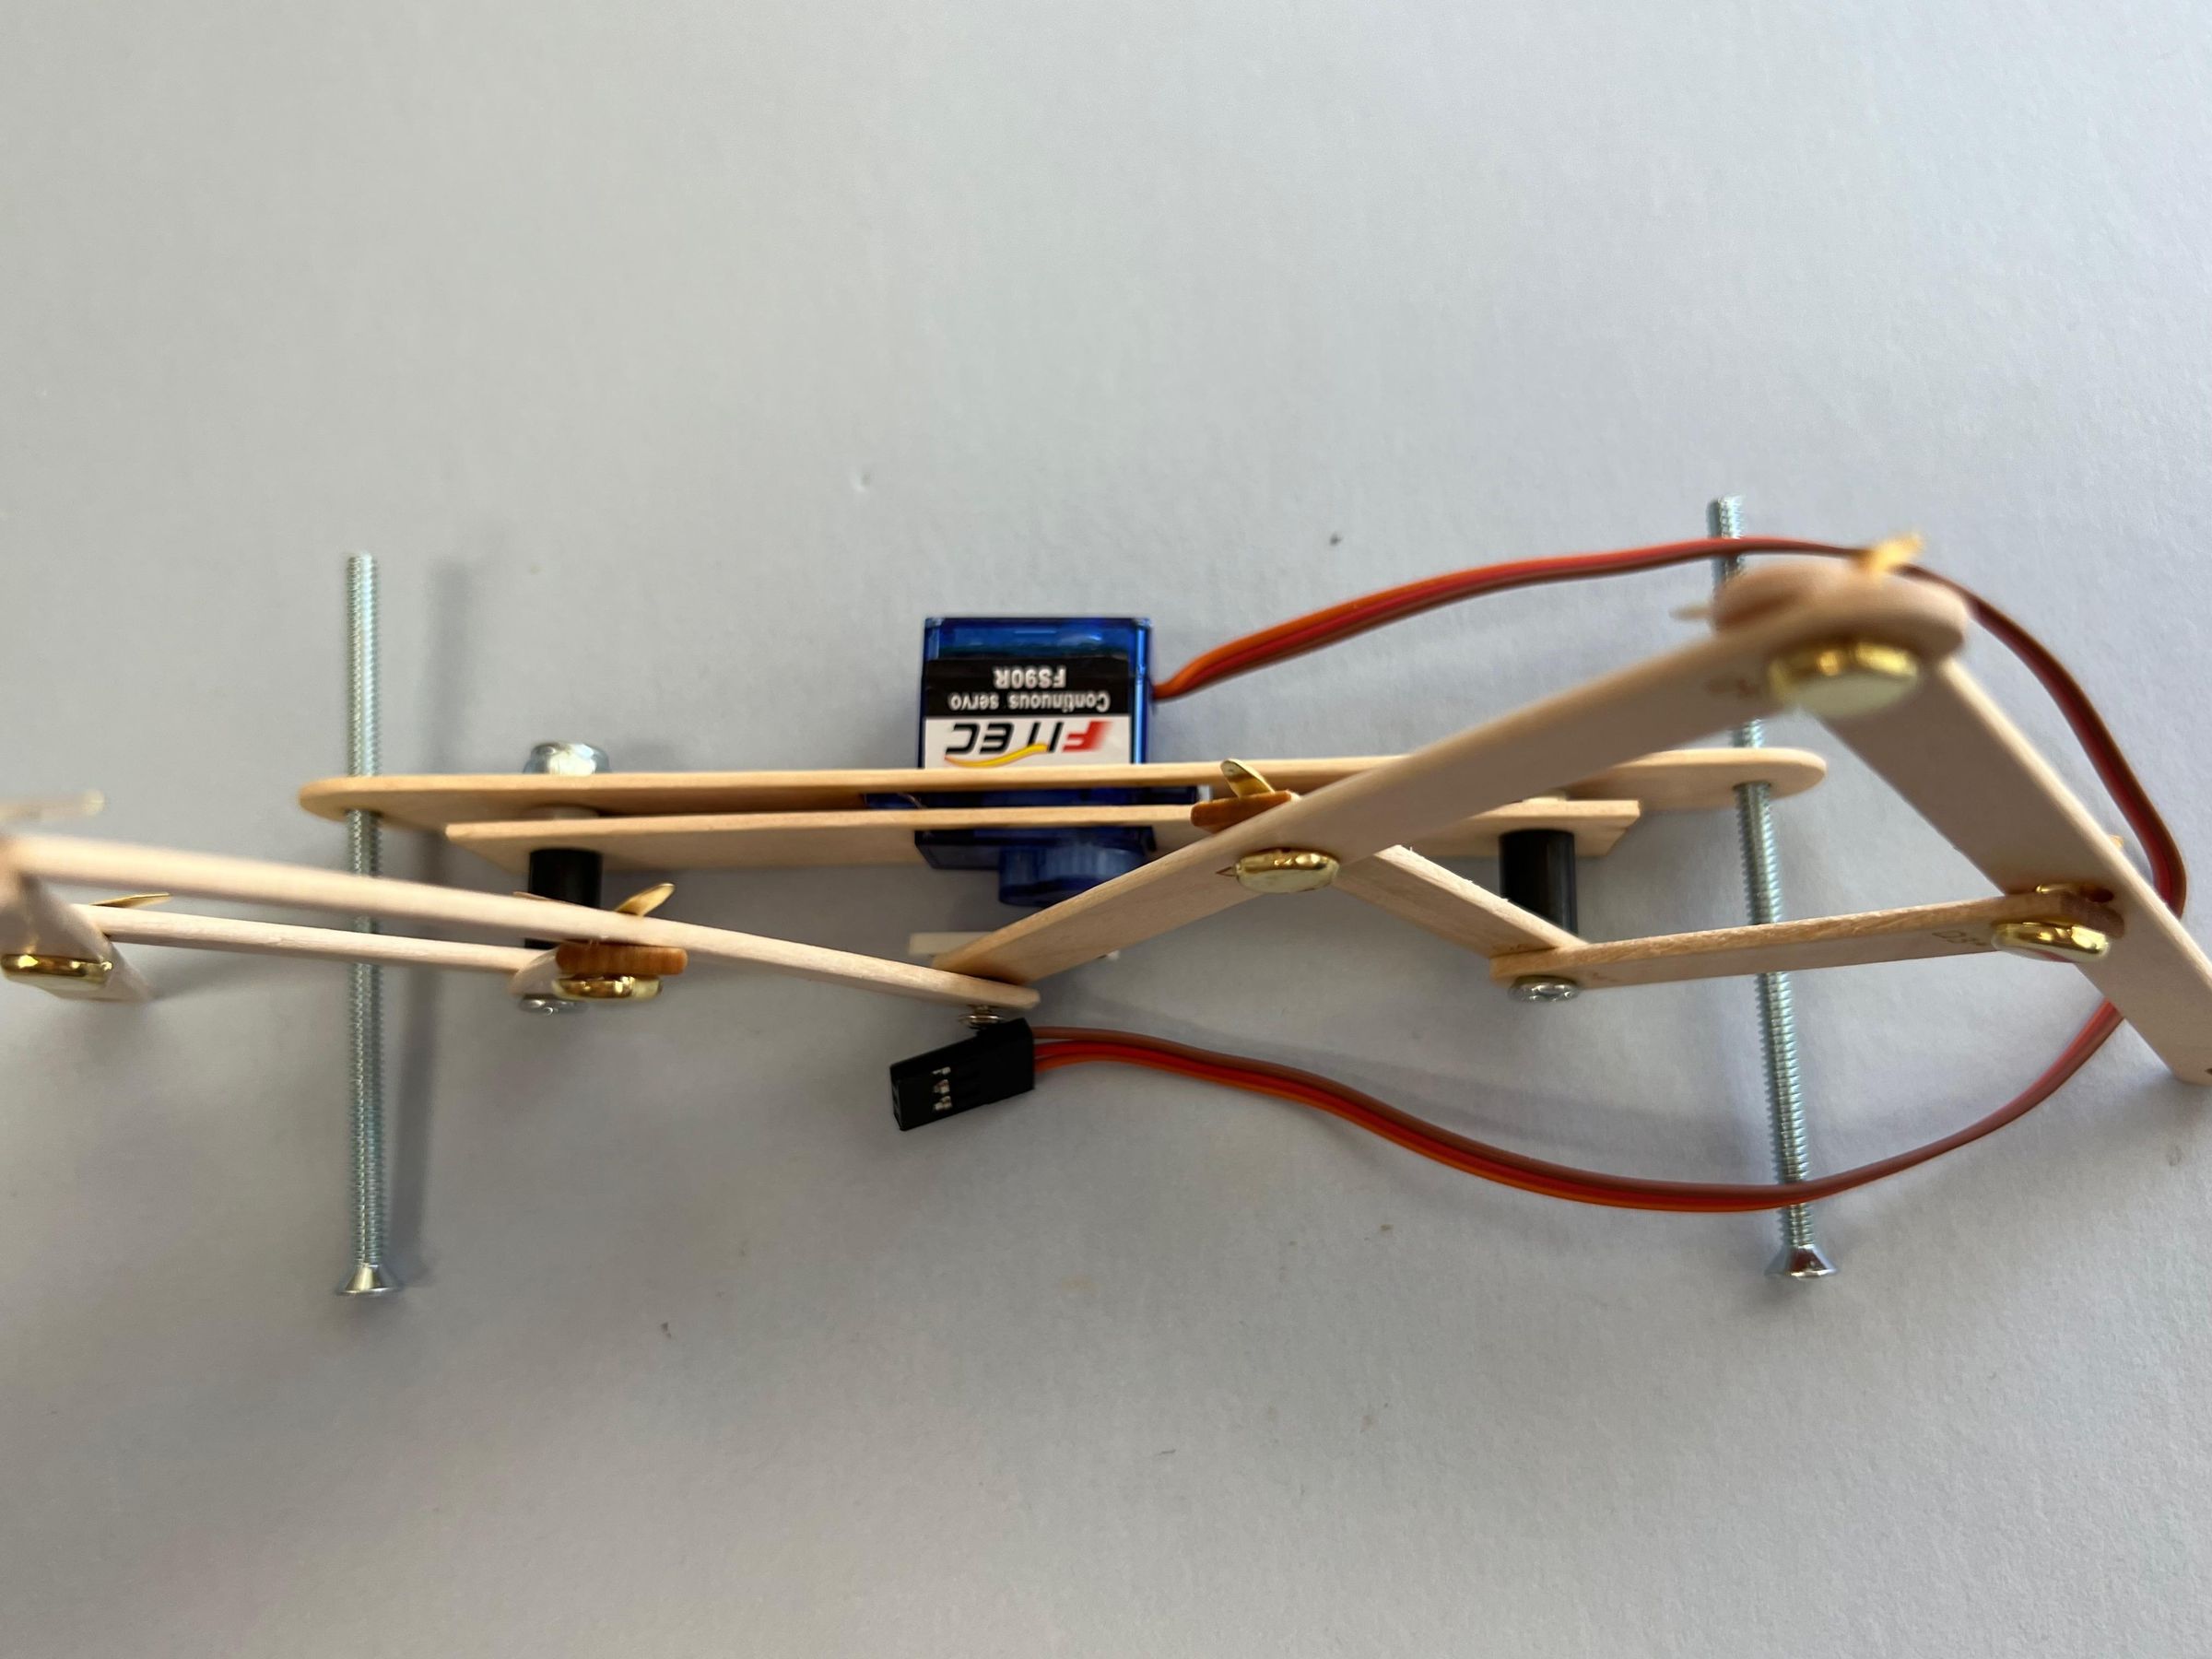
Stand the assemblies up, with the servo backs facing each other. Insert a 3" machine screw into the ends of one of the assemblies (use either the A-B assembly OR the C-D assembly, but not both).
Add Spacers
.jpeg)
Add one long spacer to each of the 3" screws.
Add Notched Sticks

Slide two notched sticks onto the 3" screws. The notches should be on the same side as the wire from the servo motor. The notches face up. Then slide two more spacers up to the notched sticks.
Second Pair of Notched Sticks
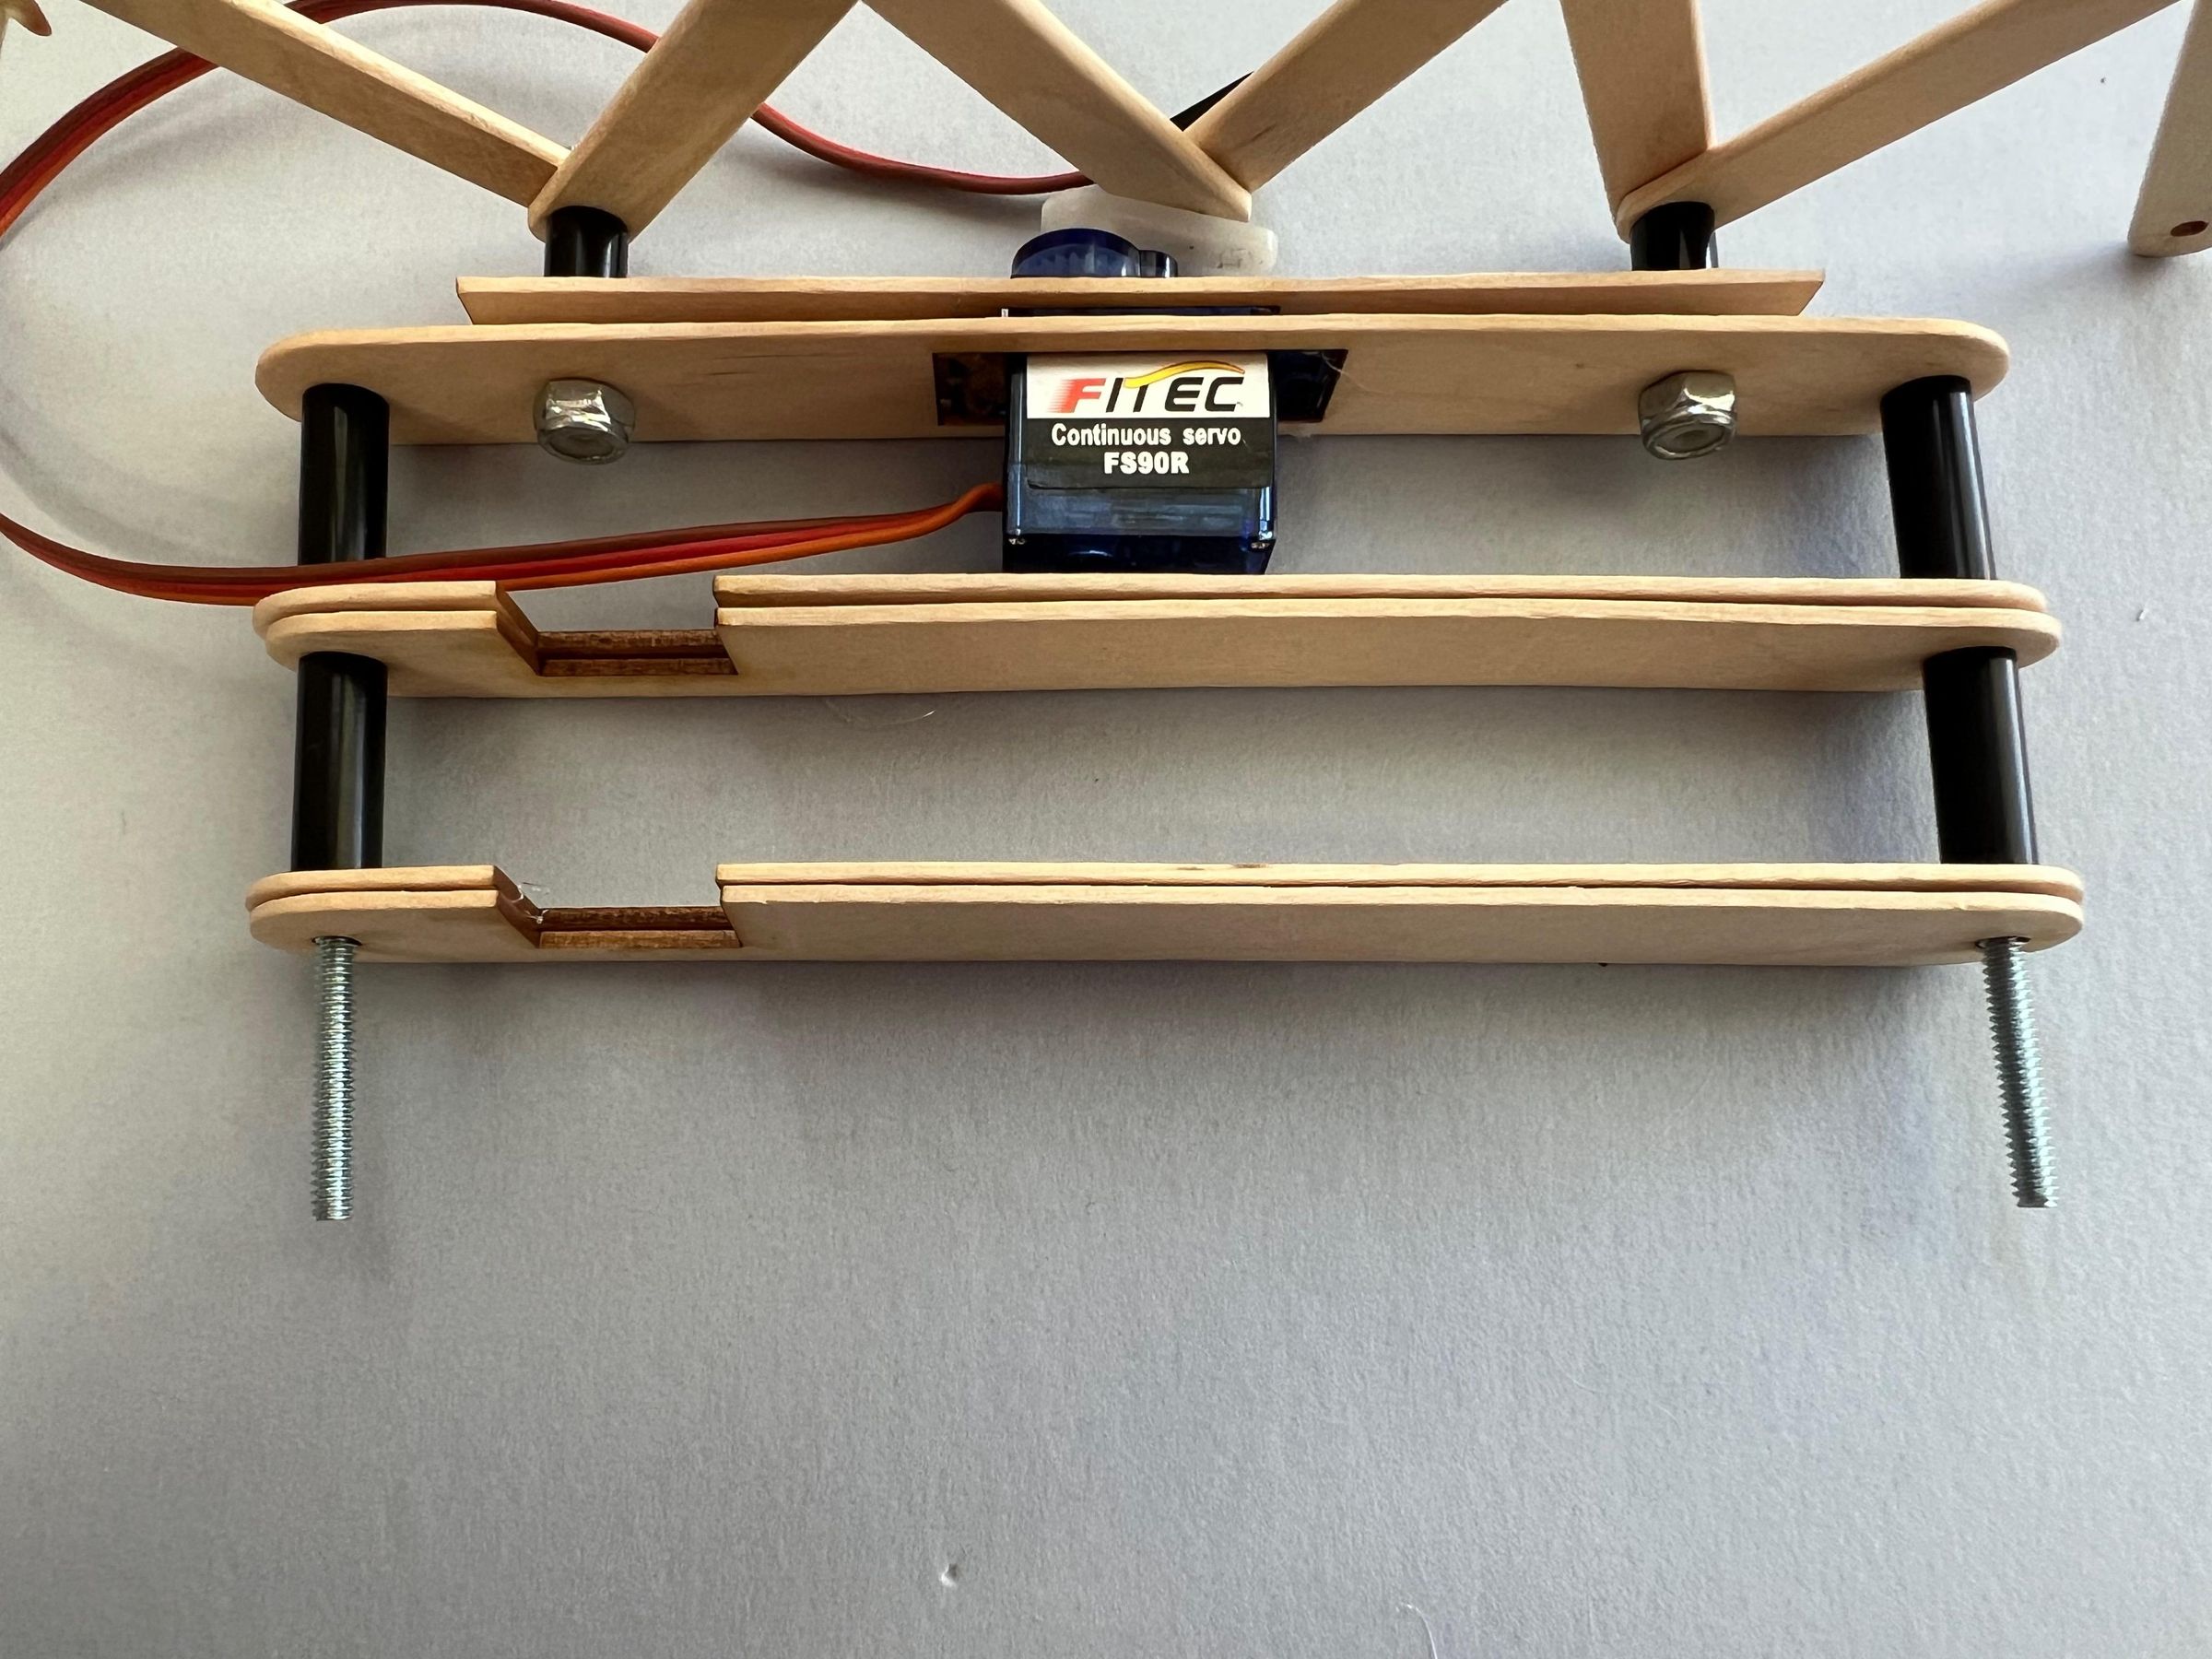
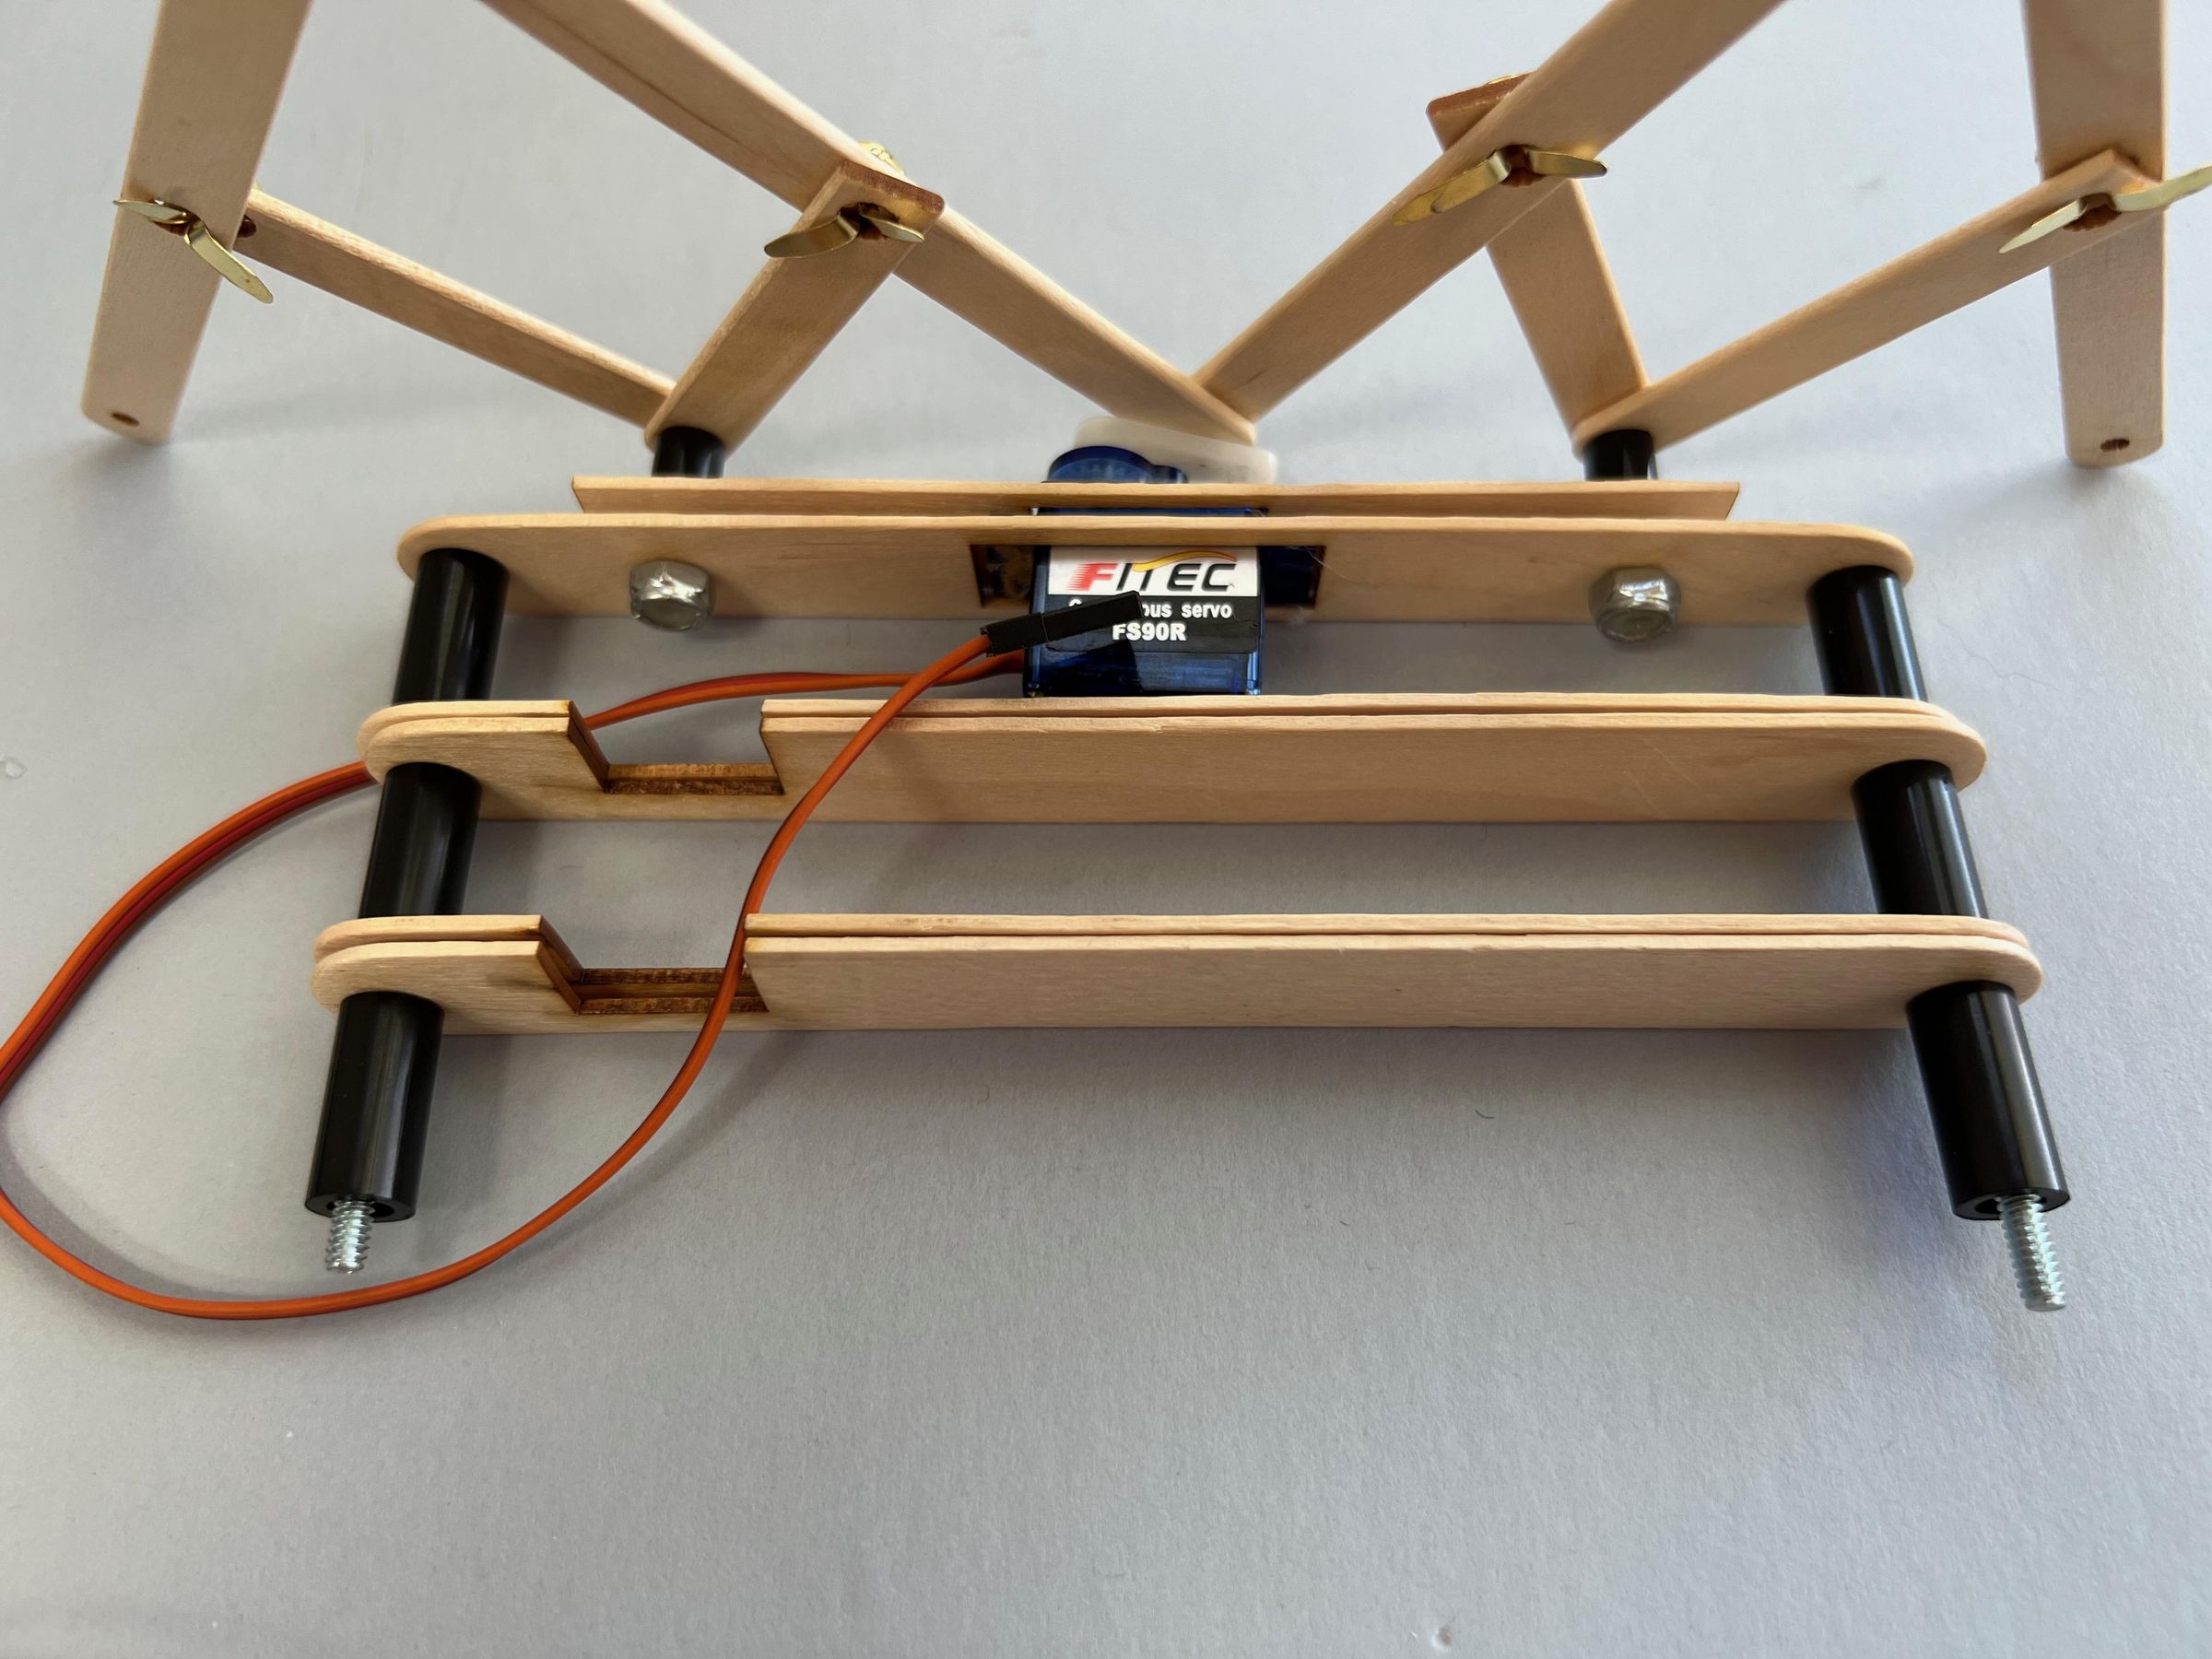
Add the second pair of notched sticks in the same orientation as the others. Then add the final pair of long spacers.
Attach the Other Leg Assembly

Slide the second leg assembly onto the end and use 6-32 nuts to secure it into place.
Attach the Servos
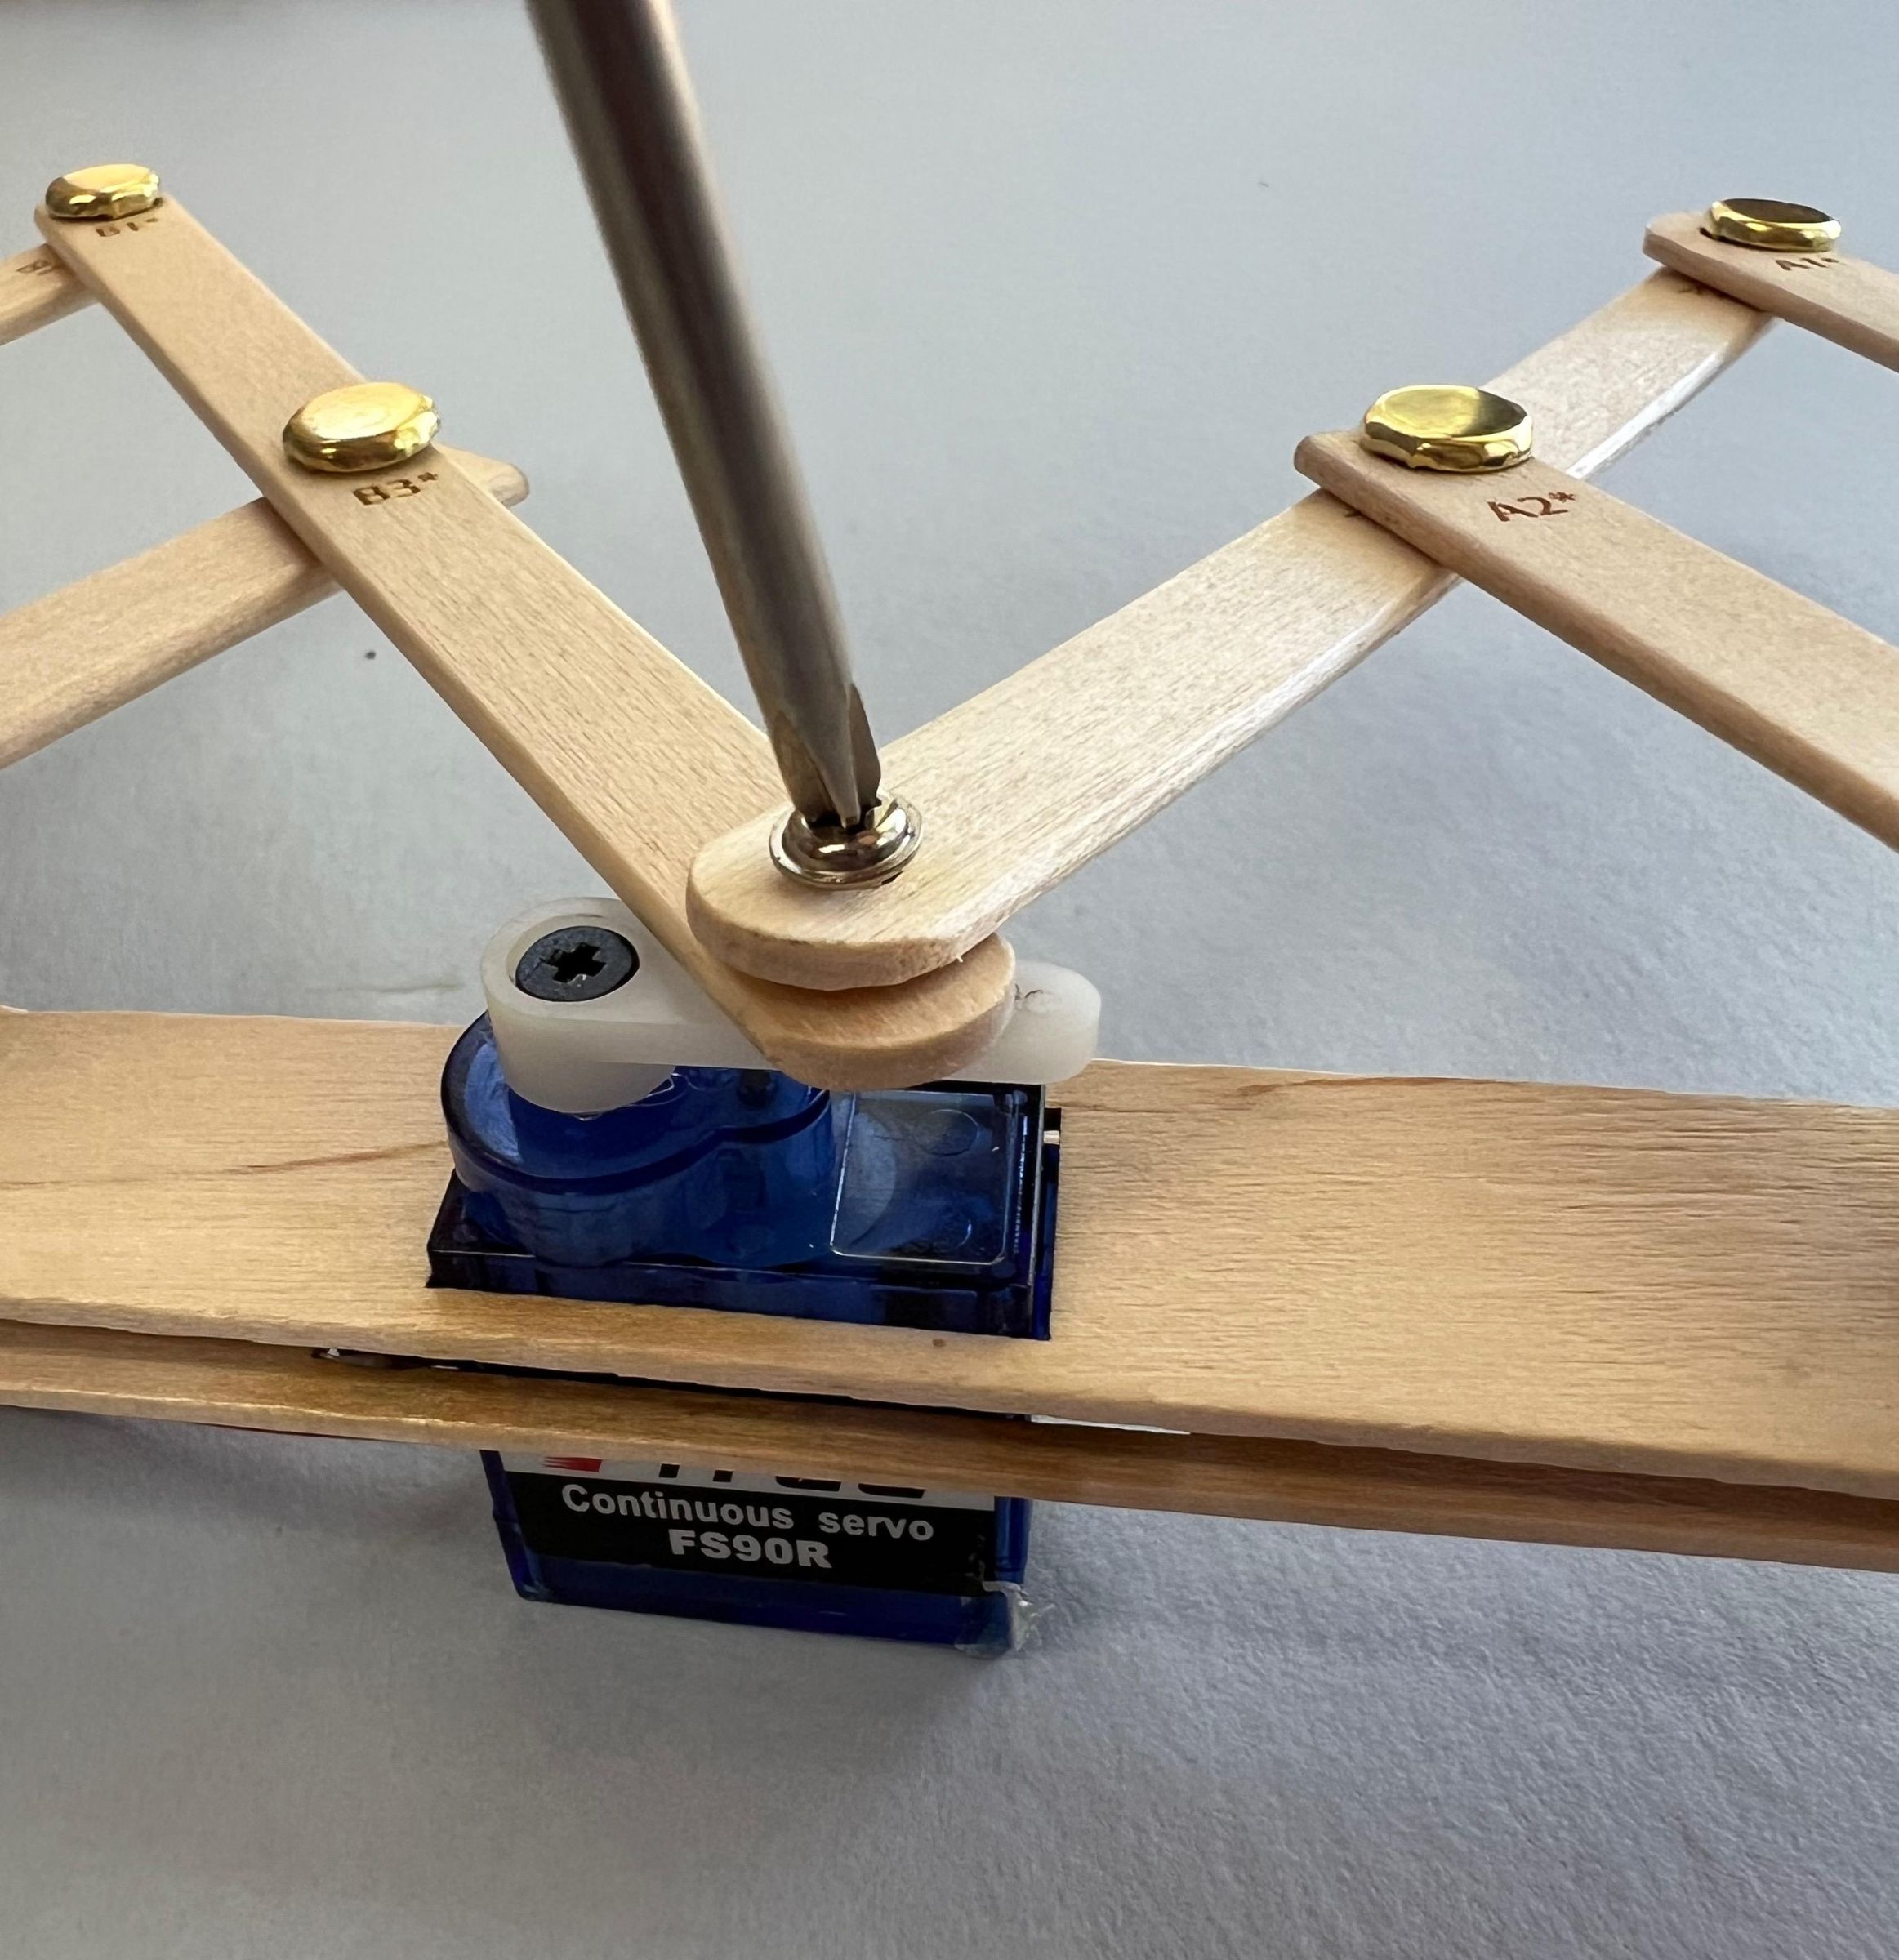
Attach the leg assemblies to the servo horn on each side. Use the pointy screw that came with the servo horns.
Attach the Micro:bit

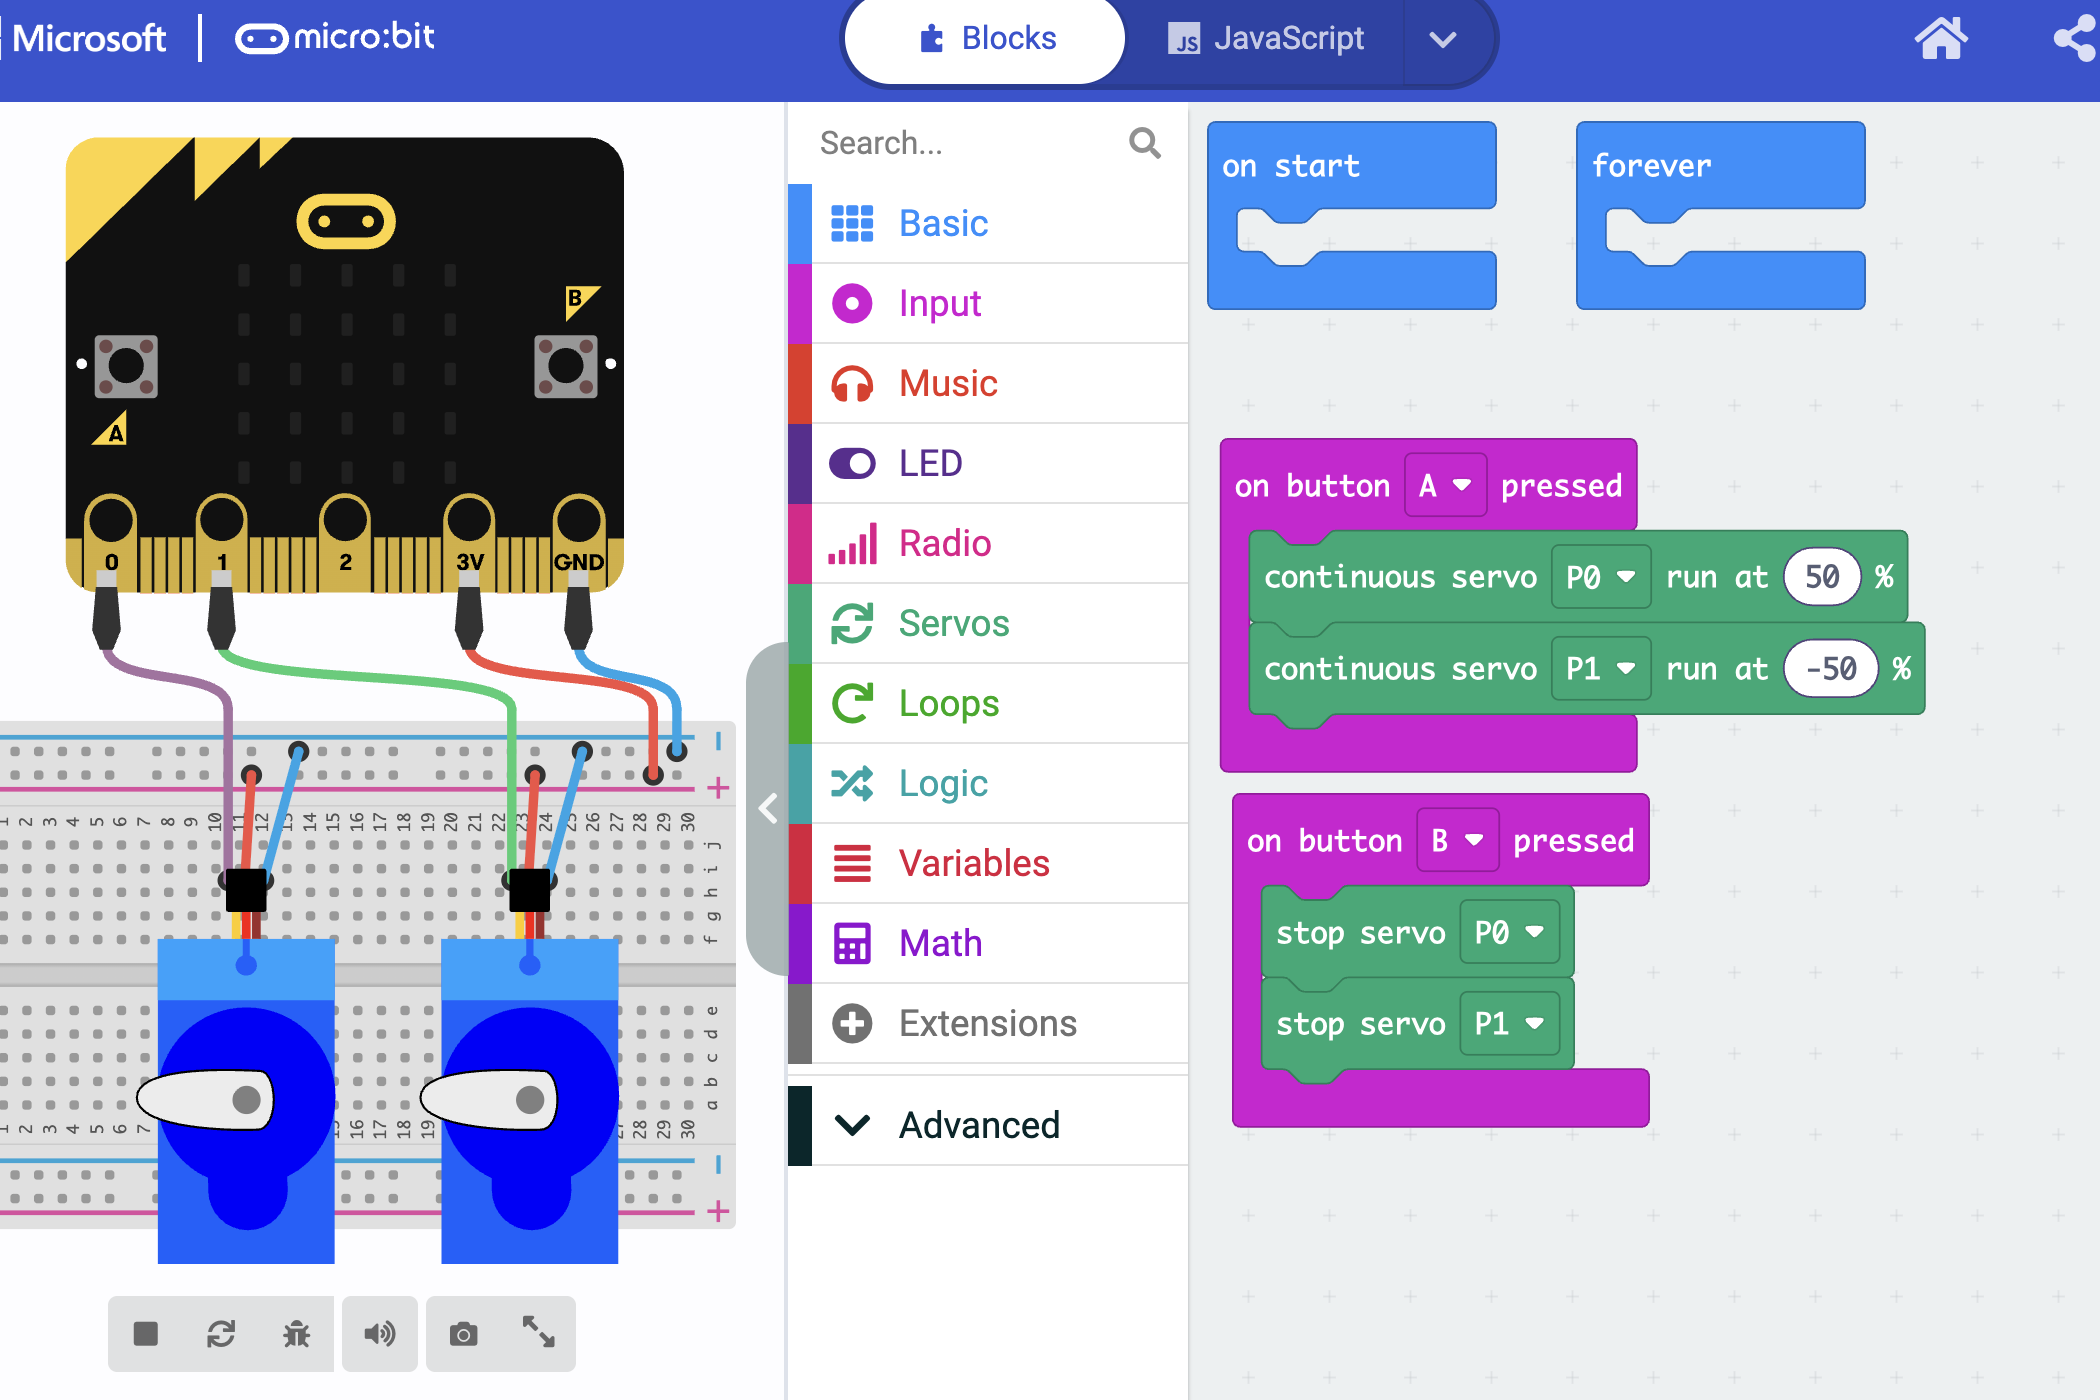
Attach the servos to the micro:bit and breakout boards. A 9V battery can sit in the notches in the middle of the frame.
We use MakeCode to program the micro:bit. When we push Button A, one servo runs in one direction and the other servo runs in the opposite direction. Button B turns the servos off. Our very introductory Instructable for working with MakeCode and micro:bit is here.
Make It Bug-Like
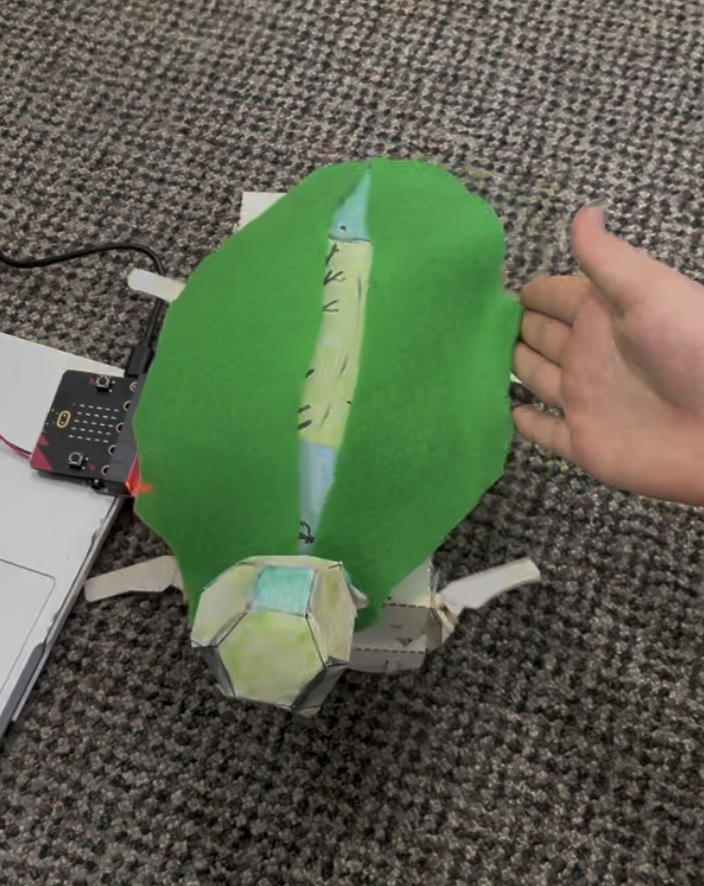

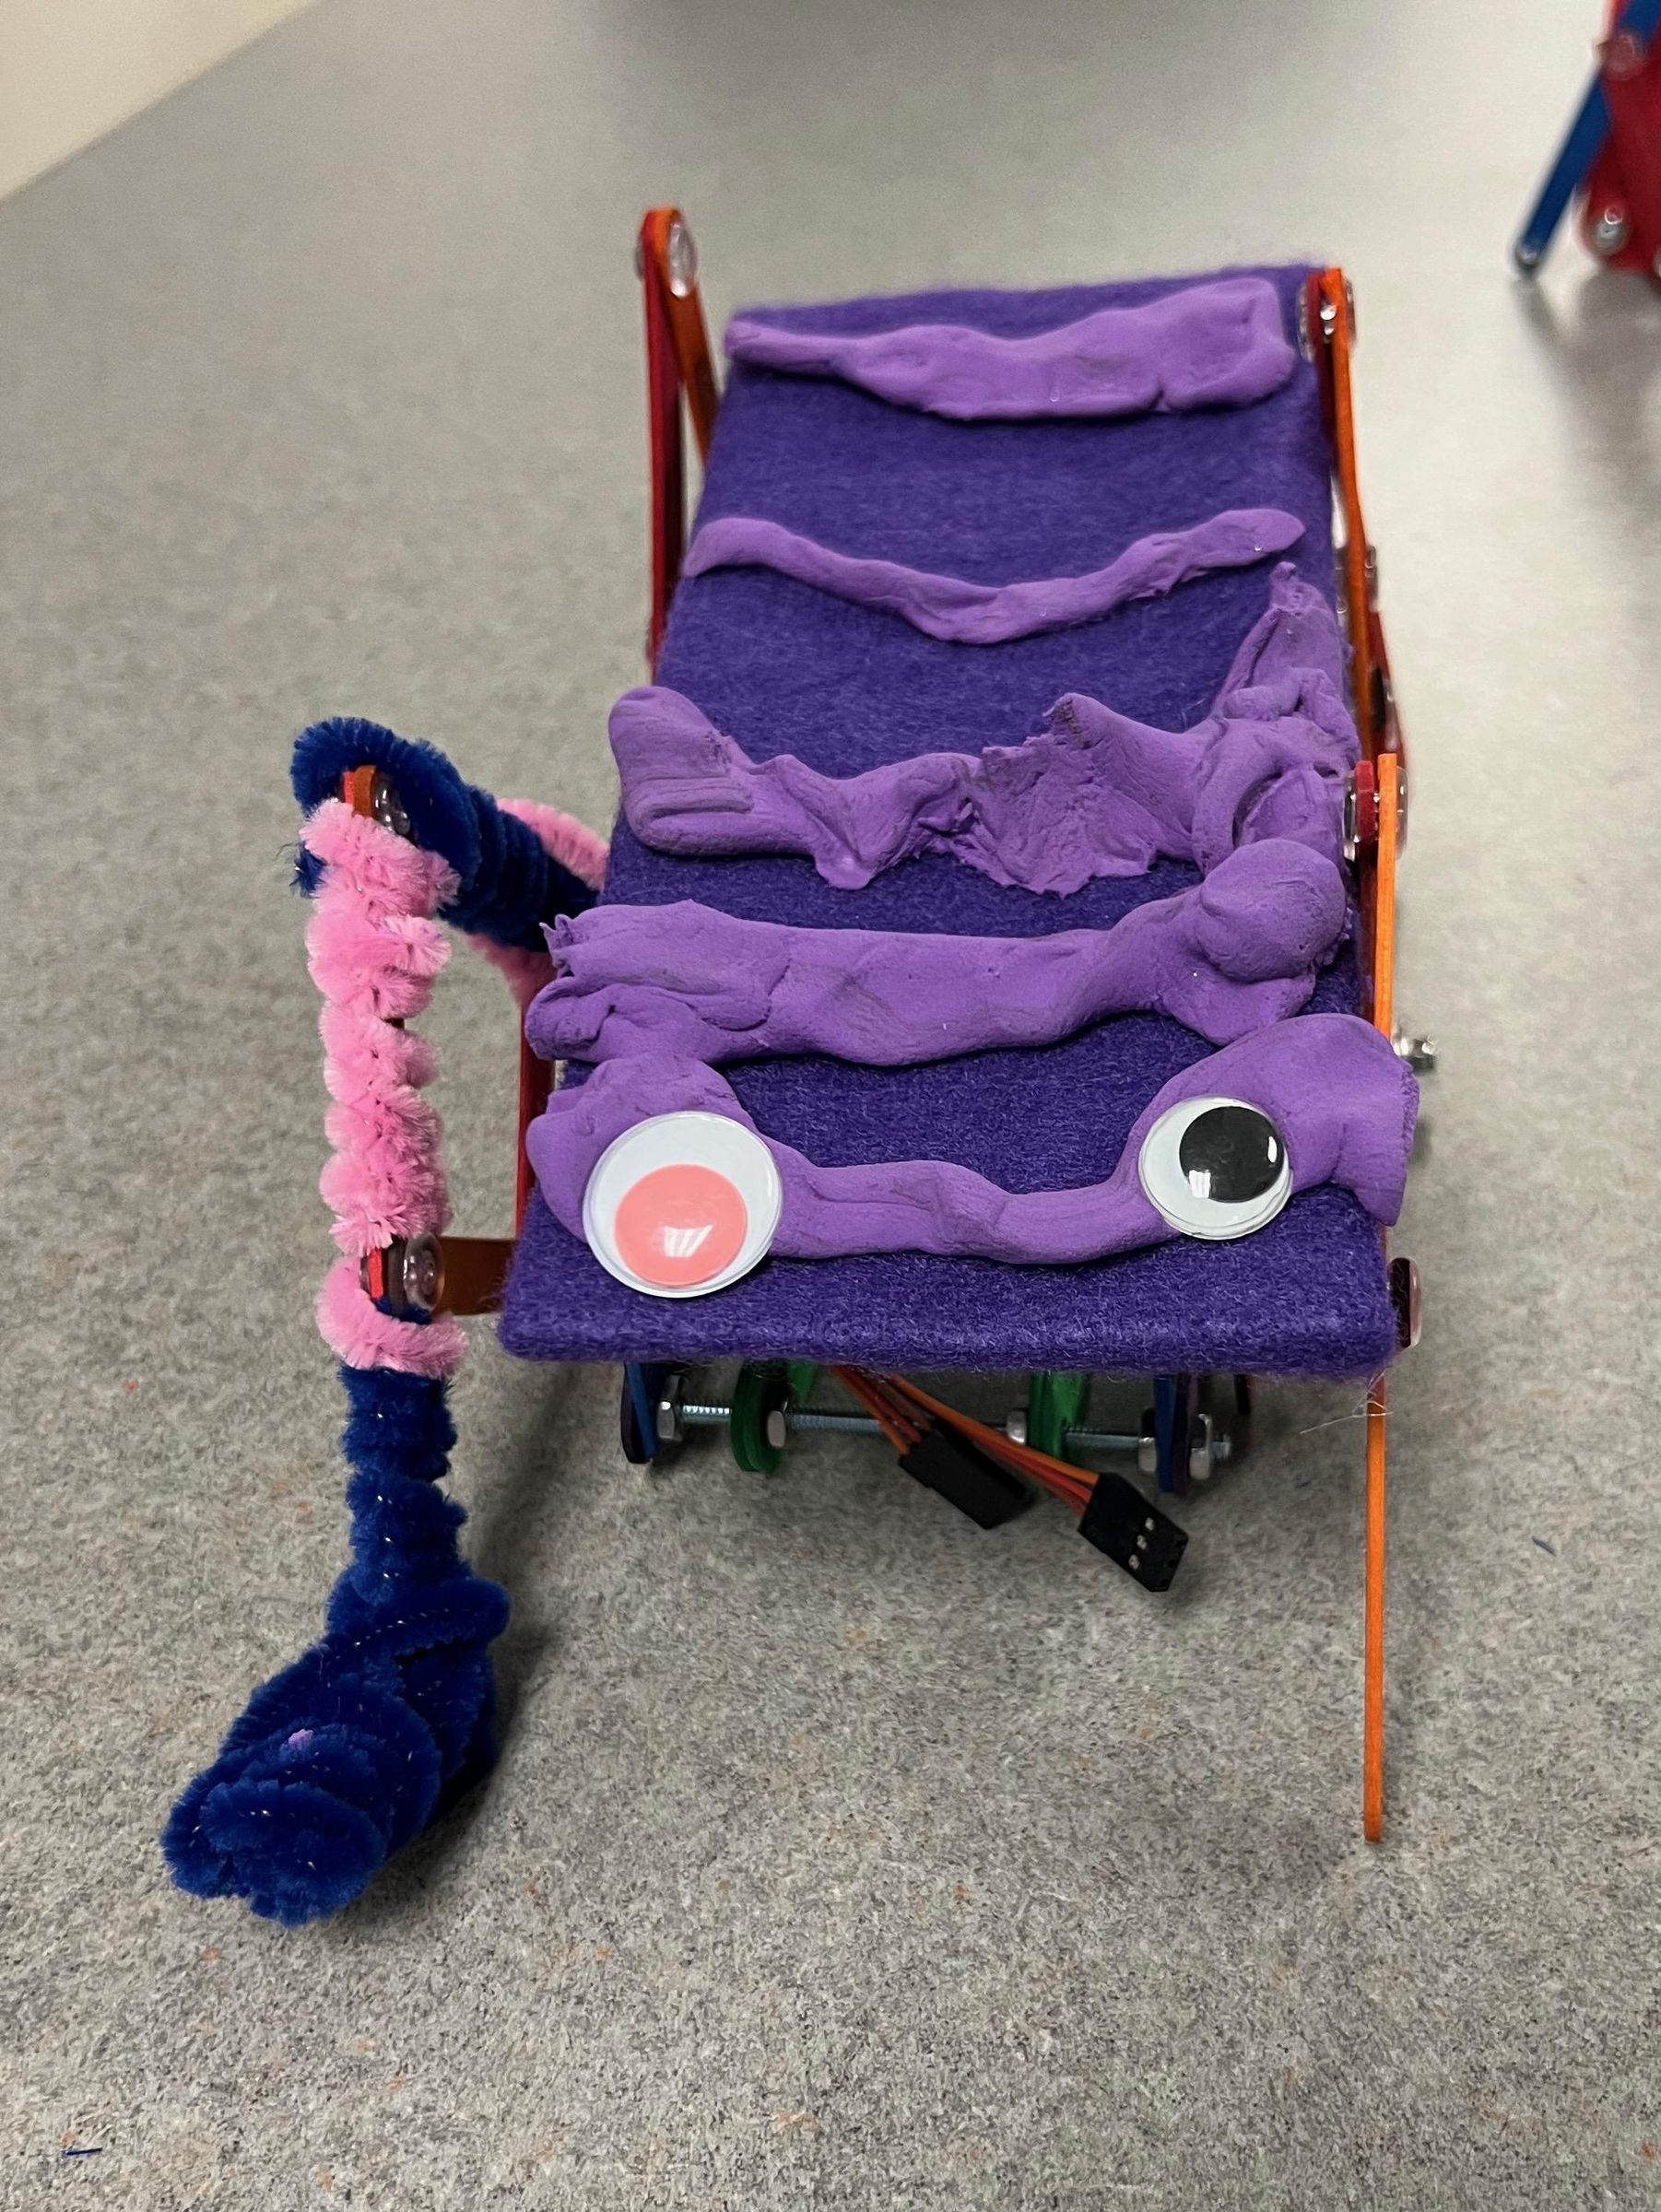
- Here are some paper craft files for making geometric heads and bodies.
- Our elementary school maker-testers enjoyed using model magic, pipe cleaners, and googly eyes to personalize their projects.
- They found that adding Sculpey/modeling clay to the feet helped with traction.
Downloads
Acknowledgements

This project was made possible through a generous pilot grant from the University of Colorado's Institute of Cognitive Science. PI: Srinjita Bhaduri/Co-PI: Ann Eisenberg.
The bug design was a Discovery Learning Apprenticeship project by Zach Majeski, drawing upon earlier work by Kaushik Jayaram (Insect Inspired Intelligence Lab, Imperial College London/Animal Inspired Movement and Robotics Lab, CU Boulder). Related references include "How to Make a Spider Robot" and "How to make an animal walking robot" on YouTube.
We would especially like to thank our intrepid kid maker-testers (grades 3-5) at Bixby School, Boulder; CU's Science Discovery Program; and STEM Launch K-8 in Thornton, CO.