Motor Thrust and Efficiency Test Stand
by yotitote in Workshop > 3D Printing
28 Views, 0 Favorites, 0 Comments
Motor Thrust and Efficiency Test Stand
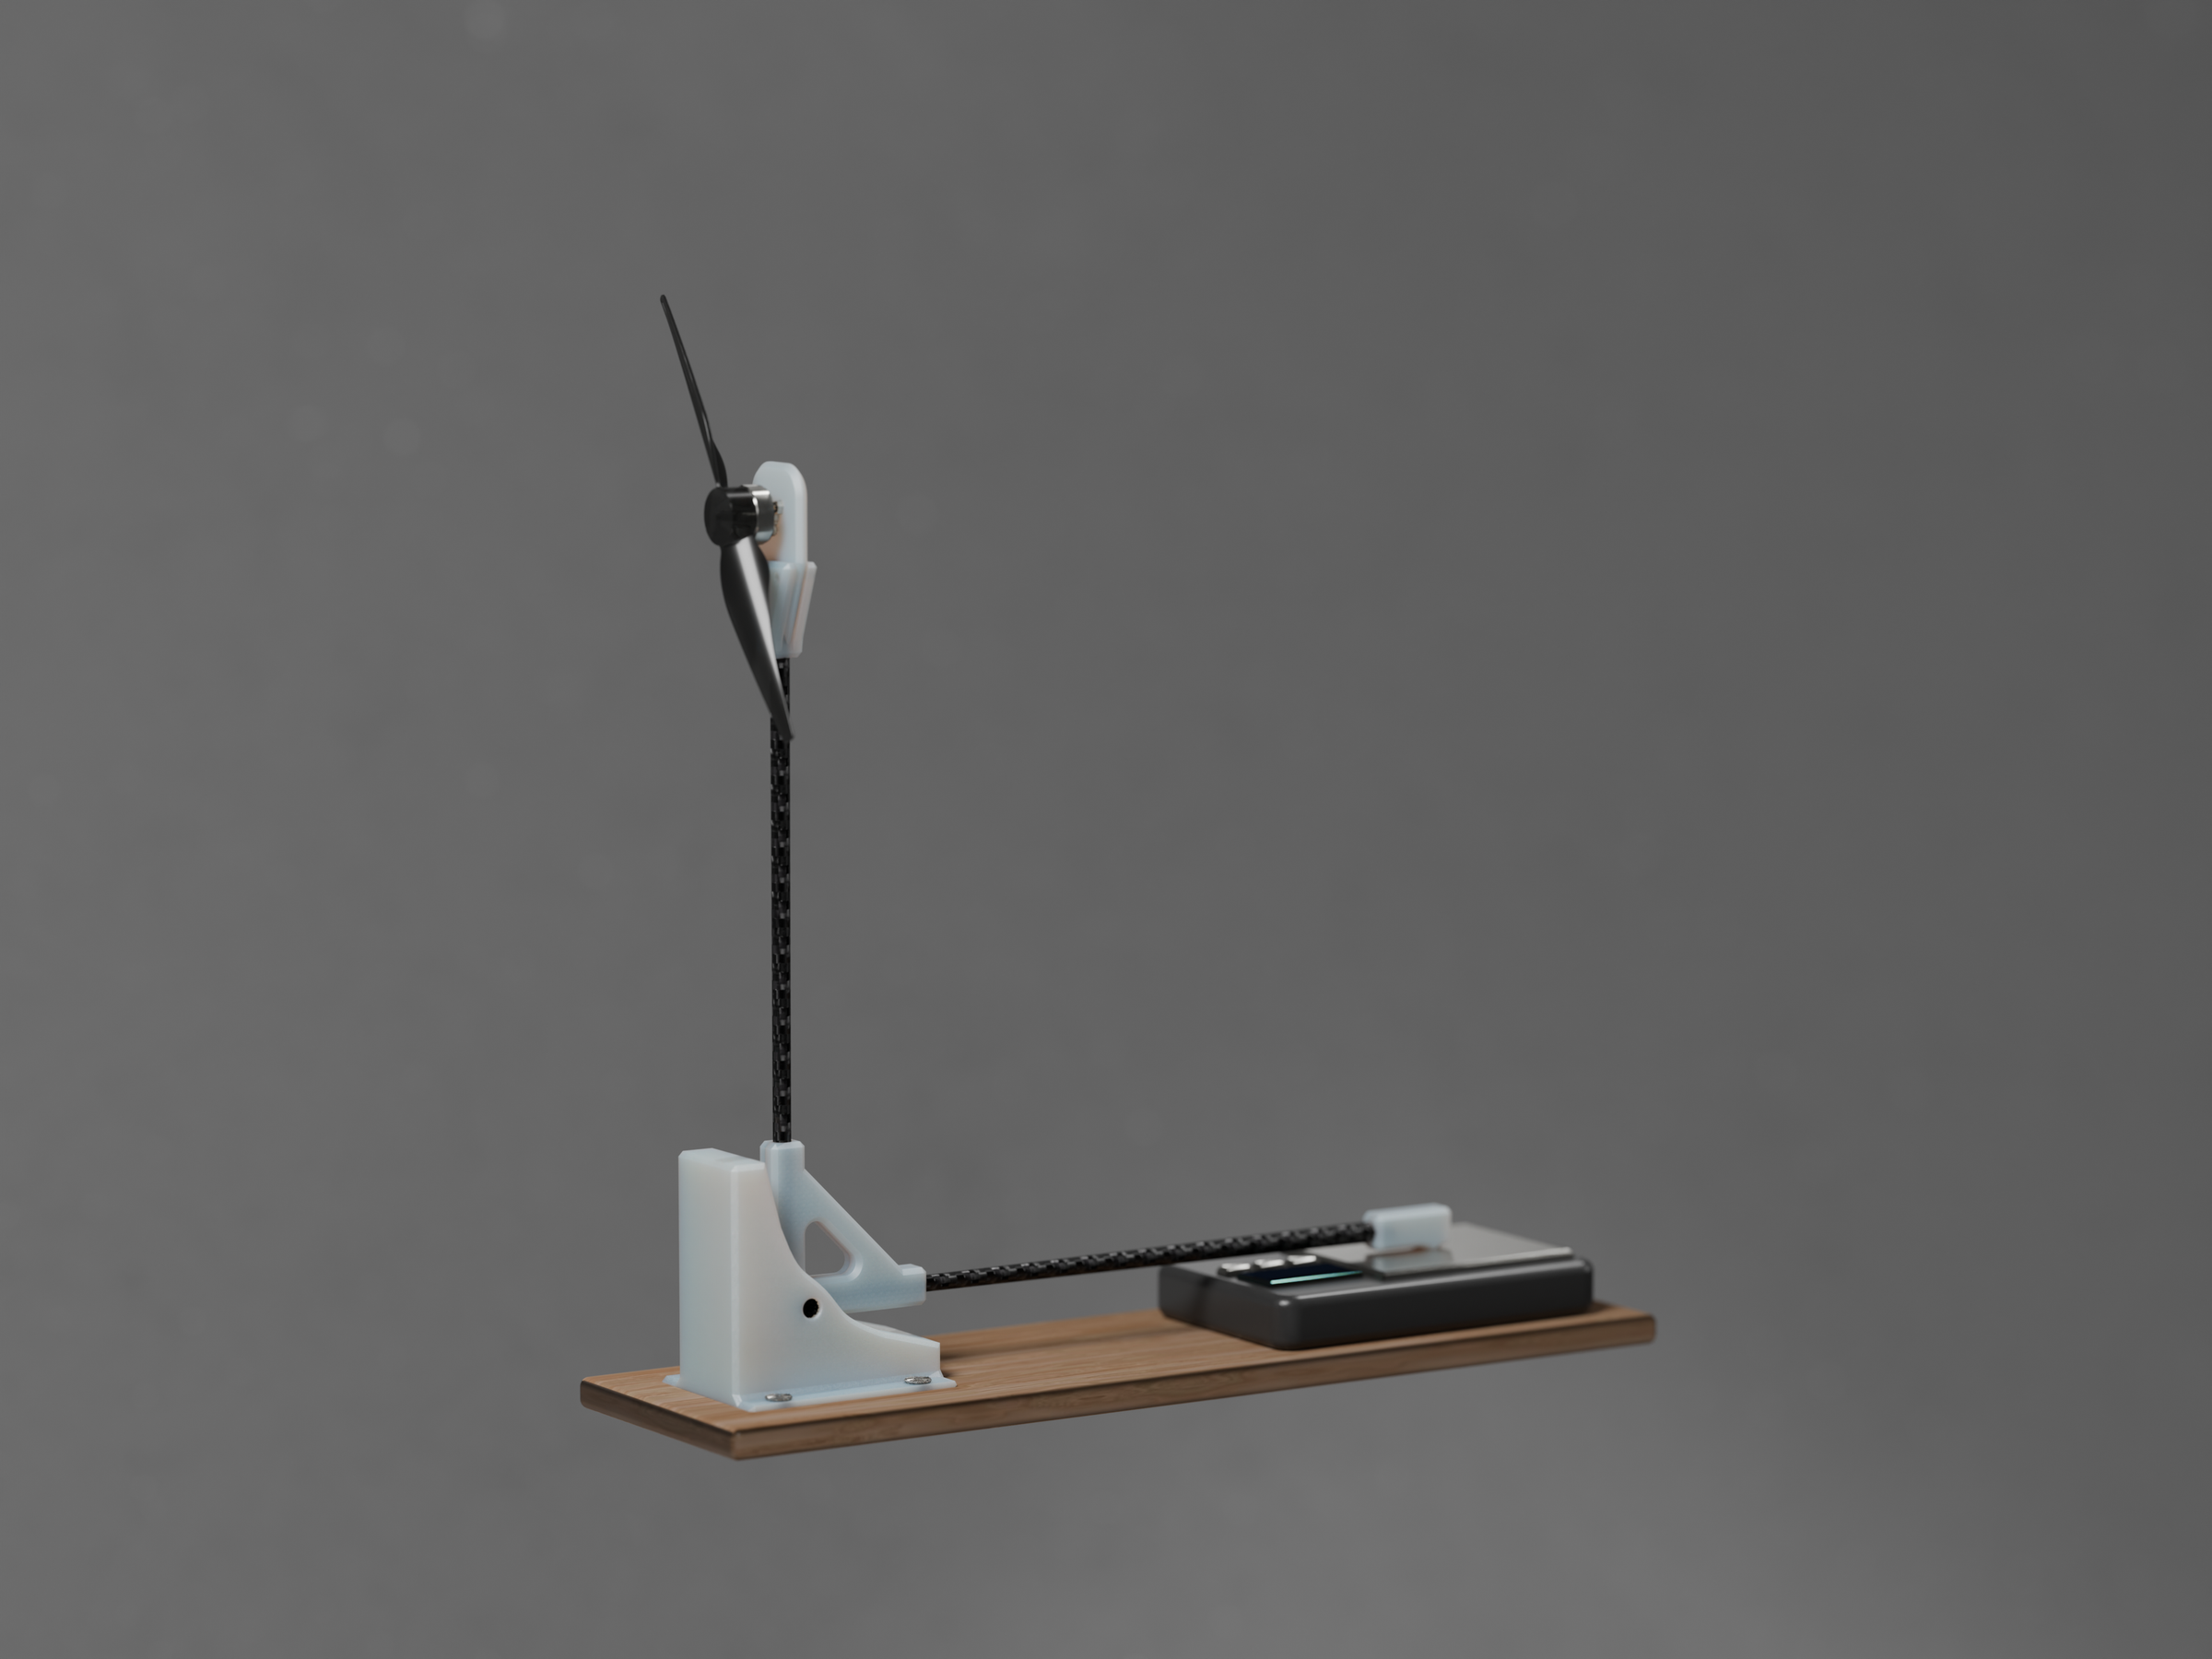
For one of my projects, I needed a simple and reliable way to measure how much power a drone motor used at a specific thrust level. To do this, I designed a lightweight thrust testing stand that uses a normal electronic scale to measure force, with two carbon-fibre arms holding the motor at the required height. The goal was to keep the setup simple, inexpensive, and easy to reproduce while still giving consistent results for comparing different motors and propellers.
Supplies
Tools:
- 3D printer
- Electronic scale
- Hacksaw / fine-tooth metal saw
- Sandpaper
- X-Acto / hobby knife
- Digital caliper or ruler
- Drill / screwdriver
- Small clamps (optional, useful while the CA glue cures)
- Dust mask or respirator
- Safety glasses
Supplies:
- 50 cm of 6 mm carbon-fibre tube/rod
- PLA filament
- Thick CA glue
- M3 × 10 mm screws
- Plywood base, approximately 10 × 40 cm
- Small amount of grease or lubricant for the hinge
- Optional CA accelerator
- Paper towels / water for wet cutting and sanding
Designing


Design:
The stand is based on a simple lever system rotating around a central hinge. One arm holds the motor vertically, while the second arm transfers the force onto the electronic scale.
The important part of the design is that the motor thrust point and the point where the lower arm presses on the scale are positioned at the same distance from the hinge. In other words, both points lie on the same circular path around the pivot. Because the lever arms are equal, the torque produced by the motor is balanced by the force acting on the scale.
This means that, as long as the forces act in the intended directions, the force measured by the scale is approximately equal to the thrust produced by the motor. Using equal-length arms also removes the need for any extra conversion factor between the scale reading and the motor thrust, which keeps the system simple and makes the measurements easier to interpret.
The long carbon-fibre arms were used to keep the motor far enough away from the base and the scale so that the propeller has plenty of clearance. The carbon tubes also provide good stiffness while keeping the moving part of the stand relatively light.
Static Stress Simulation


Thrust Stand Strength Analysis:
To get an idea of how much thrust the stand could safely handle, I ran static stress simulations at 5 N, 6 N and 10 N. I mainly looked at the maximum displacement, Von Mises stress and minimum safety factor to see how the structure behaved as the load increased.
At 5 N, the stand had a maximum displacement of about 3.86 mm and a maximum Von Mises stress of around 61.8 MPa. The minimum safety factor was 3.80, so there was still a good amount of structural margin at this load.
At 6 N, the maximum displacement increased to about 4.64 mm, while the maximum stress reached around 74.1 MPa. The minimum safety factor dropped to 3.16, which is still a reasonable value and suggests that this load should be well within the usable range of the stand.
I also tested a much higher load of 10 N. In this case, the maximum displacement increased to around 7.73 mm and the maximum Von Mises stress reached about 123.6 MPa. The minimum safety factor dropped to 1.90. This suggests that the stand could still survive this load according to the simulation, but the deformation is already quite large and the safety margin is much smaller, so I would treat 10 N as more of an extreme test rather than a normal operating condition.
The results also scaled quite consistently with the applied force, which is what I would expect from a linear static simulation. Based on these results, 5–6 N looks like a comfortable working range, while 10 N is much closer to the practical limit of the design.
It is worth keeping in mind that this is still only a simplified simulation. The real 3D-printed parts, layer orientation, carbon-fibre tubes and CA glue joints may behave differently from the material models and bonded contacts used in Fusion, so the actual strength and stiffness of the stand could be somewhat different from the simulated values.
3D Printing

The parts can be printed from most common filaments available on the market. I used PLA because I already had it on hand and it is one of the easiest materials to print reliably. For this application, it also provided enough stiffness without making the printing process unnecessarily complicated.
If you are not printing directly from the provided 3MF file, these are the settings I used:
Print settings:
- Nozzle diameter: 0.4 mm
- Layer height: 0.20 mm
- Wall lines: 3
- Top/Bottom layers: 3
- Infill: 20%
- Supports: Off
The rest of the settings can be left close to a normal PLA preset, so there is no need for anything unusual. If you want to experiment with stronger materials, nylon or carbon-fibre-reinforced filament could also be good options and may provide additional strength and rigidity. Keep in mind that carbon-filled filaments are abrasive, so a hardened nozzle is recommended.
I also included a STEP file with a basic motor-mount template. This can be modified if you want to test a different motor, making it easier to adapt the stand without redesigning the whole assembly from scratch.
Carbon Fiber Preparation

Carbon Tubes Preparation:
The carbon-fibre tubes need to be cut into three sections: two 220 mm pieces for the main arms and one 34 mm piece for the hinge.
The cutting process is the same as with most carbon-fibre parts. Use a fine-tooth handsaw, such as one designed for cutting metal, to get a clean edge without splintering the tube too much.
It is best to cut the tubes wet, as this helps prevent fine carbon dust from becoming airborne. Carbon-fibre dust can irritate the lungs and skin, so I would still recommend wearing a respirator or at least a good dust mask, especially if you are not working fully outdoors.
After cutting, lightly sand the ends to remove any rough edges or sharp fibres. This should also be done wet to keep dust to a minimum. Once the sanding is finished, rinse the tubes carefully with water to remove any remaining carbon particles from the surface and from inside the tubes.
Bottom Assembly


Bottom Assembly:
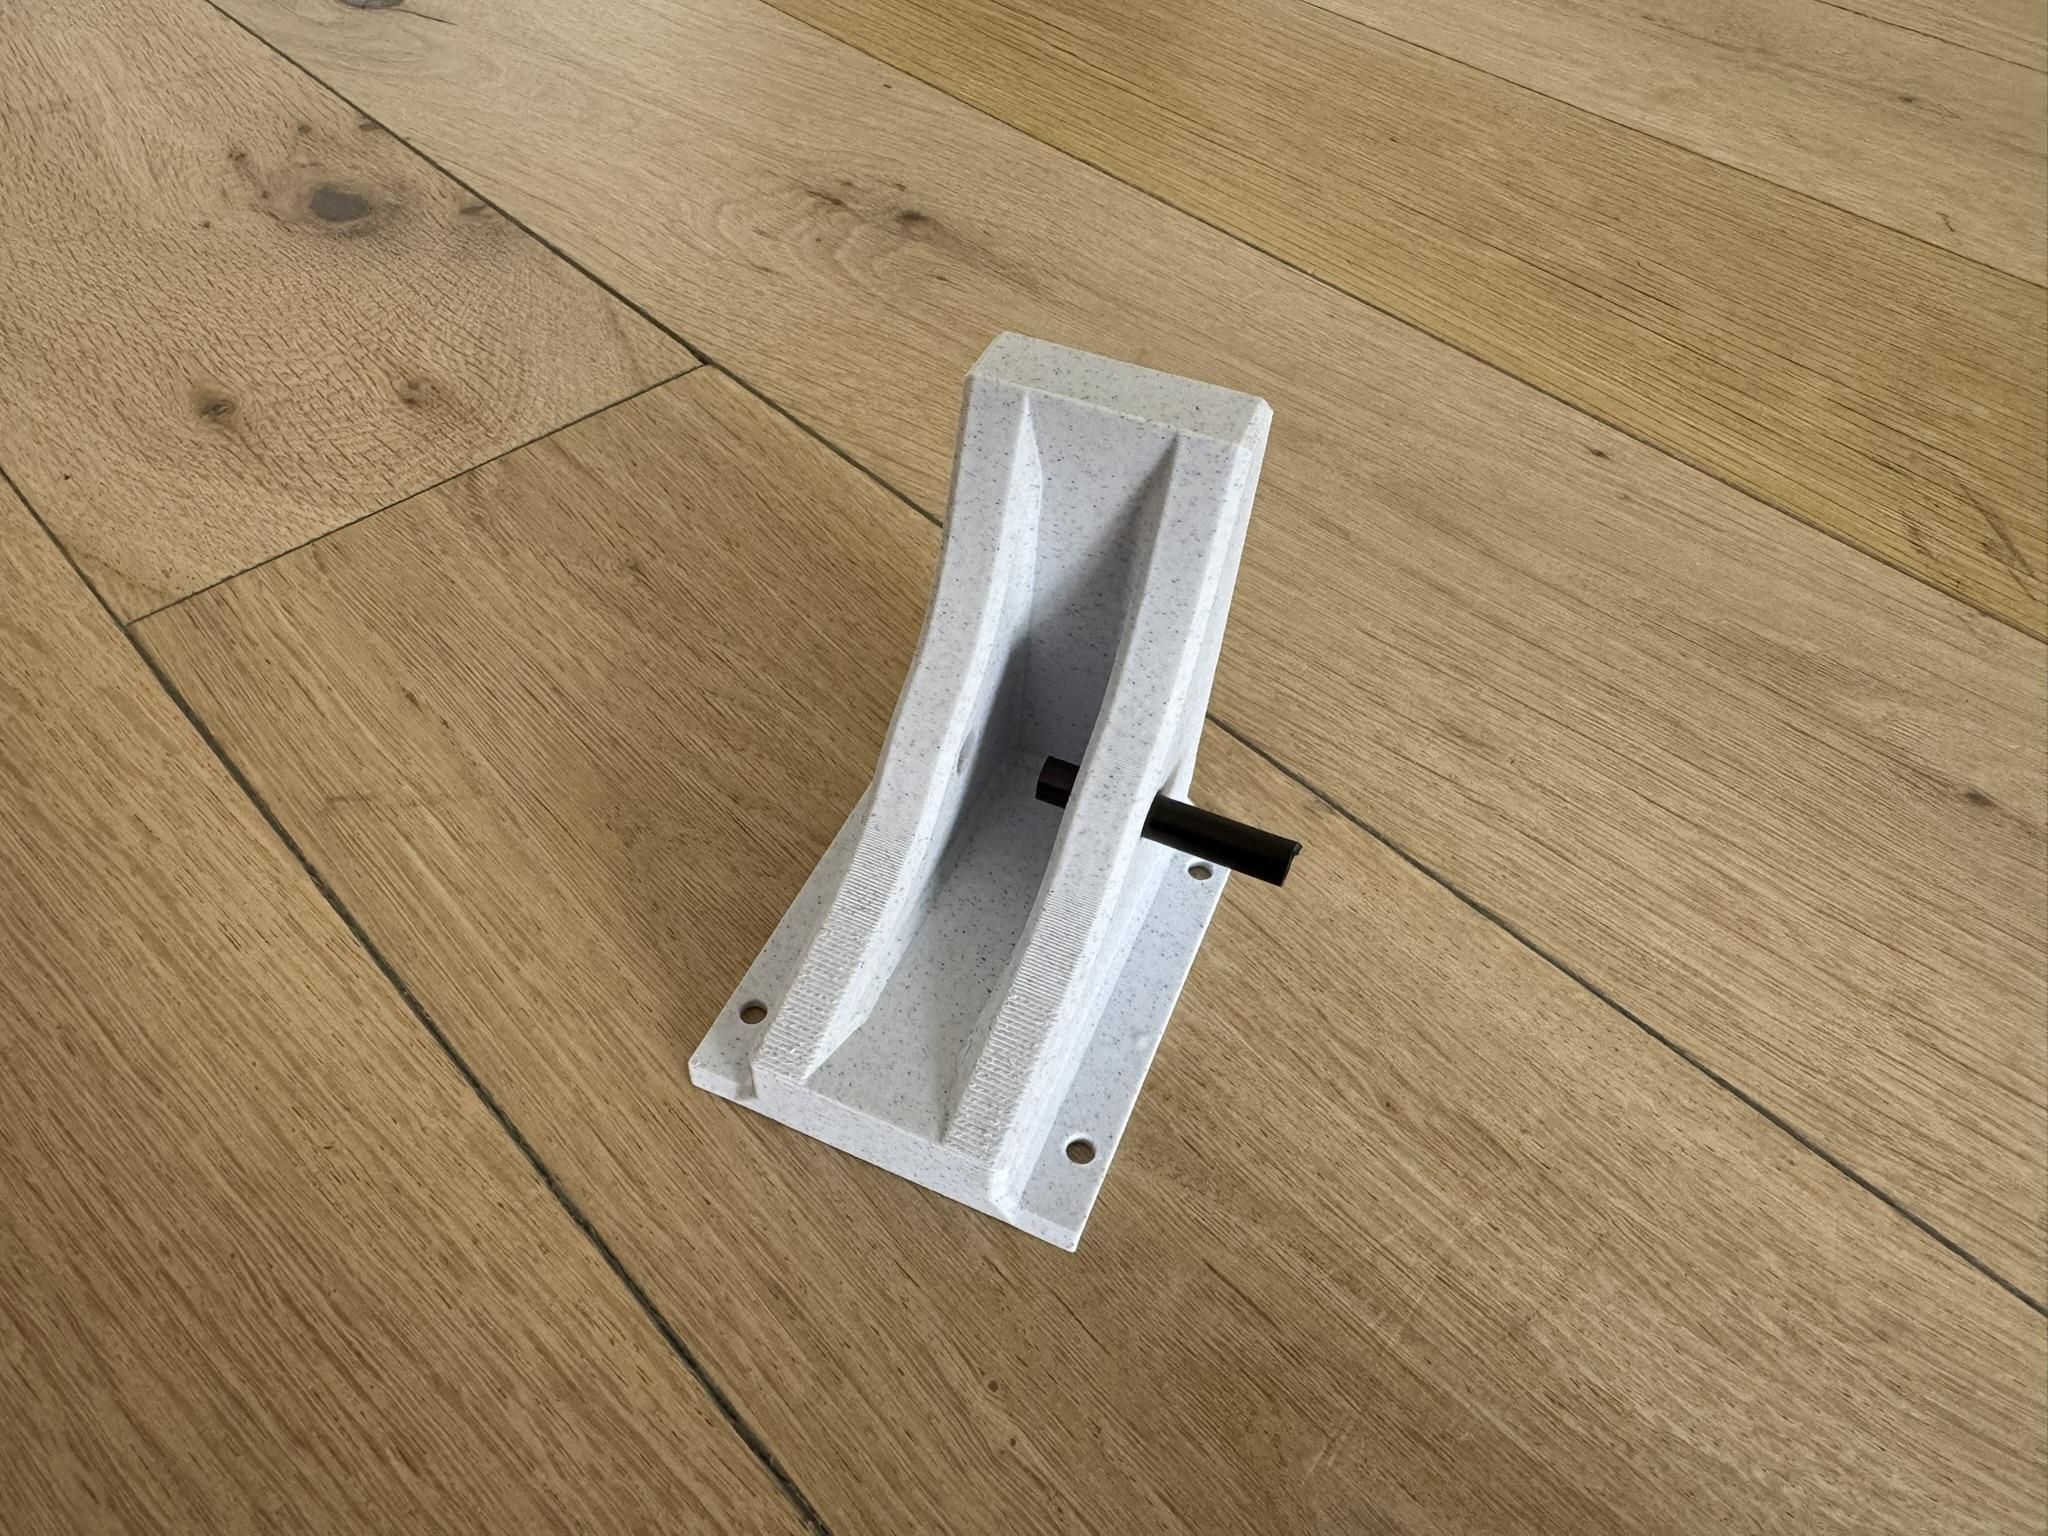
When all of the parts are printed and the carbon tubes are cut, the bottom section of the testing stand can be assembled.
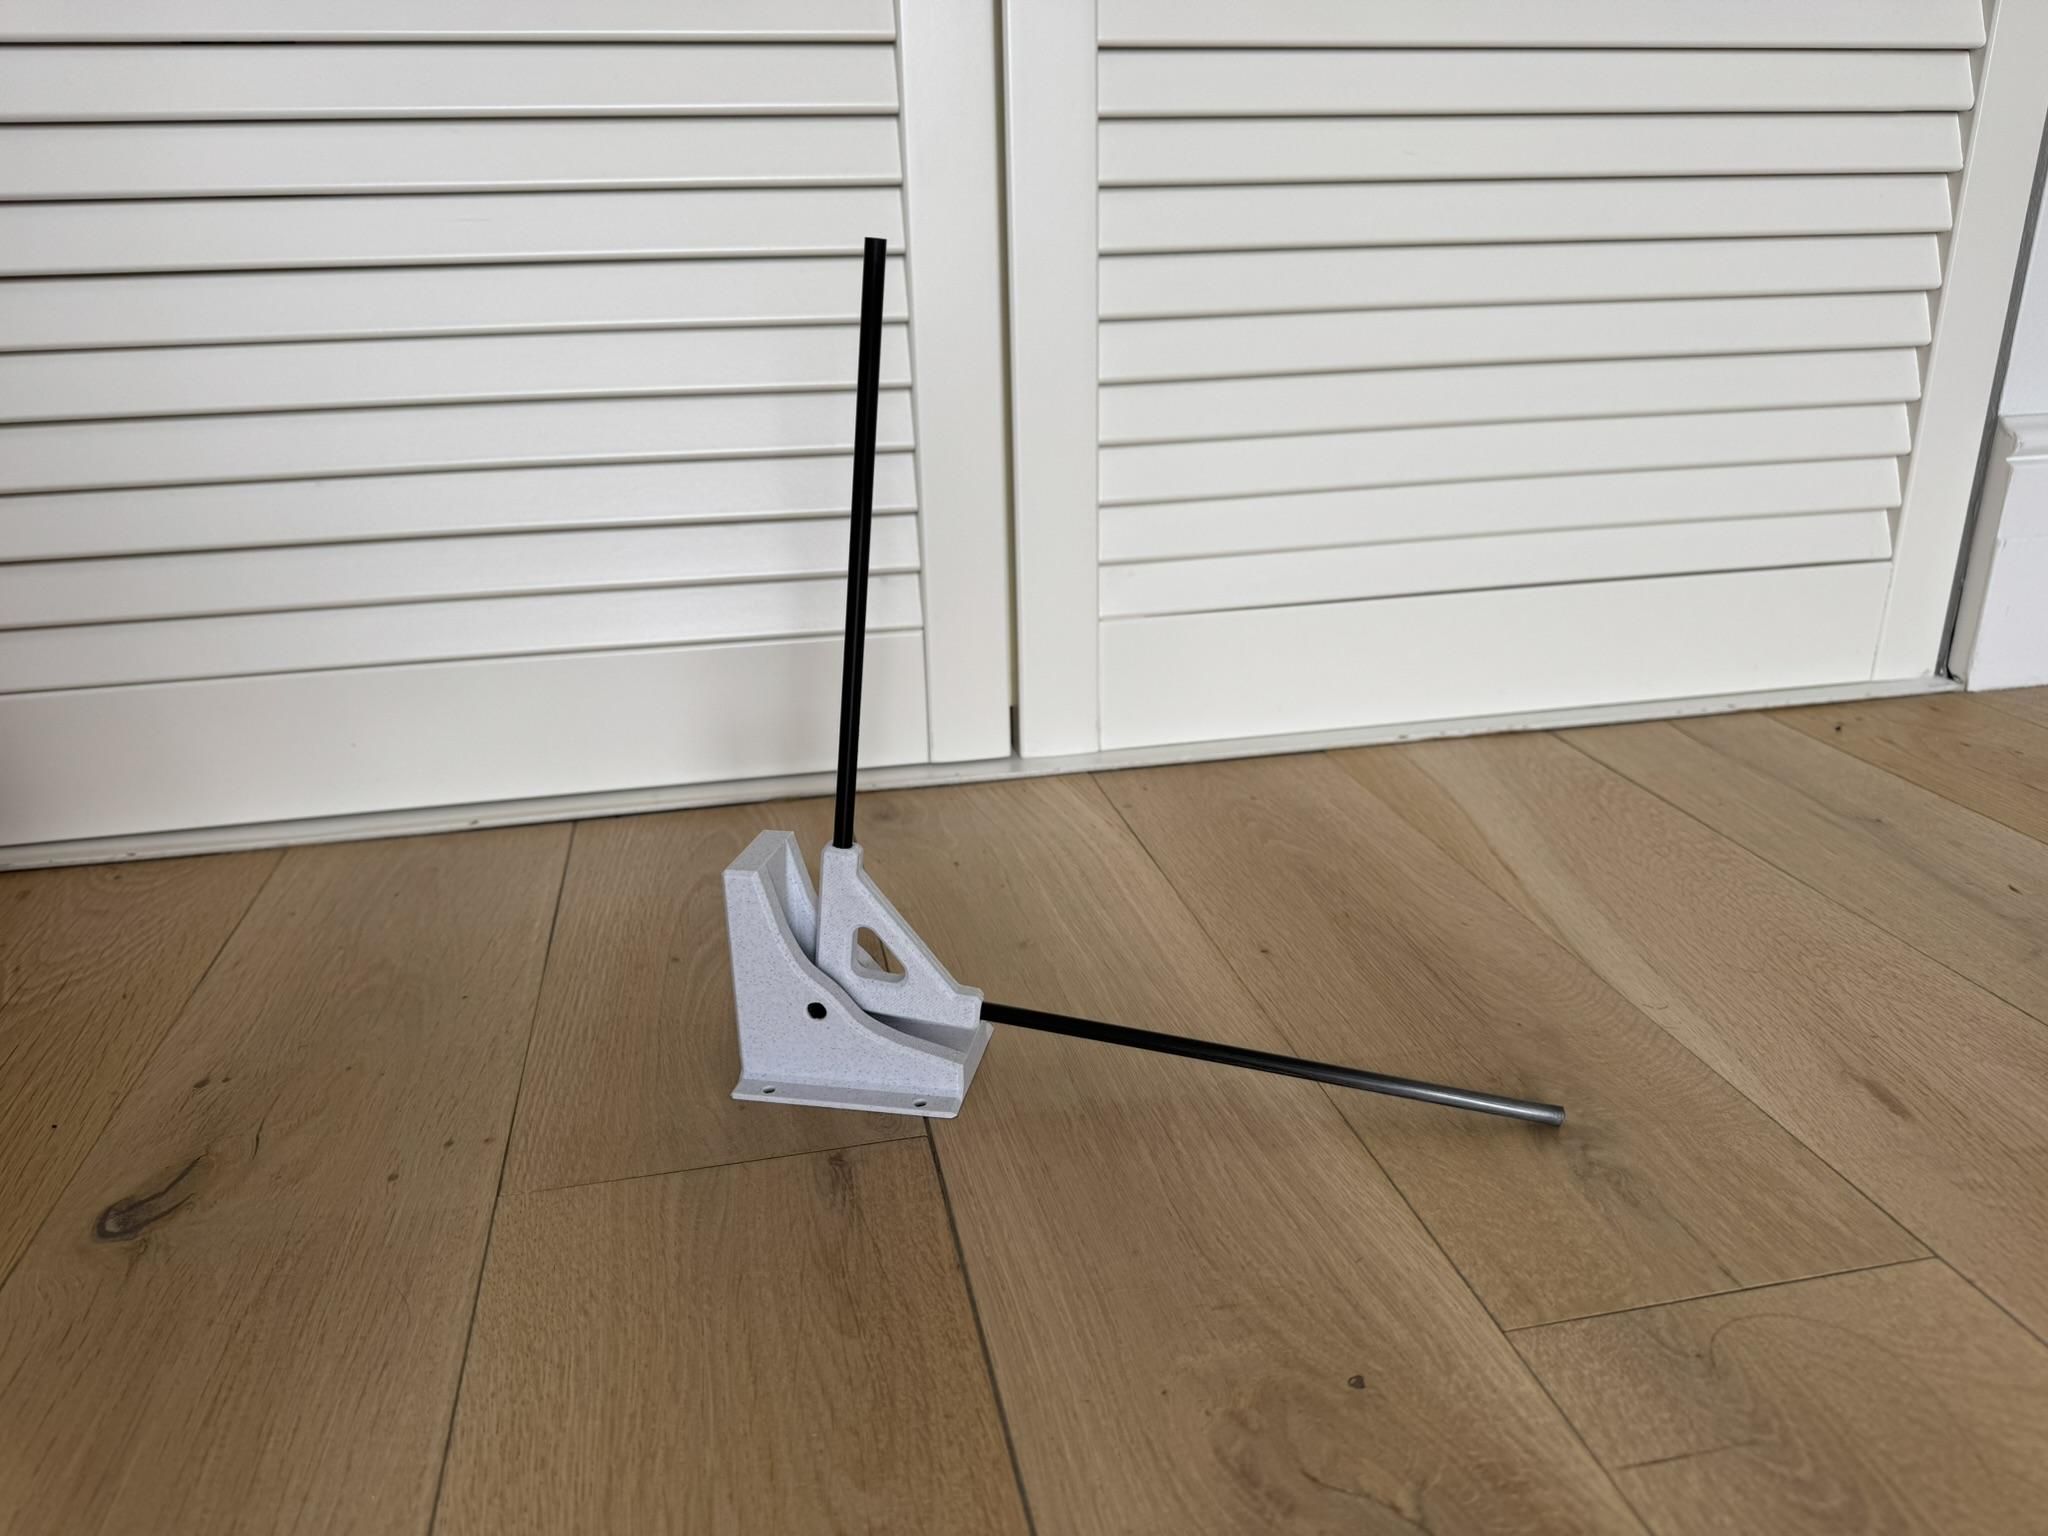
First, apply thick CA glue or another suitable adhesive inside the cavities and along the inner surfaces of both hinge parts. Insert one of the long carbon tubes into the first hinge half, making sure it reaches the end of the cavity and sits firmly in place. Once it is positioned correctly, glue the second hinge half on top, clamping the carbon tube securely between the two parts.
When the hinge assembly is finished, insert the short carbon tube about halfway into the base. Add a small amount of grease or lubricant inside the hinge area to make the movement smoother. The hinge assembly can then be placed into the base, and the short carbon tube can be pushed fully through to act as the hinge pin.
The tube should fit snugly and stay in place without moving sideways. If needed, a small amount of glue can be added to the outer ends of the tube to secure it further, making sure that no glue reaches the rotating part of the hinge.
Top Assembly


When the bottom assembly is ready, it can be glued or screwed onto a base. For my build, I used a piece of plywood cut to approximately 10 × 40 cm, which provided enough space to keep the stand stable during testing.
The motor mount and the lower end piece can then be attached to the carbon tubes using the same method as the hinge assembly in the previous step. Apply some thick CA glue inside the mounting cavities, slide the parts onto the tubes, and make sure they are fully seated before the glue cures.
It is important to center the parts carefully on the carbon tubes so that the thrust force is transferred as directly as possible along the intended axis. This helps reduce unwanted bending and makes the measurements more consistent.
The motor itself can then be secured to the motor mount using two M3 screws.
Usage

Usage:
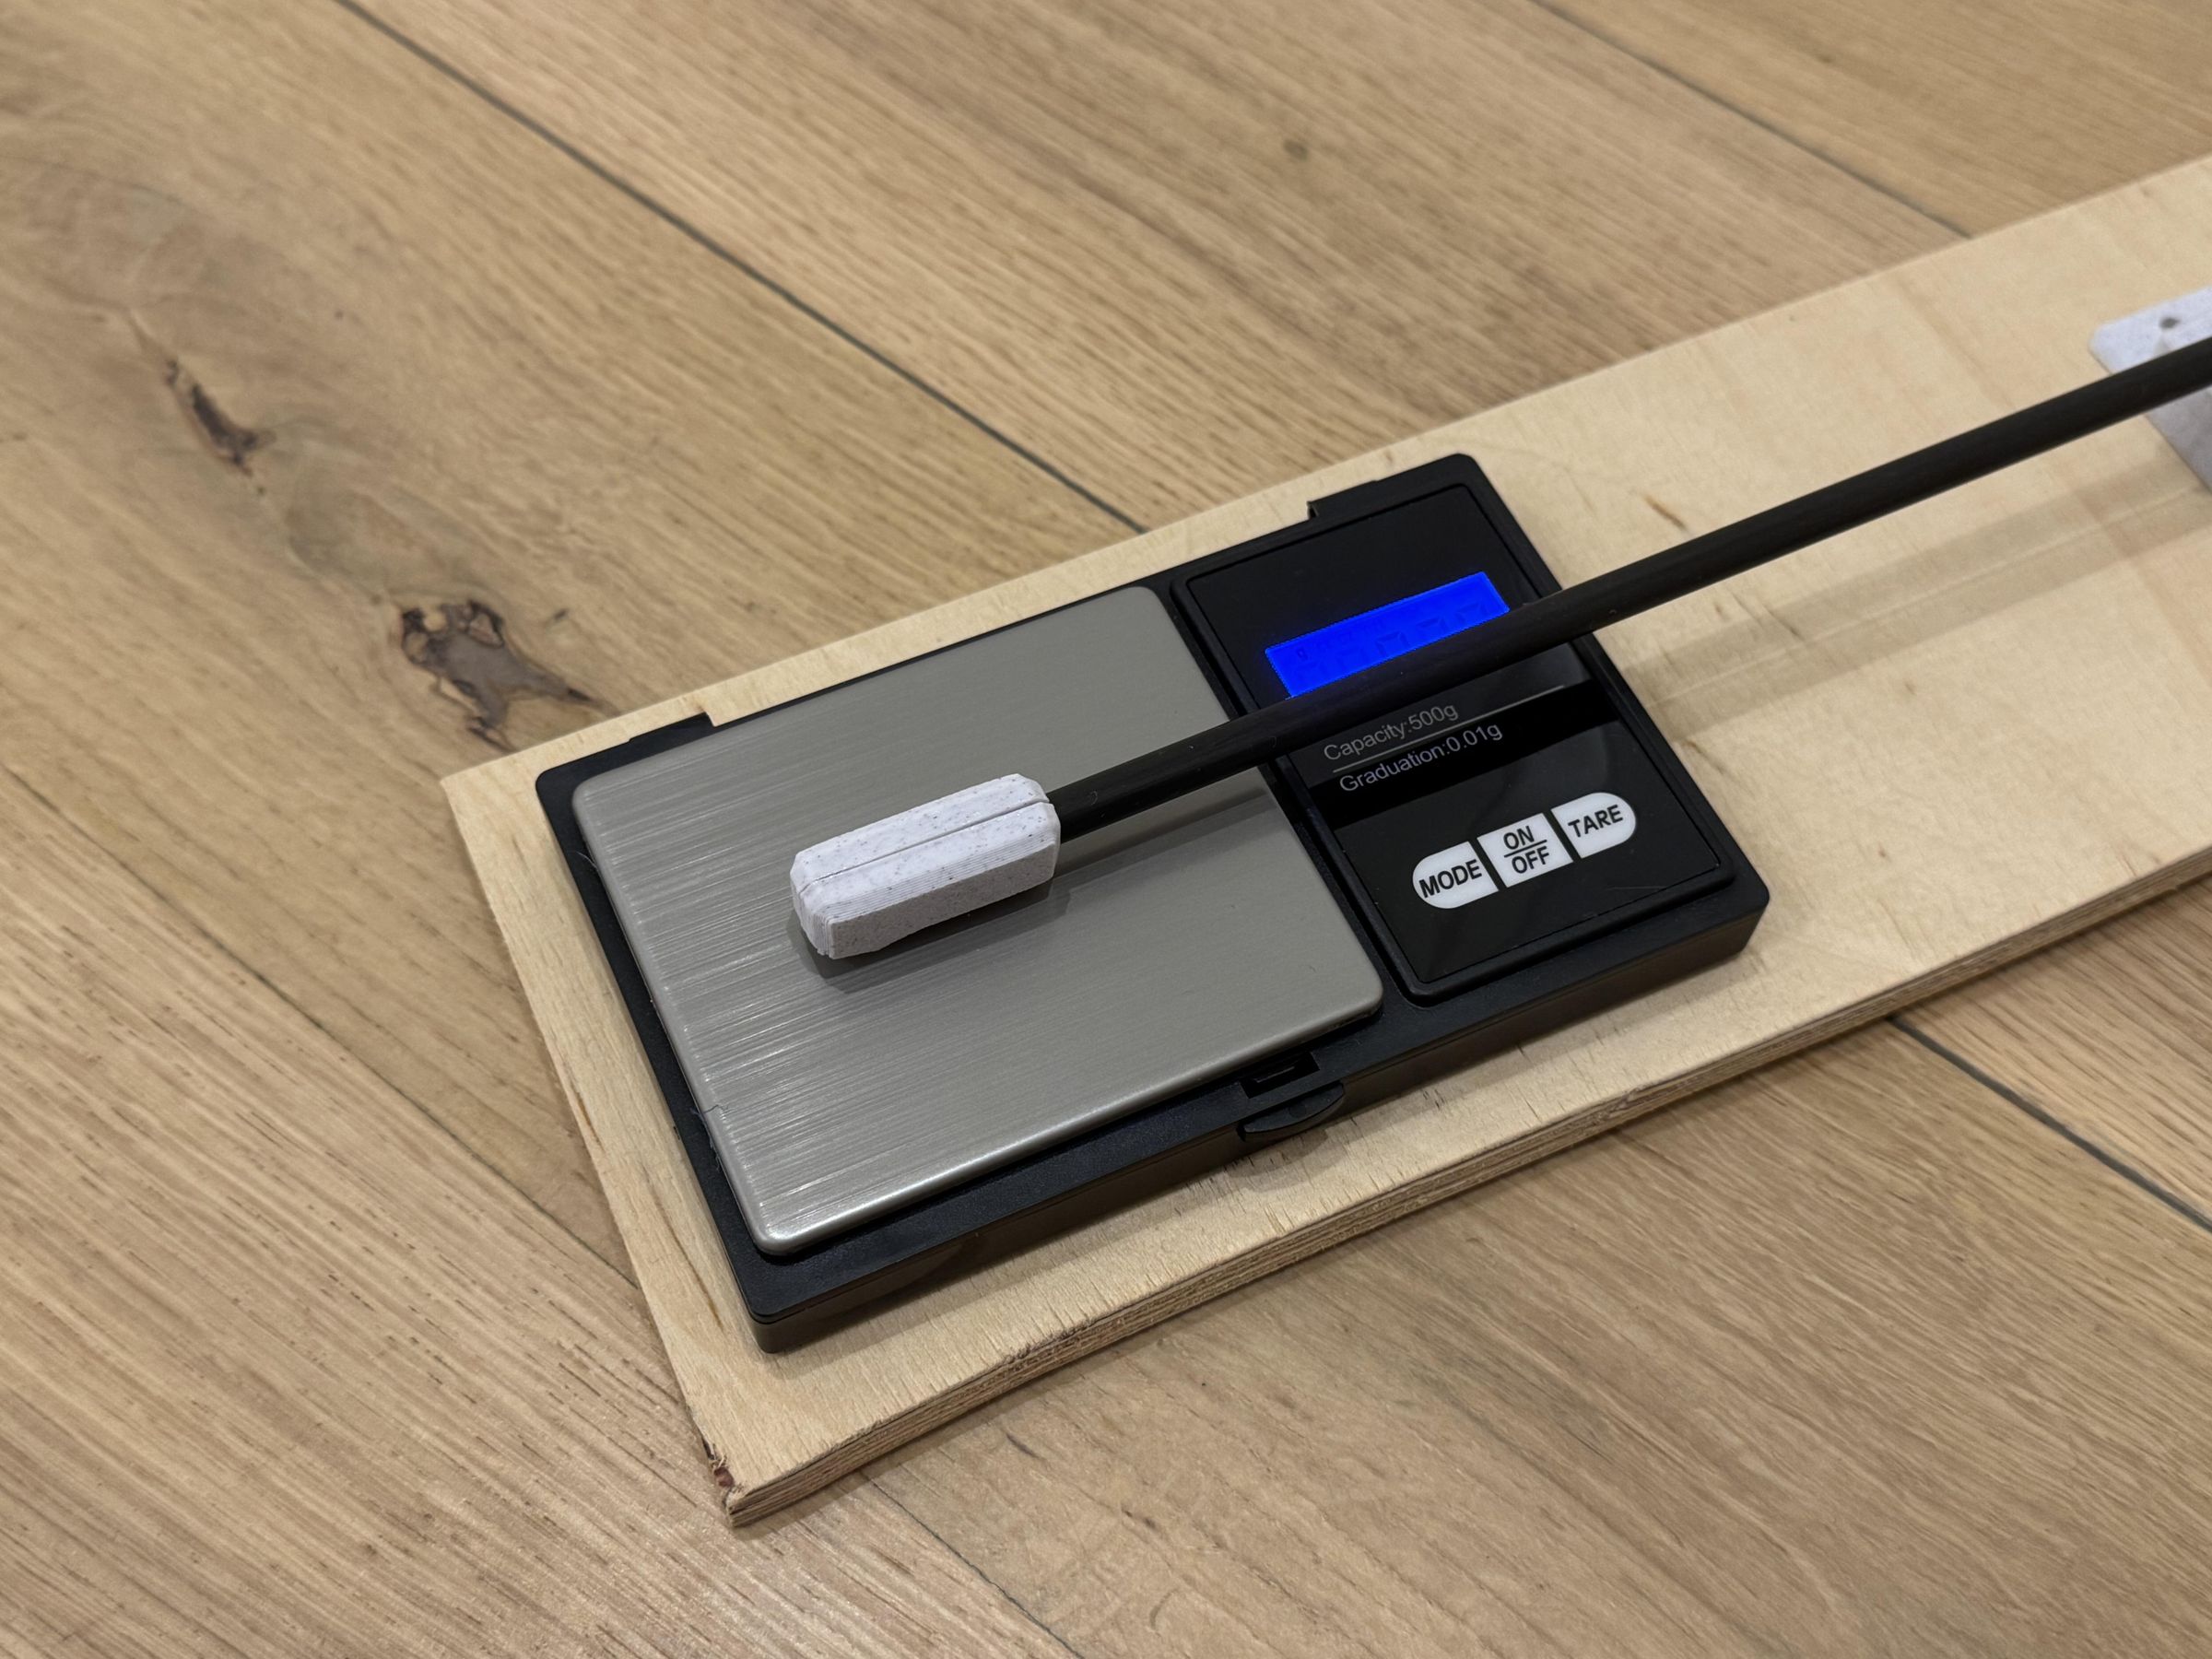
When the whole stand is assembled, the scale can be placed under the lower end of the arm and the motor can be mounted securely on the motor mount. Make sure the scale is positioned directly underneath the contact point so that the force is transferred vertically and the reading is as accurate as possible.
Before starting a test, check that the hinge moves freely and that nothing is rubbing or binding. It is also worth zeroing the scale with the stand already resting on it, so the reading only shows the additional force created by the motor.
Once everything is aligned, connect the motor to the ESC and power system and slowly increase the throttle. The thrust produced by the motor will create a force on the opposite end of the arm, which can be read directly from the scale. For more consistent results, increase the throttle gradually and wait for the reading to stabilise before recording each value.
During testing, keep clear of the propeller and make sure the stand is firmly fixed to the base. It is also a good idea to check the motor mount, hinge and glued joints between runs, especially when testing higher thrust levels.