ORBIT Breadboard BaseBot: Part 1 - Build the Circuit
by samuelwlinton in Circuits > Robots
48 Views, 0 Favorites, 0 Comments
ORBIT Breadboard BaseBot: Part 1 - Build the Circuit
-schematic.png)
This project is the first of two parts in the creation of an ORBIT Breadboard BaseBot.
This first part is on the creation of the circuit.
The second part is the assembly of the structure, found here.
The circuit to be built is shown in the diagram. (Note that the motors shown are added in the second project.) This project will walk you through how to do this.
TODO:
Supplies
Software installation
Supplies
TODO
Add the Raspberry Pi Pico W

Join two breadboards together, making sure the numbering on the boards matches.
Firmly push the Raspberry Pi Pico W onto the right breadboard as shown. The USB connector should be towards the top of the breadboard. Note: wiring instructions which refer to row numbers on the breadboards assumes that the Pico is inserted into the breadboard exactly as shown.
Add Motor Driver

Add the DRV8833 Motor Driver to the left breadboard as shown. The exact placement is not critical, as long as the pins of the board span the breadboards gutter.
Connect Power to the Motor Driver
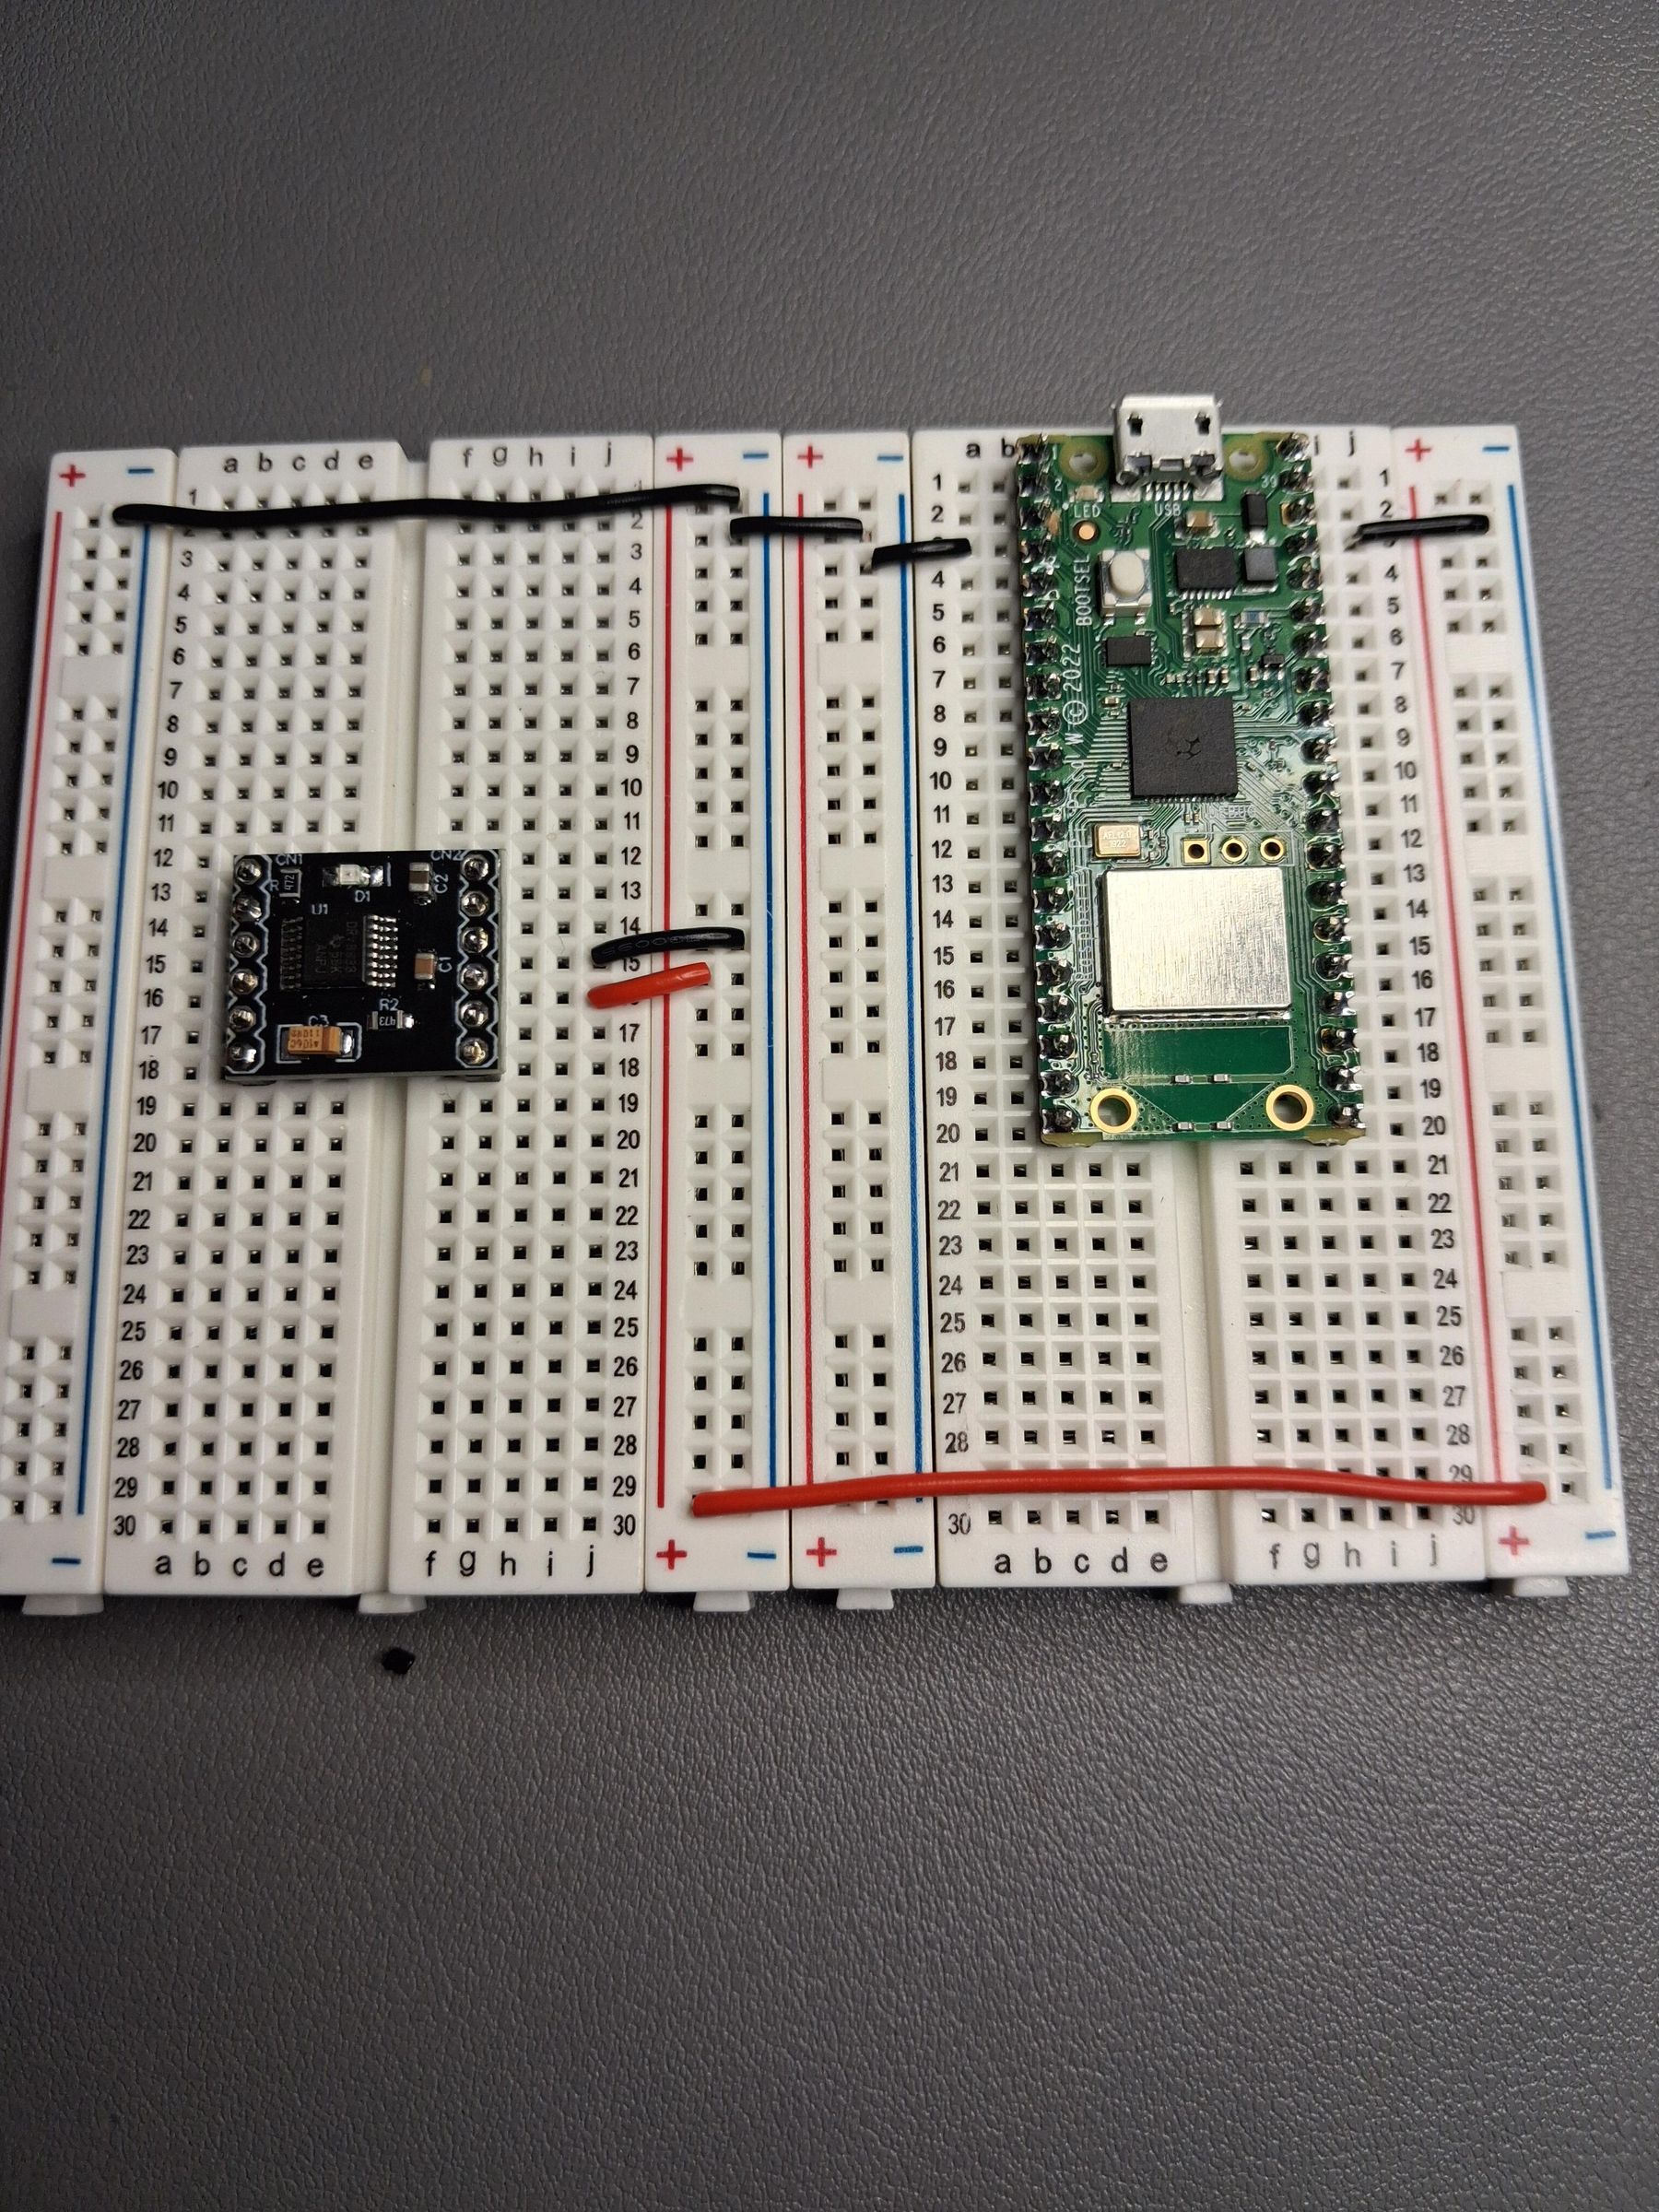

The external battery to power the motors will be connected to the right-hand power rails on the right hand board.
- Connect the ground and +5V power input as shown. (An external battery will be connected to the right-hand power rails on the right-hand board). Make sure to use black wires for ground and red wires for +5V.
- Next, connect the +5V to the Motor Driver VCC pin, and connect the ground to the Motor Driver GND pin.
Note that these labels are not visible when the Motor Driver is inserted into the breadboard. A tip is to have another Motor Driver available so you can flip it over and see which pin is which!
Connect Logic Level Power

- Connect the Motor Driver's EEP pin to 3.3V (you can route this value from the 3V3_OUT pin on the Pico. It is accessed at breadboard pin #5 on the right).
- Connect the Motor Driver's ULT pin to Ground
Connect Pico Logic to Motor Driver

This step will allow the pico to control two motors using 4 pins via the Motor Driver.
Following the pinout diagram, make the connections between the Pico and Motor Driver as shown in this picture and in the pinout diagram above.
Add Buzzer


A buzzer comes in very handy to make a sound when the bluetooth connection is established or lost. Push the buzzer firmly into the breadboard. Make sure you note which rows on the breadboard the buzzer's leads are inserted into! Connect the buzzers ground to any ground, and connect the buzzer's positive side to GP22 on the Pico (breadboard row 12, right side).
Add LED


A blue LED (you can use any color!) is used to indicate that the BaseBot is connected via Bluetooth to a controller.
Before installing the LED, it is always a good idea to check to see if it is working using a coin cell battery.
Add the LED, a 330 Ohm resistor (or similar) as shown, with the positive side connected to the Pico pin GP6 (row 9 on the left side).