Scrap Robotic Arm


Yo, so I basically built a functional, heavy-duty robotic arm entirely out of literal garbage and old broken electronics I found lying around.
I really wanted to prove that you don't need a huge budget, expensive servo motors, or a fancy 3D printer to build cool engineering projects—you just have to look at trash a bit differently. The base is literally made from an old food flask because its wide shape keeps the center of gravity low and prevents the whole thing from tipping over when it reaches out. Plus, it gave me the perfect hollow chamber to hide all the messy wiring and power connections inside so the build looks clean.
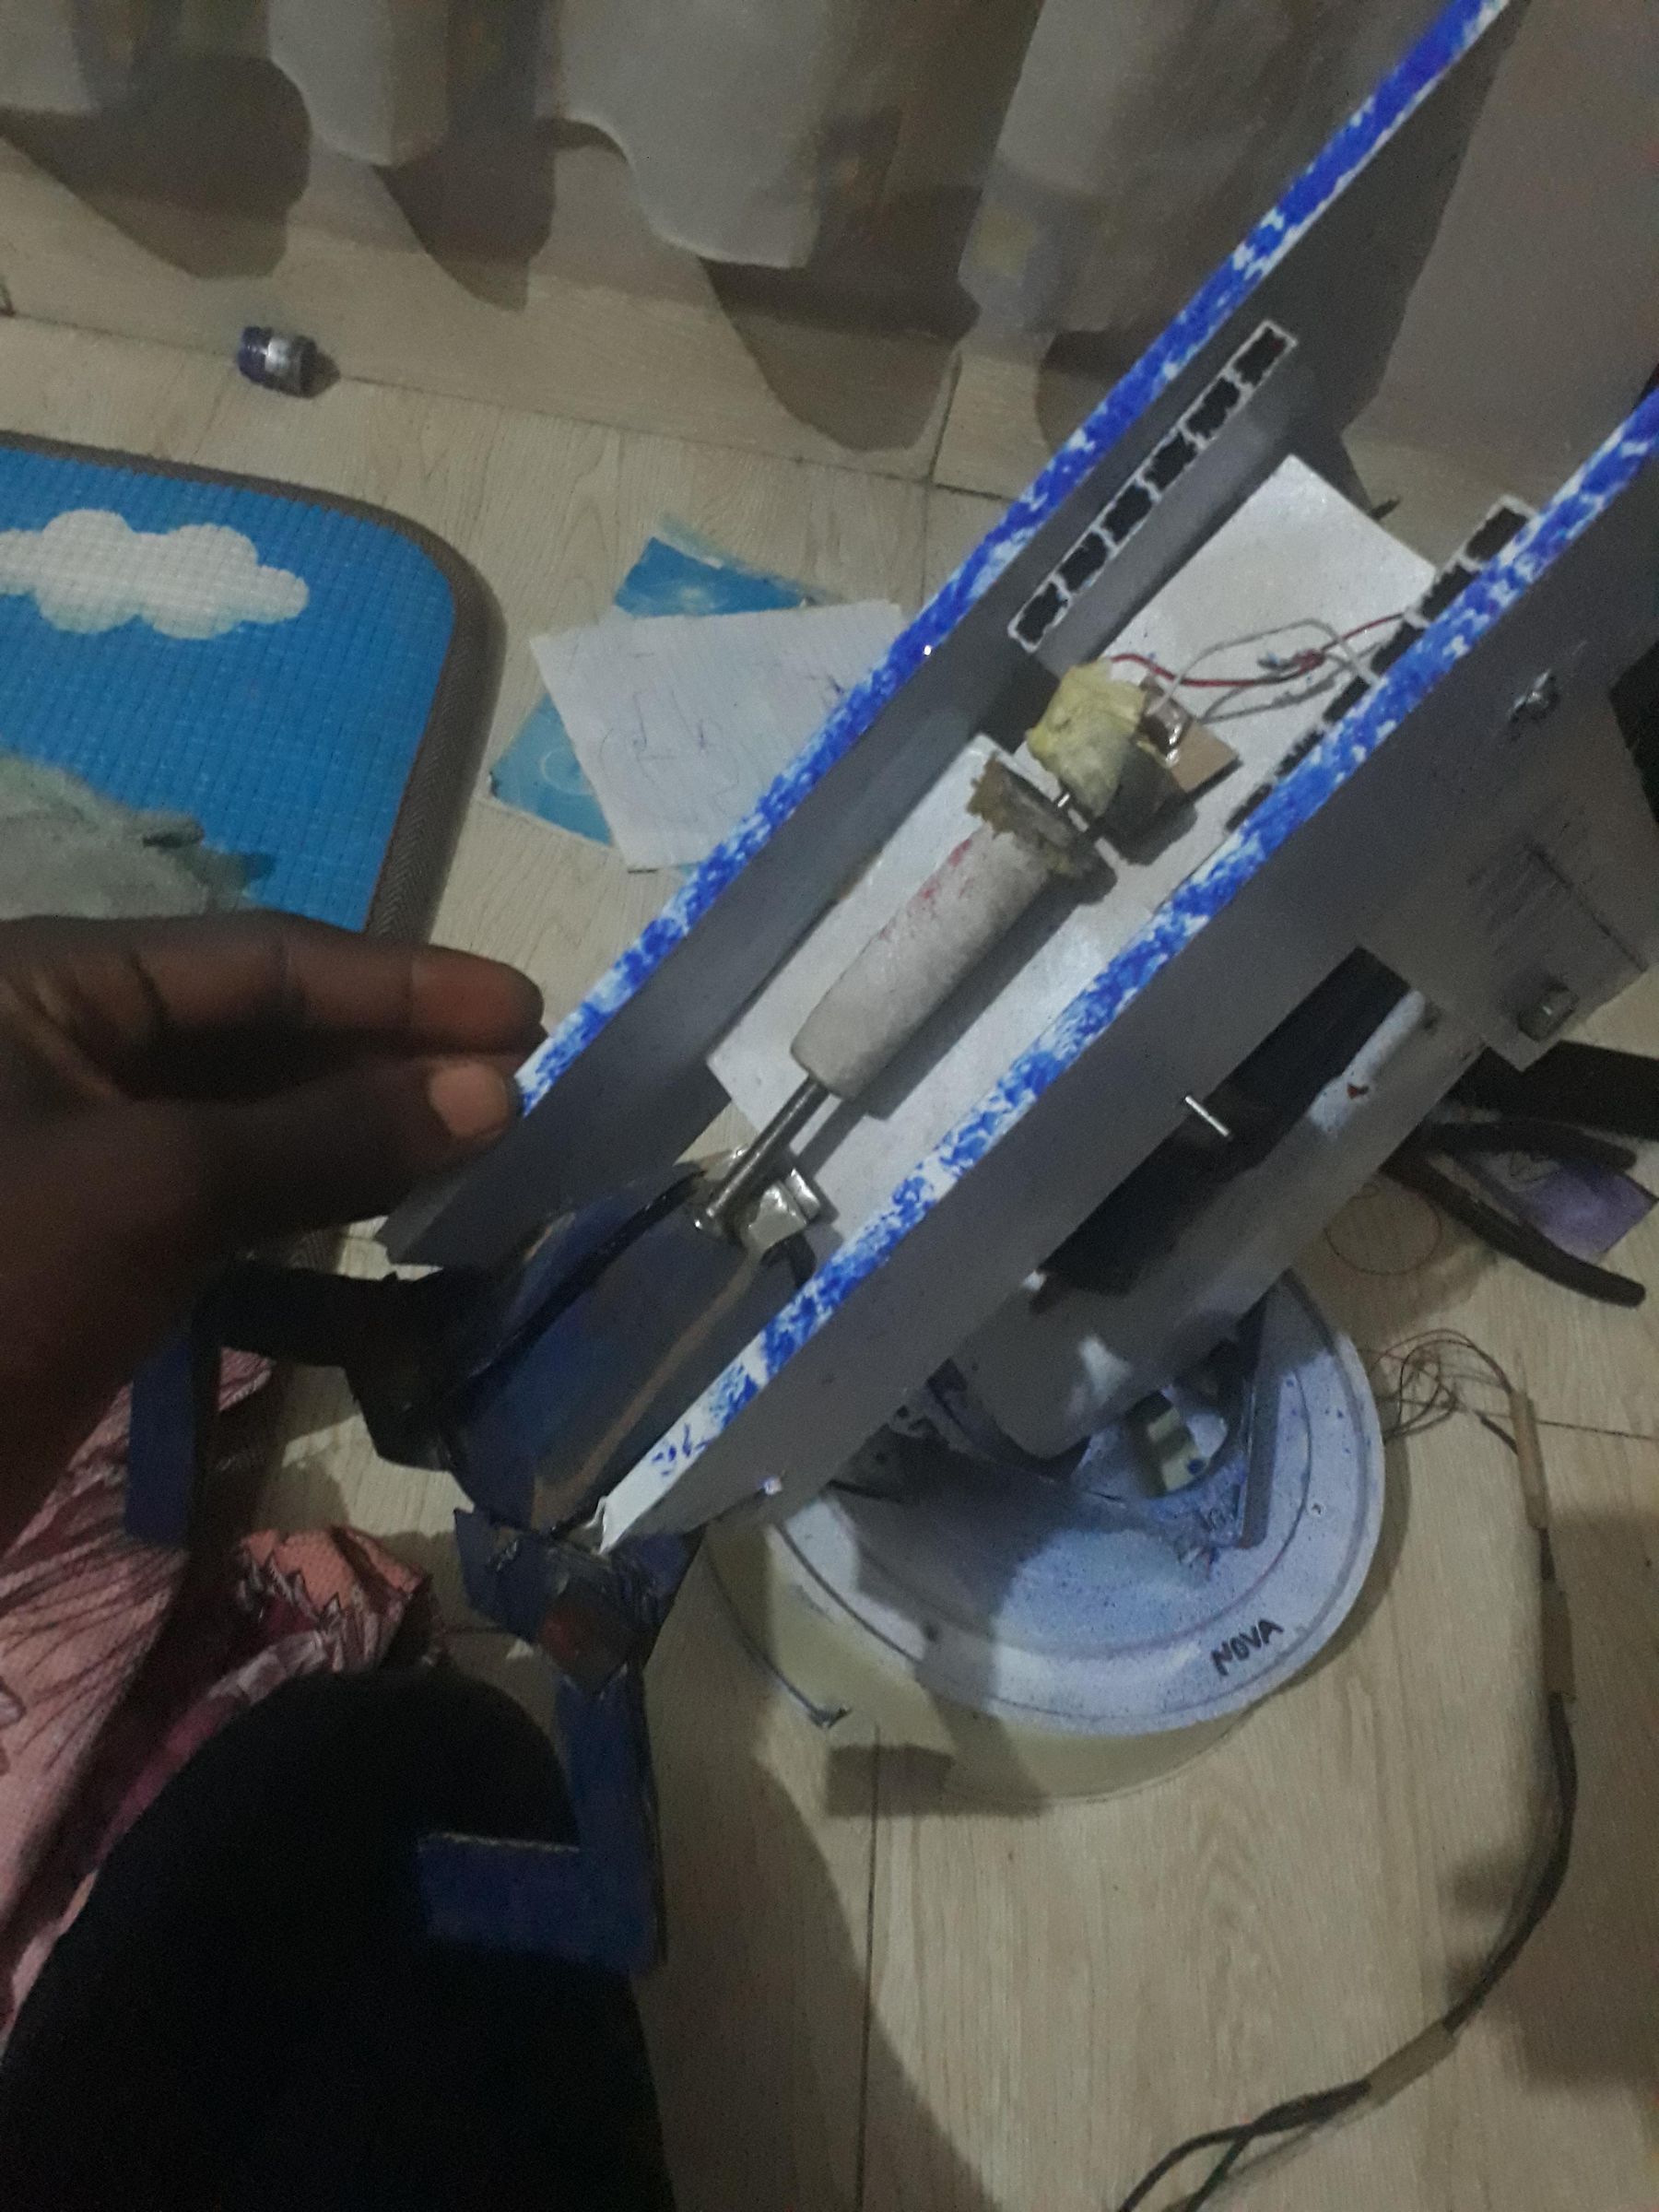
For the actual structure, I used different types of scrap plastic depending on what the joint needed. The thick main base arm is built from a sturdy piece of salvaged PVC pipe to give the whole rig a solid, rigid backbone. Then, the first and second upper arm segments are cut out of lightweight PVC ceiling board scraps. These boards have a hollow, ribbed design inside that acts like an industrial I-beam, keeping the front end agile without snapping under pressure.
For the rotation axis, I mounted everything on top of an old 12V PC cooling fan. Instead of using a separate motor to turn the base, I just wired up the cooling fan directly—so as soon as power is added to it, the fan itself spins and turns the entire upper arm assembly.
But here is the coolest part of the engineering: every single motor moving the arm segments uses a screw attached directly to its shaft. For the extra heavy-duty lifting, I ripped a powerful 775 motor out of a broken table fan and attached a long screw to it to make a custom lead screw linear actuator. For the forearm that carries the claw, the little salvaged hair clipper cube motor also uses an attached screw to tilt the segment. Even the tiny 6V hobby motor at the very front uses a screw mechanism to push and pull the fingers of the heavy cardboard gripper claw open and closed!
Because screw threads create a massive mechanical advantage and a natural lock, whenever I turn the power off, the entire arm stays perfectly frozen in place and never crashes down. It honestly works like a beast and proves you can turn a kitchen food flask and construction junk into a high-torque machine if you get a little creative!
Downloads
Supplies


Materials used
- PVC Ceiling Board & PVC Pipe: Used to form the rigid upper and lower arm sections.
- Cardboard: Cut and layered to create an ultra-lightweight mechanical gripper claw.
- Motors (775 Motor, Cube Motor, & 6V Motor): High-torque table fan motor for lifting, hair clipper motor for tilting, and a low-torque 6V motor for clamping the claw.
- 12V CPU Cooling Fan: Repurposed from an old computer to act as the motorized rotating base.
- Plywood: Cut and assembled to make a custom handheld enclosure for the wired remote control.
- Old Phone Charger Cables: Stripped down to harvest long, flexible copper lines to link the remote control box to the arm.
- Glue: Heavy-duty adhesive applied to reinforce joints and seal the remote box.
- Paint (Blue & White): Used to give the industrial scrap materials a clean, factory-finished look.
- Screws & Bolts: Mechanical fasteners used to link the moving joints together.
- Blue LED Light: Installed inside the frame channels to illuminate the internal screw mechanics.
- Drill Screws: Heavy-duty fasteners used to mechanically lock the main mast to the rotating fan hub.
- 3.7V Battery: The primary portable power cell running the entire control circuit.
Preparing the Base
.jpeg)
Step 1: preparing the Food Flask Base
Grab a wide, heavy plastic food flask. This will serve as the base
Take a utility knife or the hot tip of a soldering iron and melt a clean 15mm hole right near the bottom edge of the flask wall. This is your main exit portal for your power supply wires.
Drill a 10mm hole straight through the dead side of the flask's screw-on lid. This acts as a smooth wire channel so your cables can pass from the inside of the flask up into the arm without rubbing or getting tangled when the arm rotates.
Making the Base Rotational

2: Hacking the PC Fan Turntable Axis
Get a broken 12V PC cooling fan. Spin the blades with your finger to make sure the internal bearings aren't jammed. Use an old toothbrush to clean out any dust or hair stuck inside the spinning track.
Strip down the red and black wires on the fan. Hook them up to your test battery to make sure that as soon as power hits it, the fan frame spins immediately.
Cover the top of the food flask lid with a thick layer of hot glue or two-part epoxy. Press the flat bottom frame of the fan housing down hard into the glue, then use a drill screw to mend it firmly.
Cut a thick piece of salvaged PVC plumbing pipe to about 25cm long to act as your main lower backbone. Drive a long, heavy-duty mechanical screw straight down through the inside middle of the PVC pipe and bite it right into the plastic center spinning hub of the cooling fan. This physically locks the mast to the fan so when the fan spins, the entire upper arm spins with it. Slap a thick ring of hot glue around the bottom edge of the pipe for absolute zero wobble.
Fabricating the Rigid PVC Ceiling Board Boom


Step 3: Fabricating the Rigid PVC Ceiling Board Boom
Cut out two pairs of identical parallel side panels for the upper arms using your scrap PVC ceiling board.
The Ultimate Structural Trick: When you look at the cut edge of the ceiling board, you'll see hollow, square channels running through it. Make sure your long structural cuts run with these channels, not across them. This creates an industrial I-beam effect—keeping the arm segments super light so the motors don't strain, but giving it massive structural strength so it won't flex or bow.
Drill a 5mm hole through the top end of your vertical PVC pipe backbone, and matching 5mm holes through the base ends of your first pair of ceiling board panels.
Slide a long metal bolt through the ceiling boards and the PVC pipe joint, then spin a nut onto the other side. Tighten it down just enough so the joint can swing up and down smoothly, but make sure it’s tight enough to stop any annoying side-to-side rattling. Repeat this exact drilling and bolting setup to connect the first upper arm segment to the second forearm segment.
Building the 775 Motor Main Linear Actuator(screw Mechanized System


Step 4: Building the 775 Motor Main Linear Actuator(screw mechanized system
Take the big, heavy-duty 775 motor out of your broken table fan. Mount it tightly to the side of the lower PVC mast using a bracket made from wood or PVC scraps.
Attach a long threaded metal screw rod directly to the spinning shaft of the 775 motor. Use a rigid metal coupler sleeve, and crank down the tiny set screws with an Allen wrench until the rod is locked flat against the flat spot of the motor shaft so it can't slip or spin free.
Align the long screw rod vertically so it sits perfectly inside the open space between your parallel PVC ceiling board panels.
Spin a traveling nut onto the threaded rod. Use two small machine screws to anchor the wings of this traveling nut firmly to the lower hinge link of your first upper arm segment.
How it works: When you feed power to the 775 motor, it spins the threaded rod fast. The rotation forces the traveling nut to crawl straight up or down the threads, converting high-speed spin into massive linear lifting force. Best part? The friction of the screw threads creates an automatic mechanical lock. The exact second you cut the power, the nut freezes on the threads and the arm stays locked in position instead of crashing down.
Adding the Hair Clipper Cube Motor Tilt Screw
Step 5: Adding the Hair Clipper Cube Motor Tilt Screw
Mount the little rectangular cube motor you pulled out of the dead hair clippers right onto the hinge joint connecting the first and second ceiling board segments.
Attach a smaller, fine-threaded screw directly to the output shaft of this cube motor using a tight press-fit .
Thread this smaller screw through a tiny pivot nut that is anchored to the bottom side of the second forearm segment carrying the claw.
When you power up the cube motor, it spins the small screw, moving the pivot nut to precisely tilt the front forearm segment up and down so you can aim your gripper perfectly.
Building the Claw Screw Mechanism With Cardboard


Step 6: Rigging the Cardboard Claw Screw Mechanism
Trace and cut out a two-sided mechanical gripper claw from a thick piece of dense, multi-layer corrugated box cardboard.
Use small pins or bits of cut wire as the pivot hinges for the claw fingers. Using cardboard keeps the front end incredibly light, which keeps the arm perfectly balanced and centers all the weight back toward the heavy flask base.
Mount a tiny 6V hobby motor to the very tip of the forearm and attach a small fine-threaded screw directly onto its shaft.
Guide the threads of this screw into the center linkage of the cardboard claw fingers. When the motor spins clockwise, the screw pulls the linkage back to clamp the jaws shut; spinning it counter-clockwise pushes the linkage forward to open the claw wide.
Wiring and Adding LED


Step 7: Running the Wiring Harness and Bling
Take your old, broken USB phone charging cables and slice open the outer plastic jacket to harvest the highly flexible copper wires inside.
Fish these wires carefully down through the hollow center of your vertical PVC pipe mast and route them inside the open channels of your PVC ceiling boards so they are completely hidden and won't snag when the joints move.
Route all the wires down into the hollow food flask and join to an external long wires to the wired remote.
Splice a bright LED covered with blue cover of a table water into the main power line and tuck it into the upper PVC pipe channel. It lights up the whole internal metal screw assembly from the inside, making the entire build look like a high-tech engineering machine when you switch it on!
Test the Control Loops and Reverse the Motors!(the Remote)

Step 8: Test the Control Loops and Reverse the Motors!(the remote)
Now that everything is wired up, it is time for the fun part: testing your custom controller to make sure it actually talks to your robotic arm. Since we aren't using regular store-bought buttons, you get to complete the circuit yourself like a real hardware hacker!
Get Your Control Probe Ready: Take a loose jumper wire connected to your power source or microcontroller signal pin, and make sure the tip has a clean, exposed metal edge (or attach a metal stylus to it).
Test the "Forward" Motion: Tap your metal probe across the first pair of staples in one of your clusters. This closes the gap, lets electricity flow, and tells your wireless chip to spin the arm's motor one way.
Test the "Reverse" Motion: Move your probe over to the opposite pair of staples in that same cluster. Because of that awesome diagonal "X" pattern you wired up, the circuit automatically flips the path of the electricity, telling the motor to instantly spin backward!
Check Your Style Zones: Double-check those cool foil design accents you added around the edges. Make sure the foil isn't accidentally touching any of the bare metal staples. If it does, it will short-circuit the board and keep sending a glitchy, continuous signal to your robot.
Testing


Test it!!!