This Pure Mechanical 6 - Leg Robot Layout Inside Is GENIUS! Full Build STEM Project
by Brito Power Lab in Workshop > Science
18 Views, 0 Favorites, 0 Comments
This Pure Mechanical 6 - Leg Robot Layout Inside Is GENIUS! Full Build STEM Project
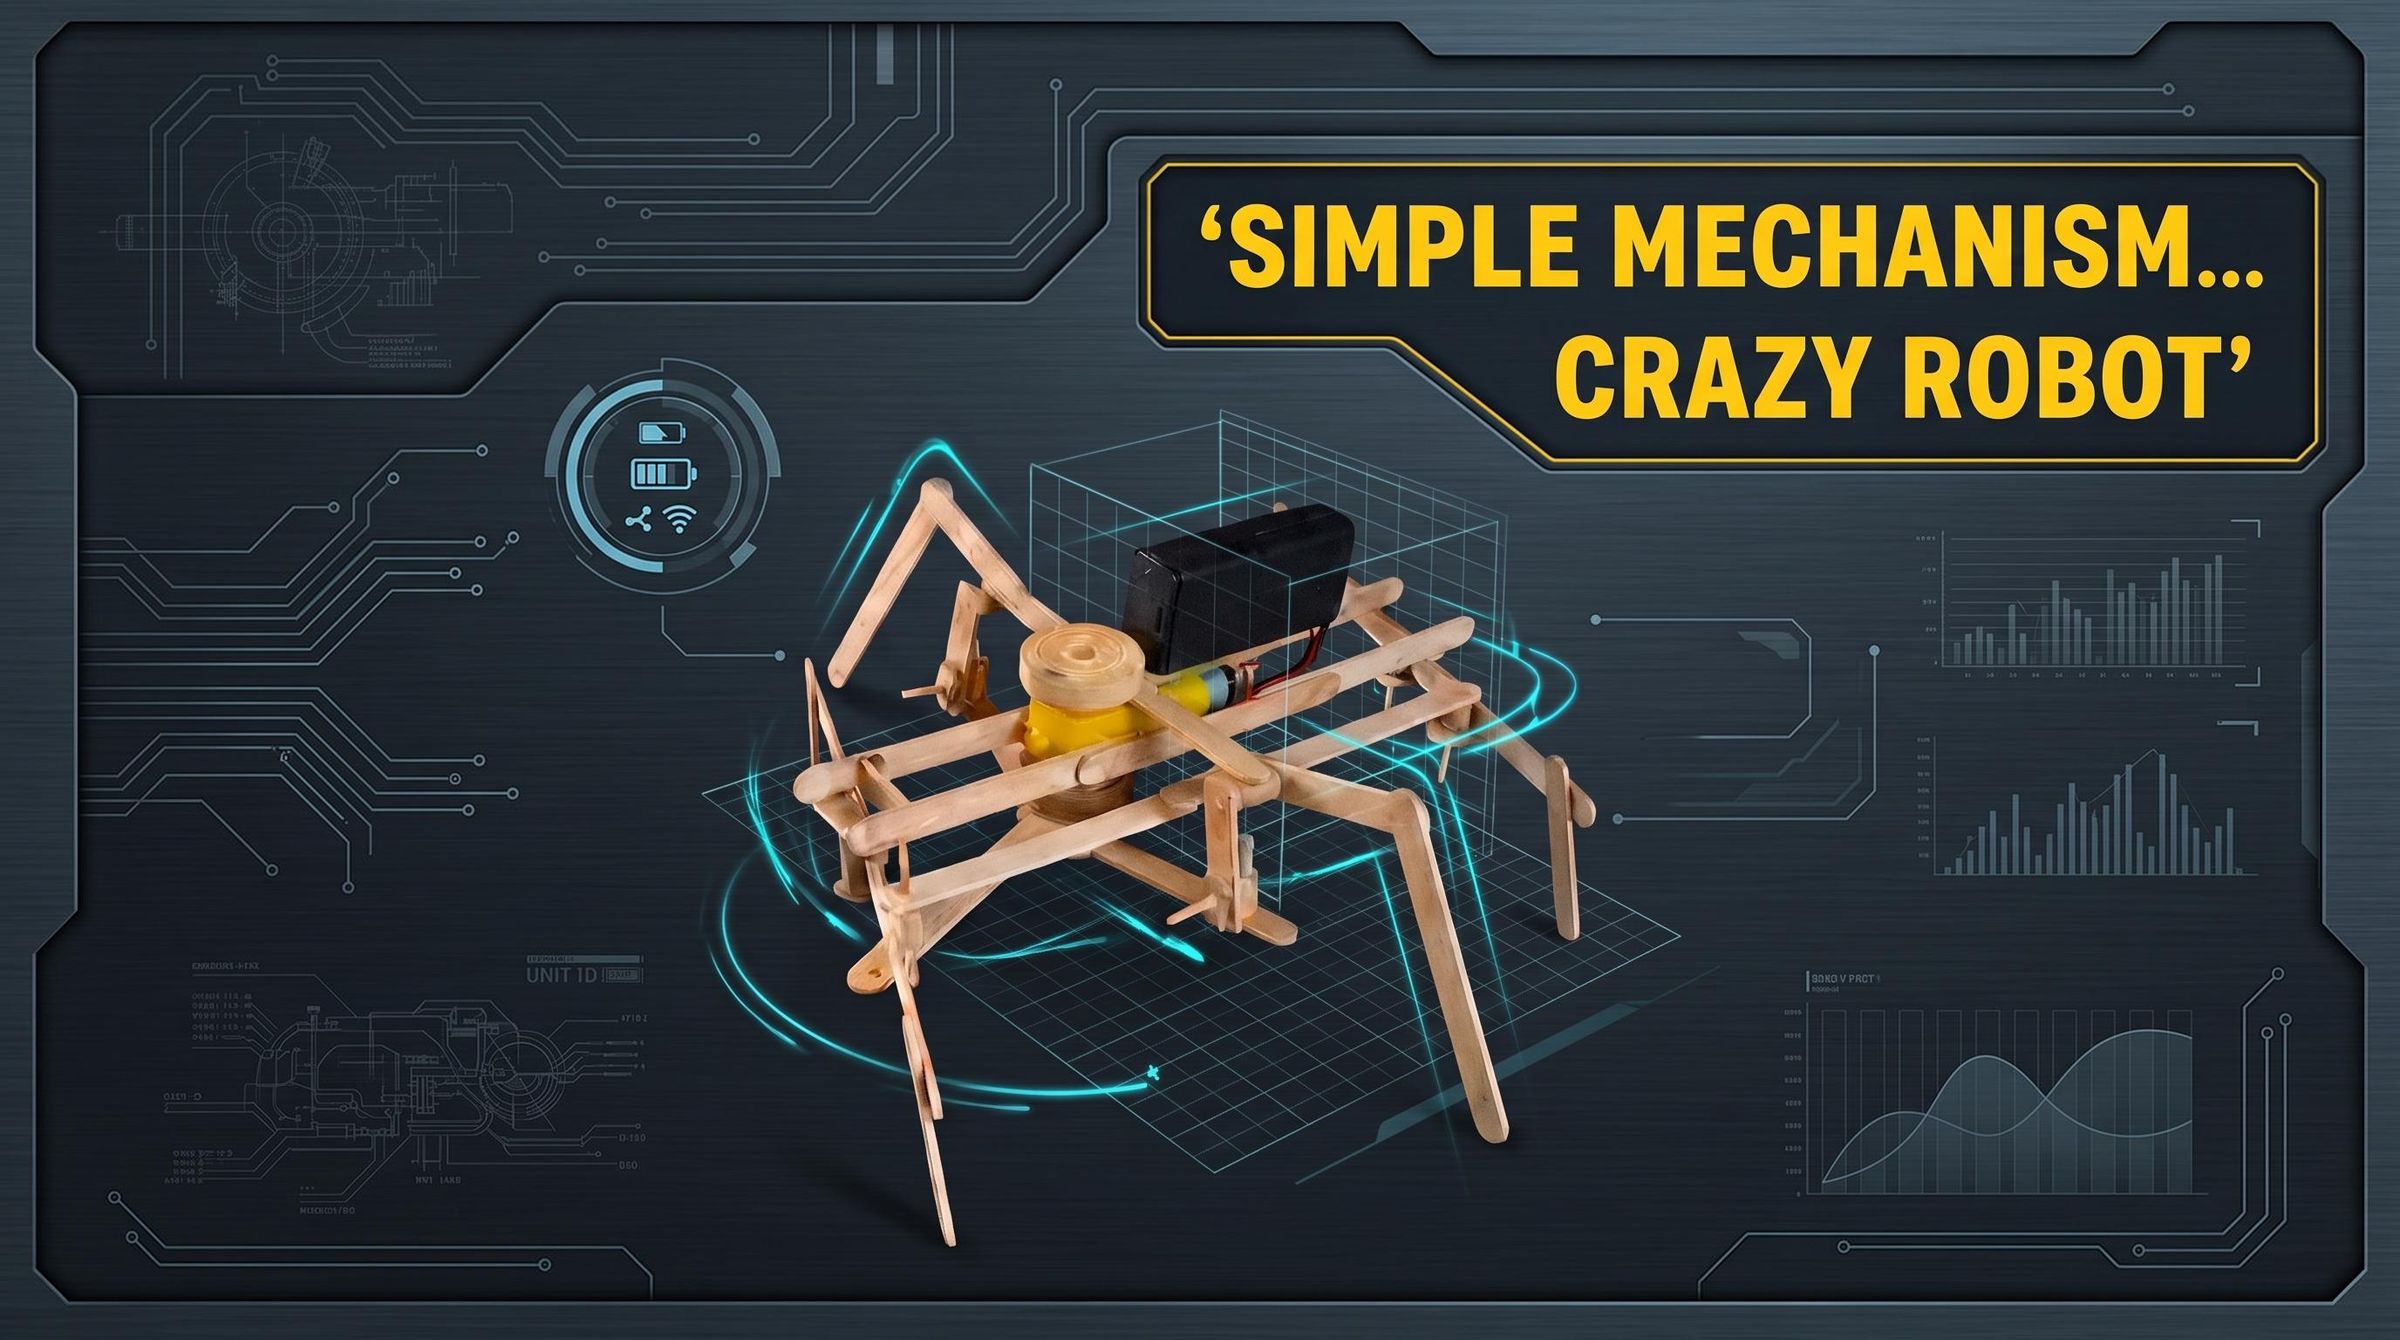

I built a 6-leg walking robot using just ONE motor! 🤯 The amazing part is that all six legs are driven by a crank and linkage mechanism. Instead of using a separate motor for every leg, I designed a mechanical link system that transfers the motor's rotation into coordinated leg movement. In this video, I'll show you how I built this walking robot, how the crank works, how the links are connected, and how the six legs move together to make the robot walk.
🤖 ONE MOTOR
🦿 SIX LEGS
⚙️ CRANK MECHANISM
🔗 LINKAGE SYSTEM
🔥 DIY WALKING ROBOT
You'll see the complete build process, mechanism, testing, adjustments, and the final walking test. The goal was to create a simple mechanical walking system using as few motors as possible — and the final movement is surprisingly satisfying! If you enjoy DIY robots, walking robots, robotics, mechanical engineering, linkage mechanisms, crank mechanisms, homemade robots, engineering projects and creative inventions, subscribe to Brito Power Lab for more unusual robots and science experiments. Watch until the end to see the complete six-leg walking test!
Supplies
Materials
- Gear Motor
- 3.7VDC Battery pack
- Carrom coin
- Popsicle stick
- Bamboo straw
How to Built
You'll see the complete build process in Video.